Makelangelo News Tutorials
How to translate Makelangelo software
As of Makelangelo Software 7.23.0 it’s now easy for you to translate Makelangelo software into your favorite language. Here’s how!
(more…)As of Makelangelo Software 7.23.0 it’s now easy for you to translate Makelangelo software into your favorite language. Here’s how!
(more…)Robot Overlord has been in heavy development since July of 2019. Now after 816 commits I believe it’s ready.
The contextual menus for objects in the scene has been completely overhauled to be consistent. The networking has added an SSH system. The kinematics now use Gradient Descent. And there’s so much more!
CDM will be doing Unity development for the Sixi Robot Arm.
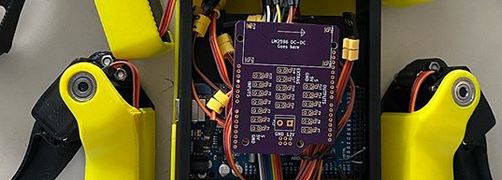
So you built a Spot Micro (or you want to) and – because you’re very clever – you read the instructions first. You probably noticed there’s a section where you have to build a PCB from scratch. For a lot of people, that’s beyond their skill level …for now. In the meantime, nothing should hold you back from building a sweet walking robot dog, amiright? Cool.
Here’s a board we used in the past for a stewart platform, which are a type of robot you can read about elsewhere on this site. It’s a good start for driving a robot dog. ELEC-0132 stewart platform board was designed for 11 PWM signals out and 6 analog values in. I’m betting that one of them can be used as an extra out signal to drive all 12 motors in the Spot Micro’s legs.
The boards are made by OSHPark and you can get them here:
https://oshpark.com/shared_projects/uGE0oIwR
But maybe wait until I test this theory. If I do this post will be updated with a part 2 right here:
