Sixi 2 robot arm
6. Shoulder Gearbox
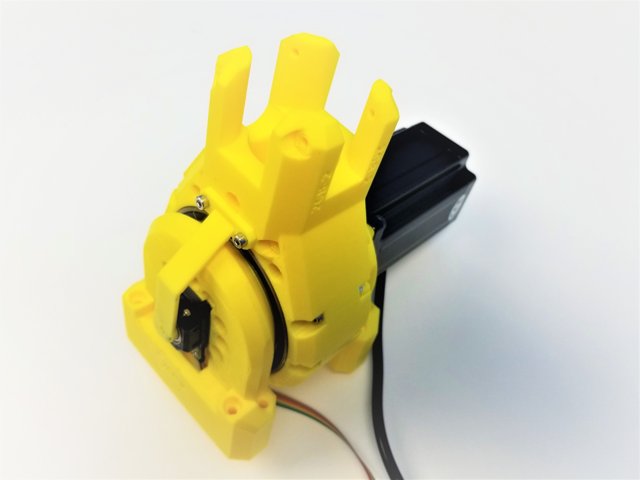
Step 1 Tools and Parts Required for this Chapter
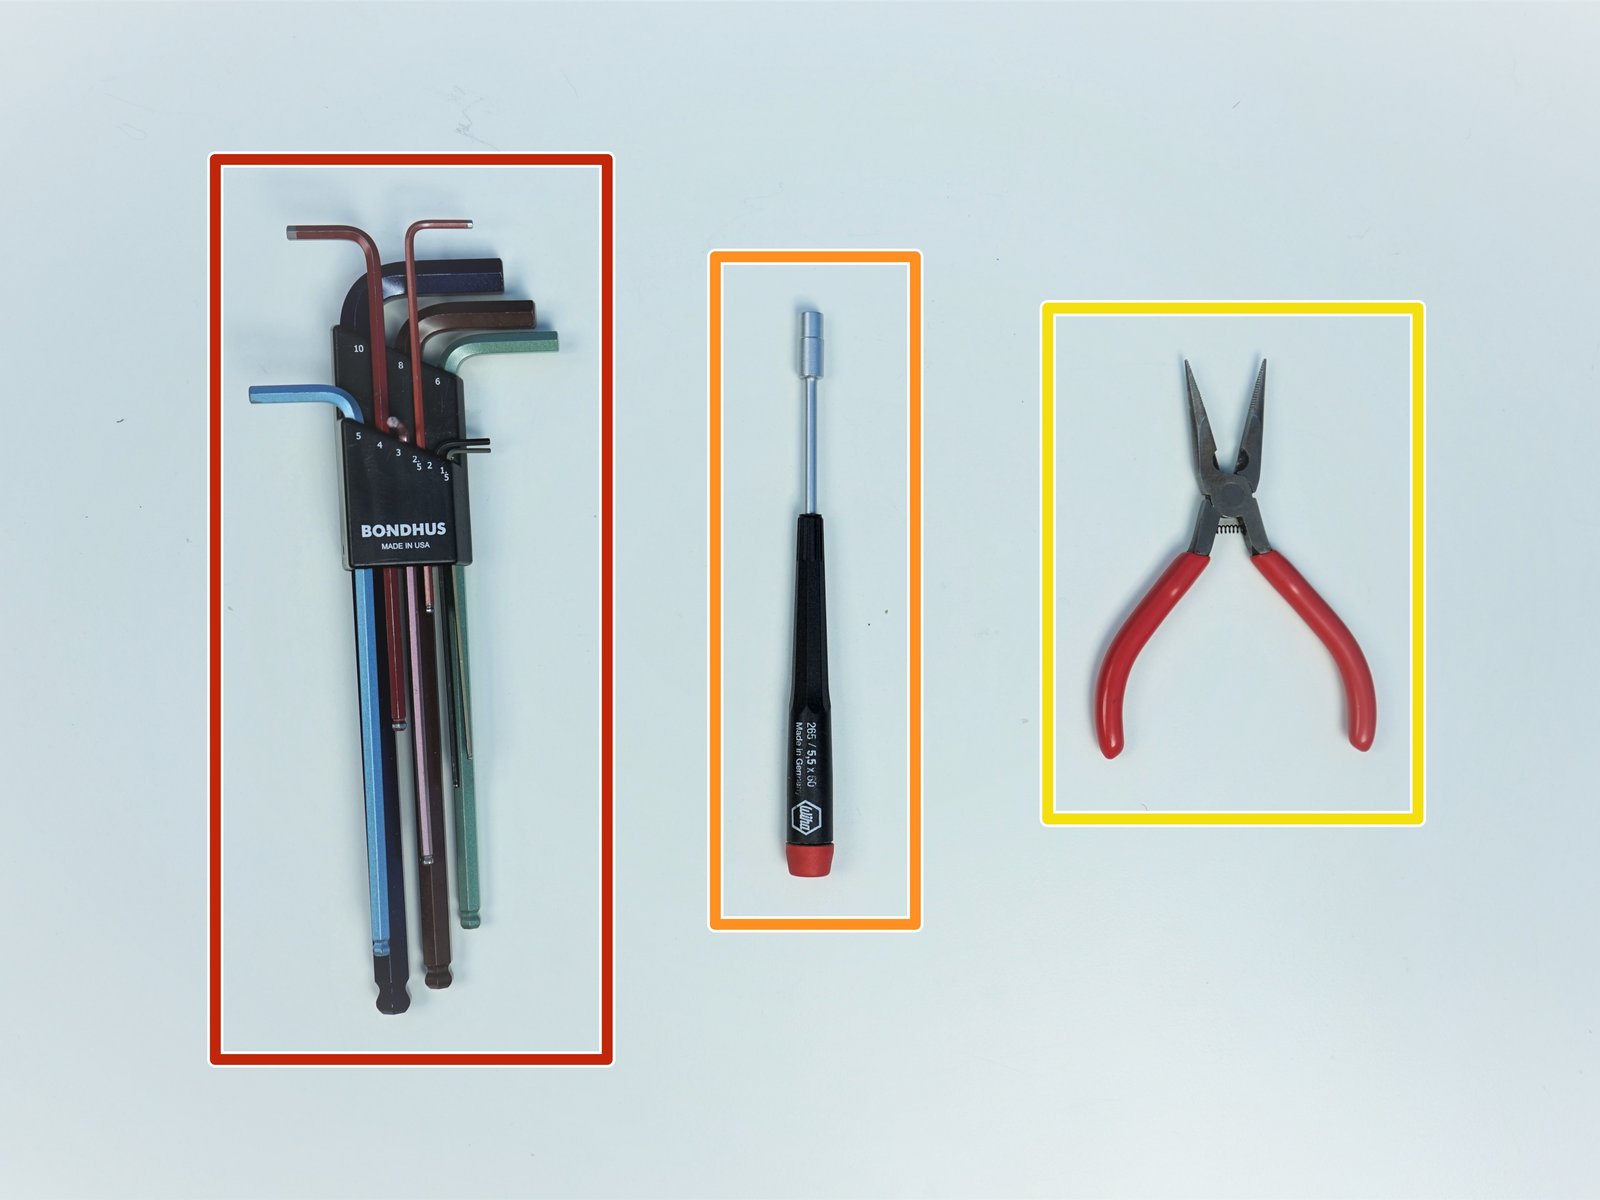
Click the large image to open full size.
Package #2
Alan Keys
Socket Head Driver
Plier [Opt.]
Step 2 Clamped Rotors - Parts and Notes
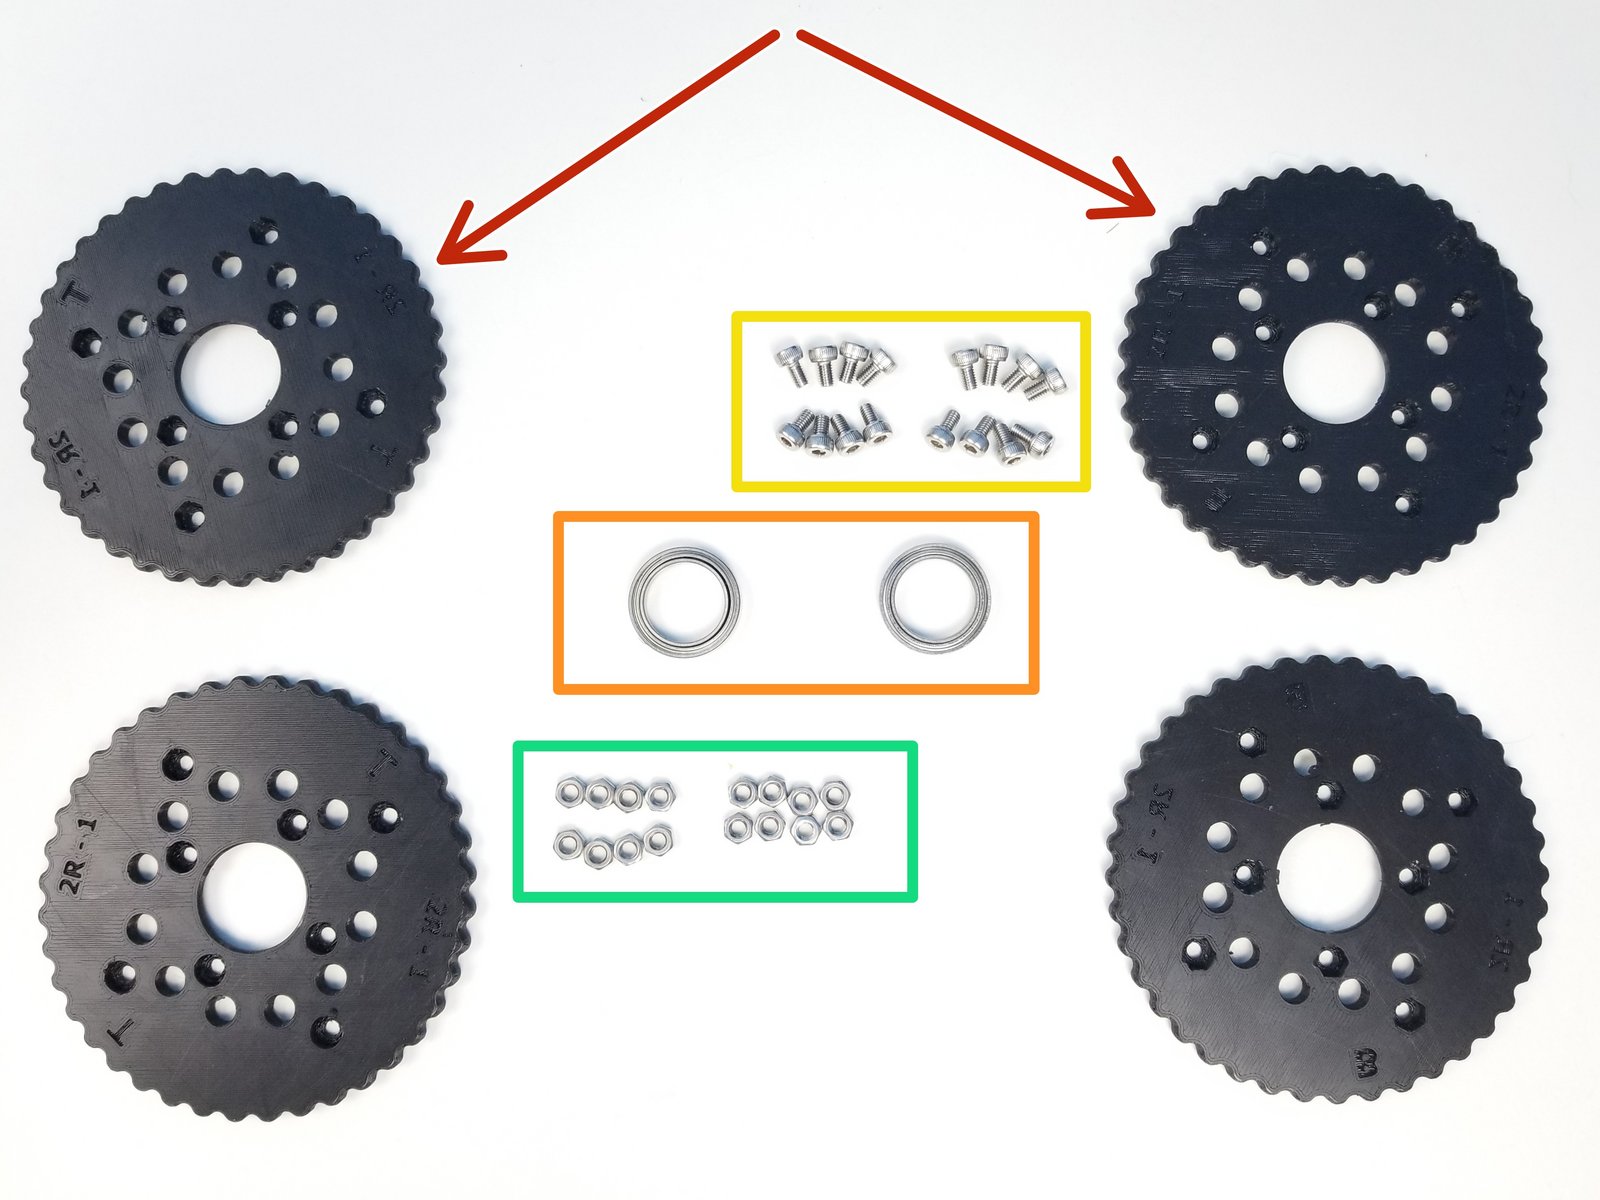
Click the large image to open full size.
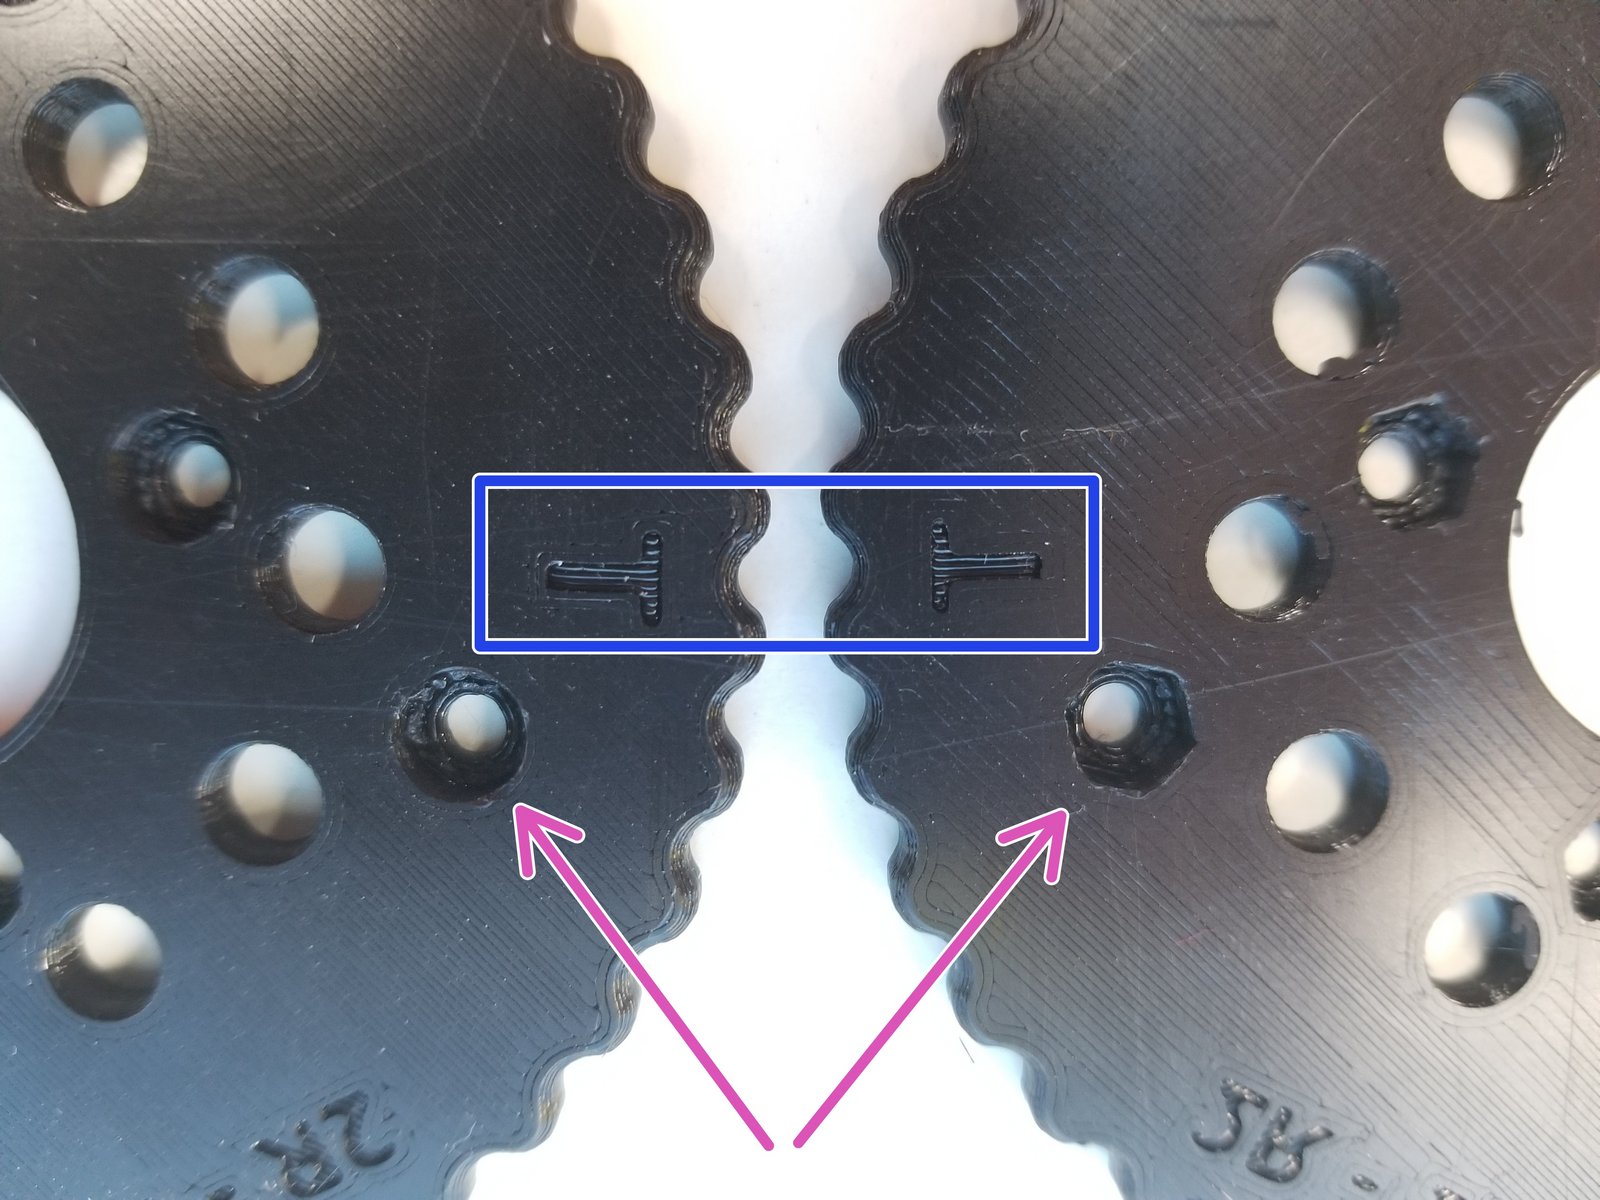
- Note:
Prepare the following components:
[3D] - 2GB Shoulder GB Rotors
6702 Bearings [15x21x4mm] (x2)
M3x5mm Screws (x16)
M3 Hex Nuts (x16)
- Note:
NOTE:
Shoulder Gearbox Rotor consist of 4 similar looking parts, Be aware of T Label and B Label
Also Be aware of the Nut Insert vs. Screw Head Insert
Step 3 Clamped Rotors
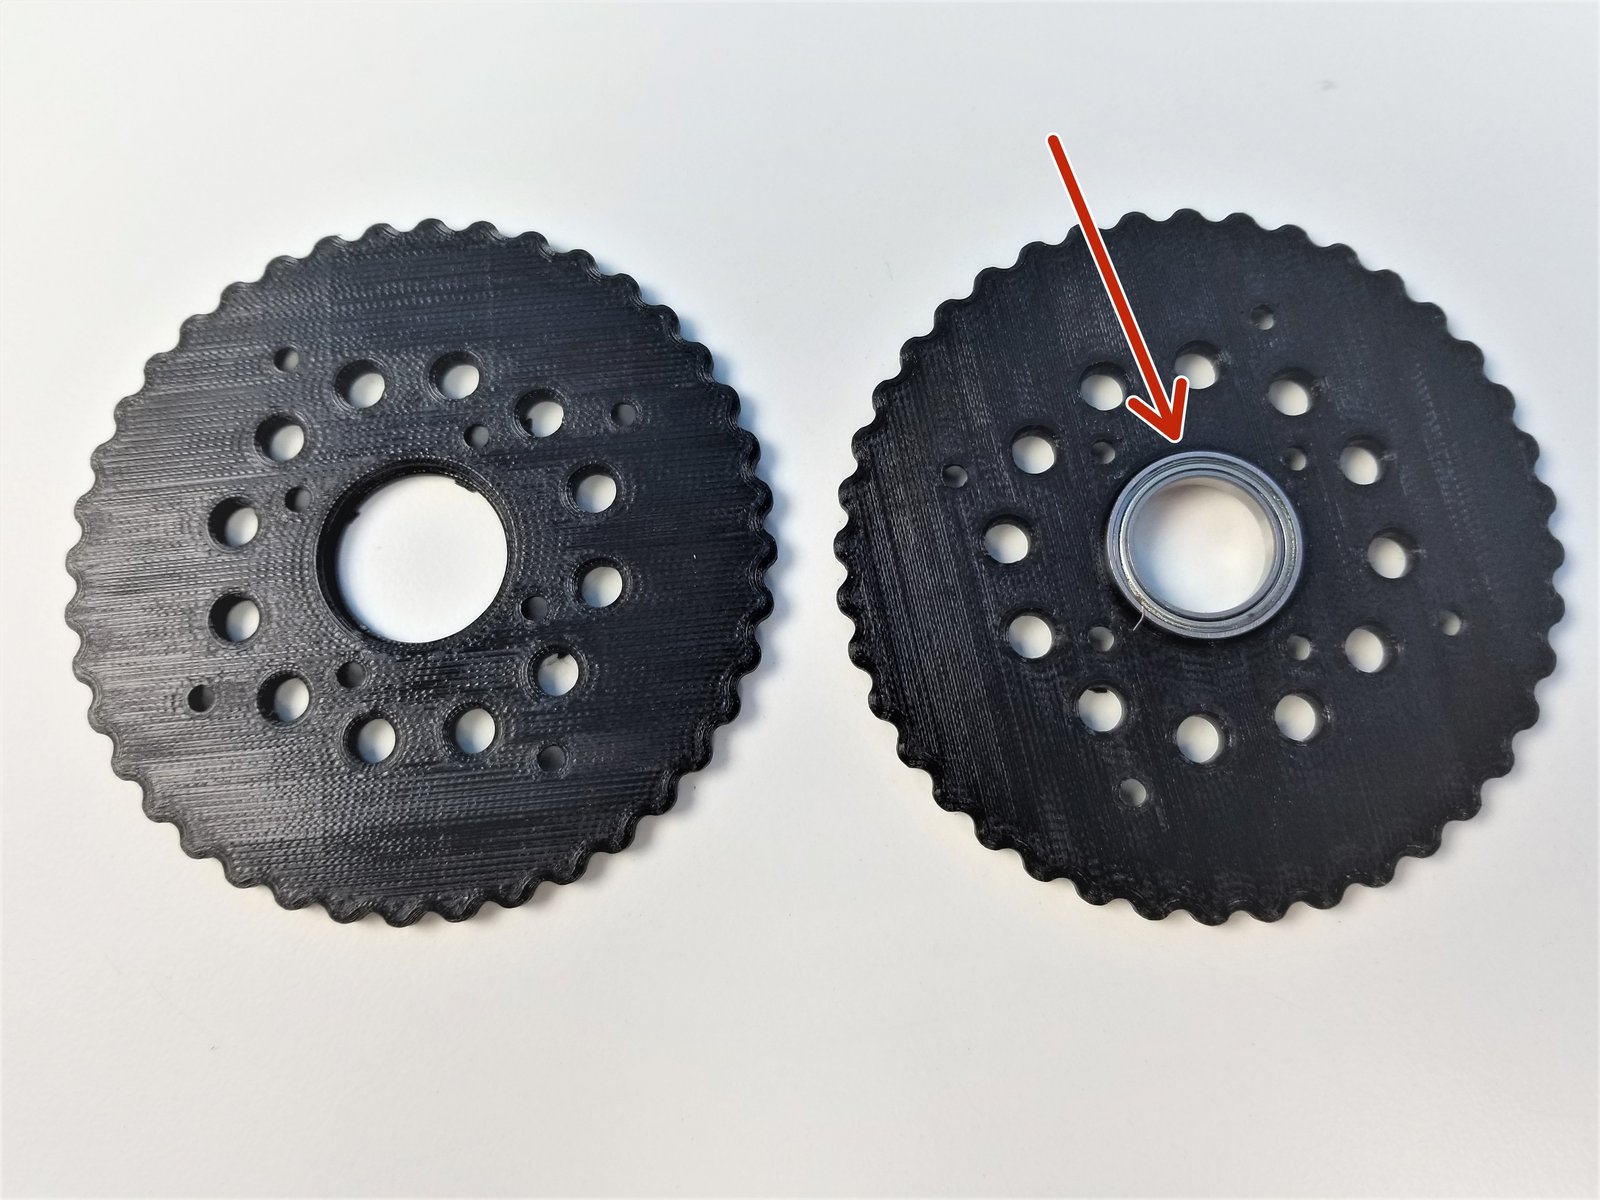
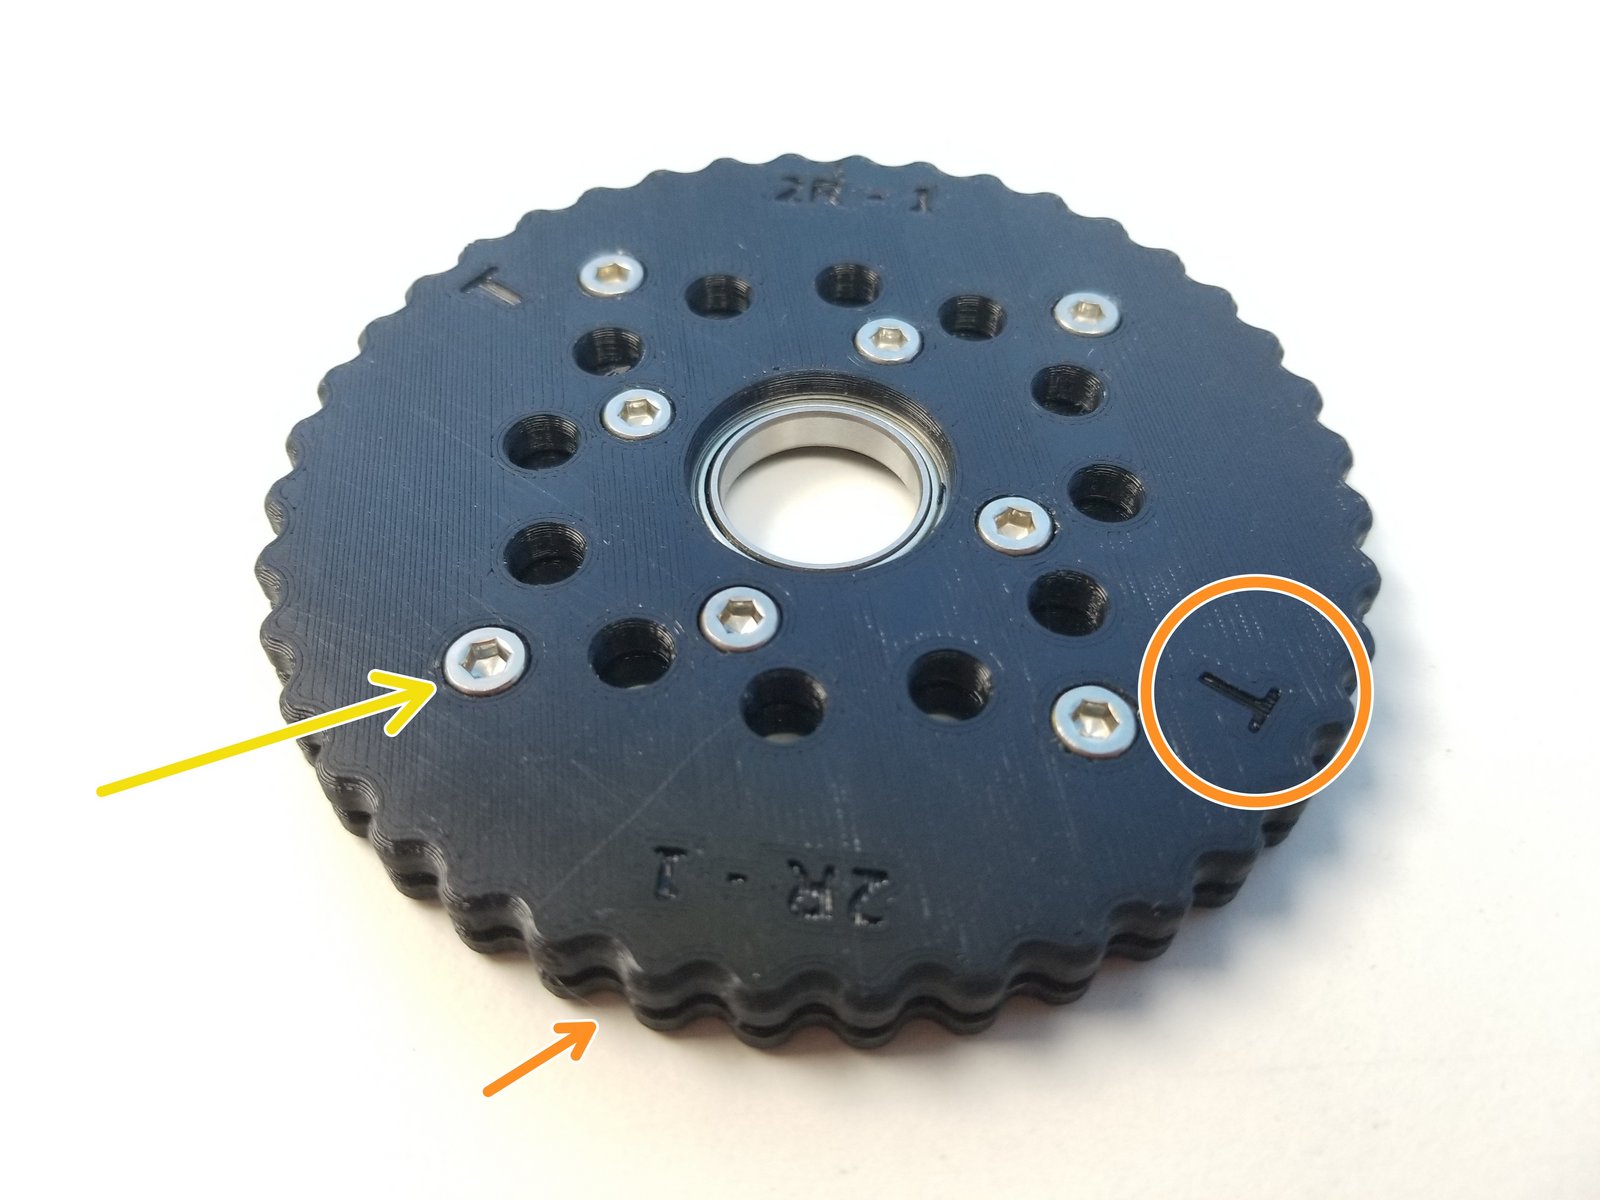
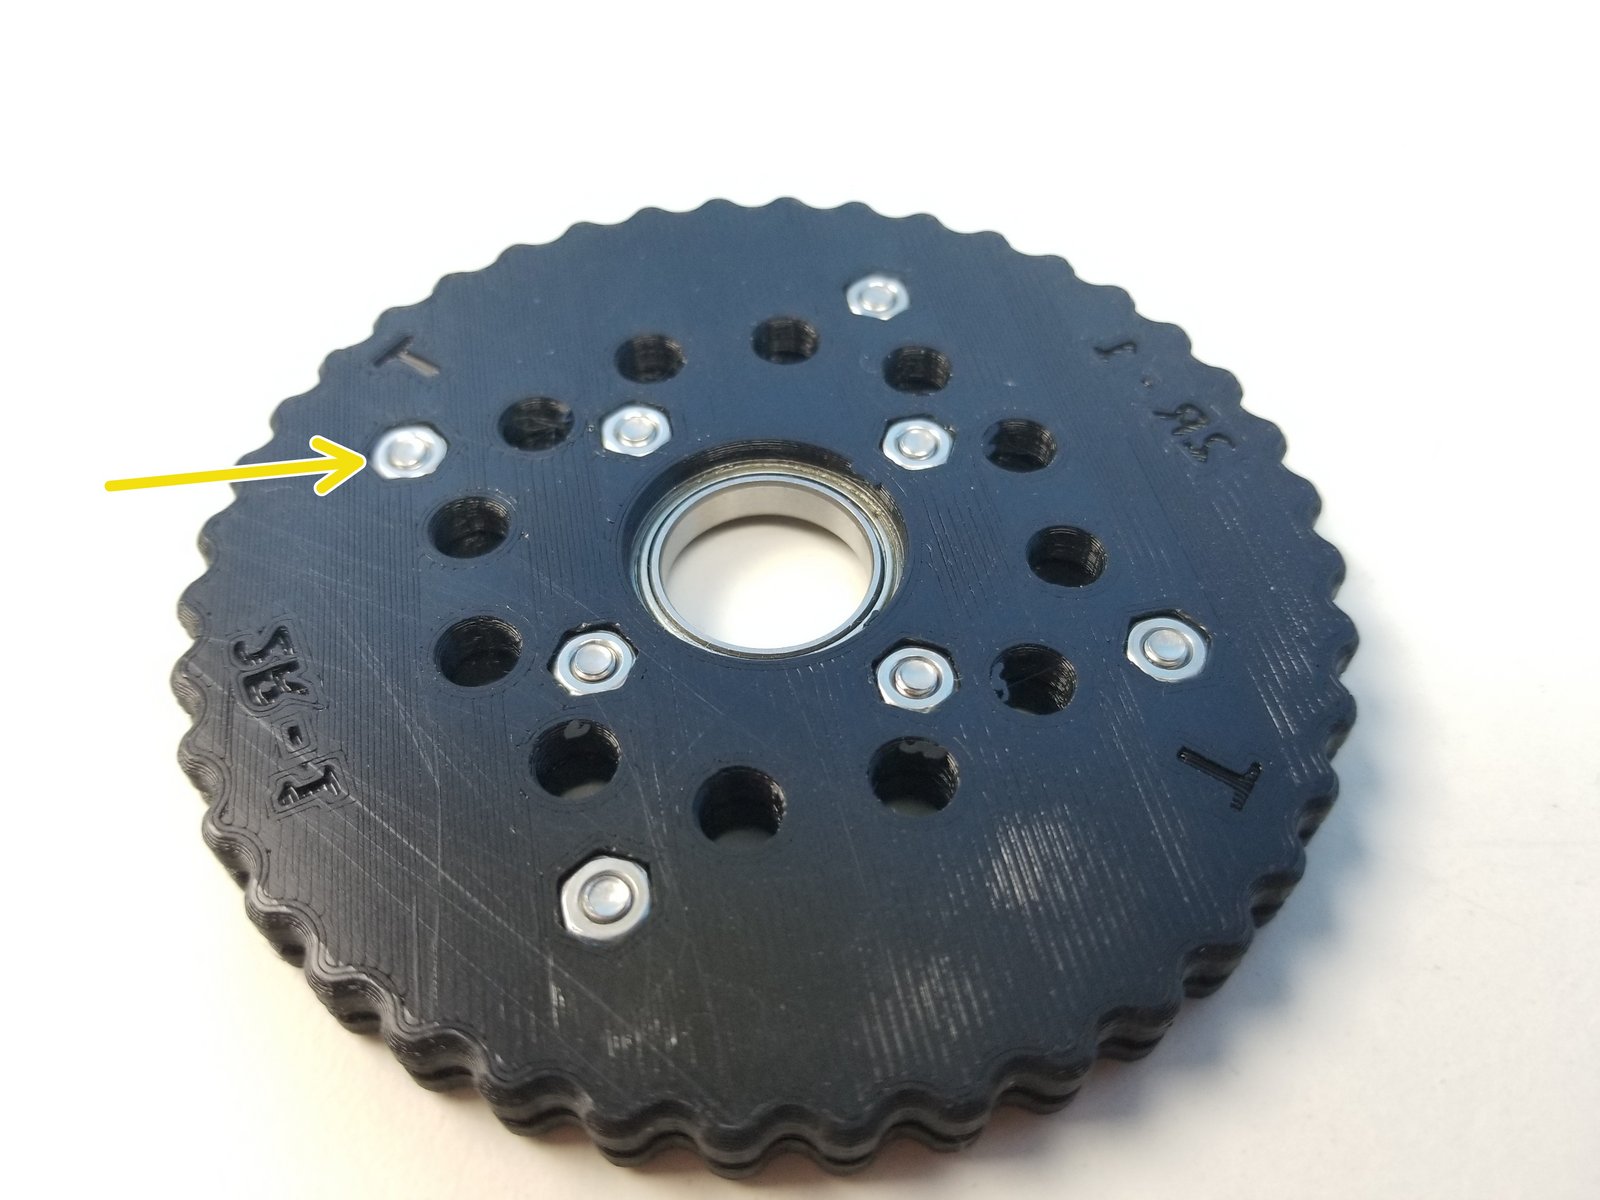
Click the large image to open full size.
- Note:
The process for "T" Rotor and "B" Rotor is the same. We will use T rotor as our guide and repeat the same process for B rotor
Insert 6702 Bearing on one half of the T Rotor
Place the other half and clamp the Bearing together
- Warning:
Make sure to align the T label, The holes and the teeth won't line up if this isn't done correctly.
Insert M3x5mm Screws and Hex Nuts on each half of the Rotor and tighten all the Screws.
- Note:
Repeat the same Process for B Rotor
Step 4 Eccentric Input Shaft - Parts
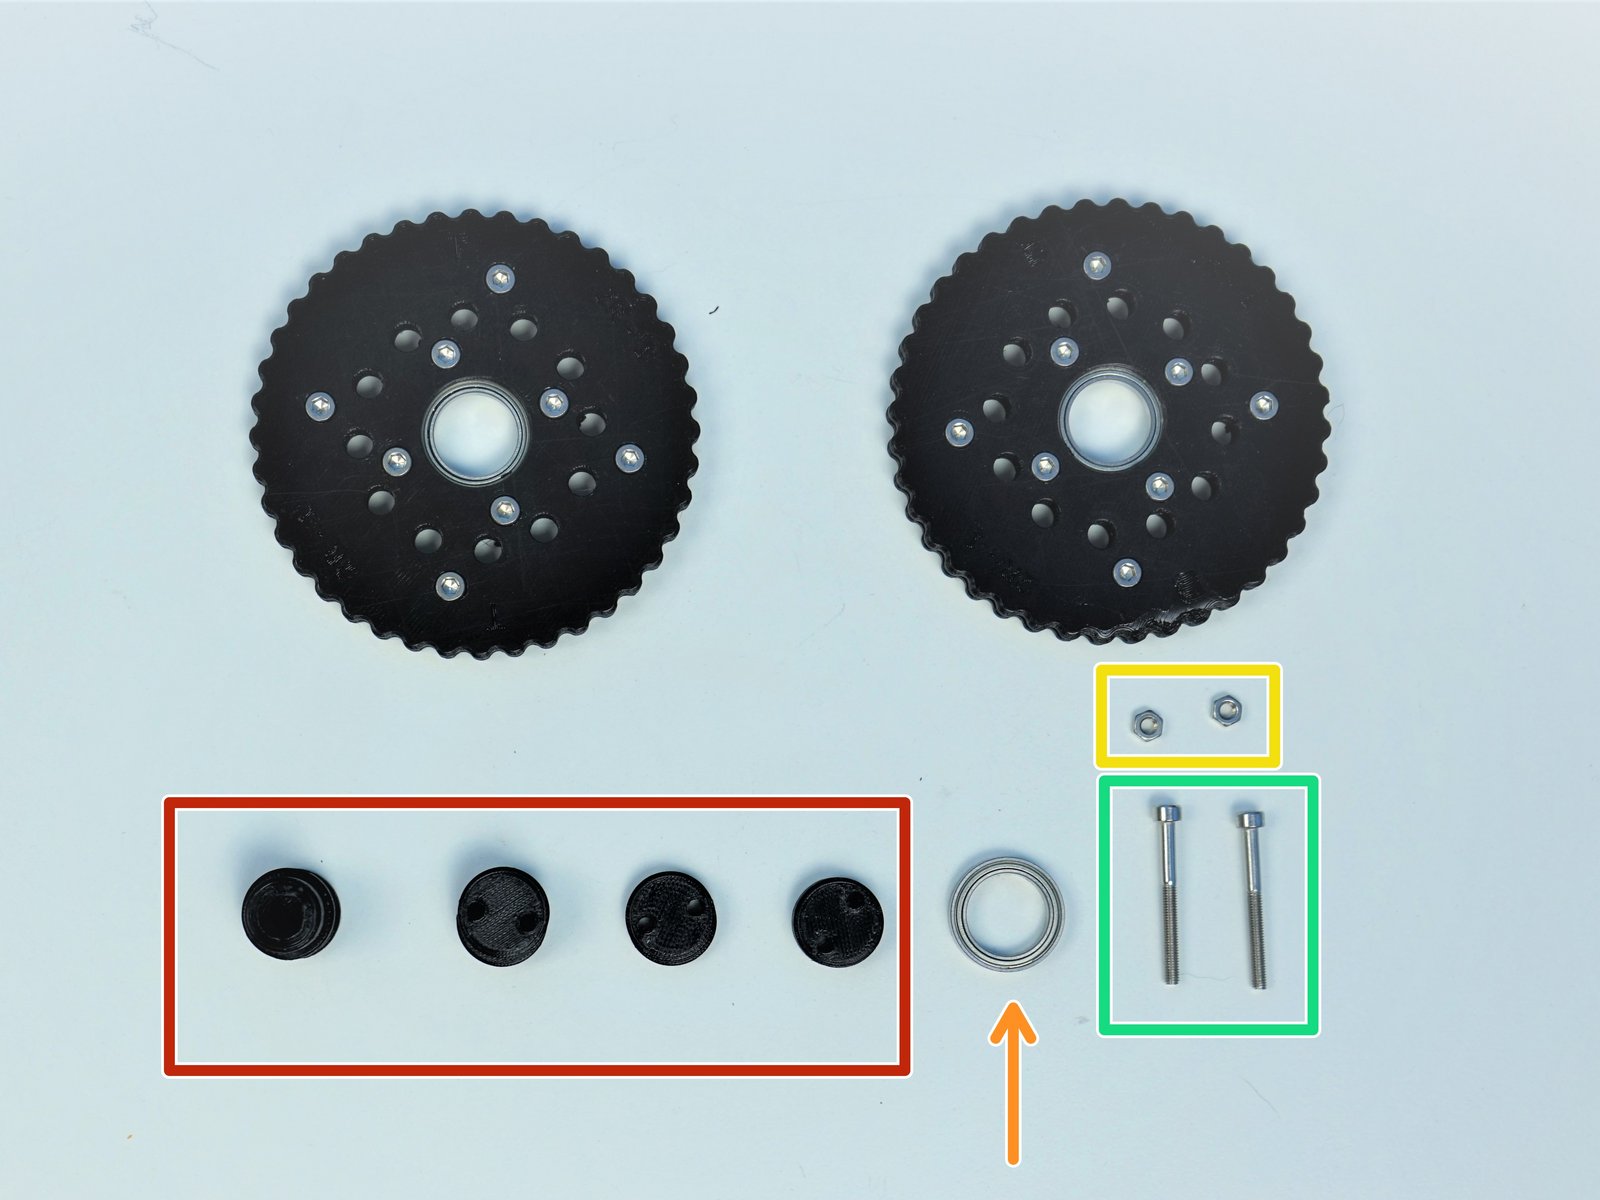
Click the large image to open full size.
- Note:
Prepare the following components:
Assembled Rotors
[3D] - 2GB Eccentric Shafts
6702 Bearing [15x21x4mm] (x1)
M3 Hex Nuts (x2)
M3x30mm Screws (x2)
Step 5 Eccentric Input Shaft - Notes
Click the large image to open full size.
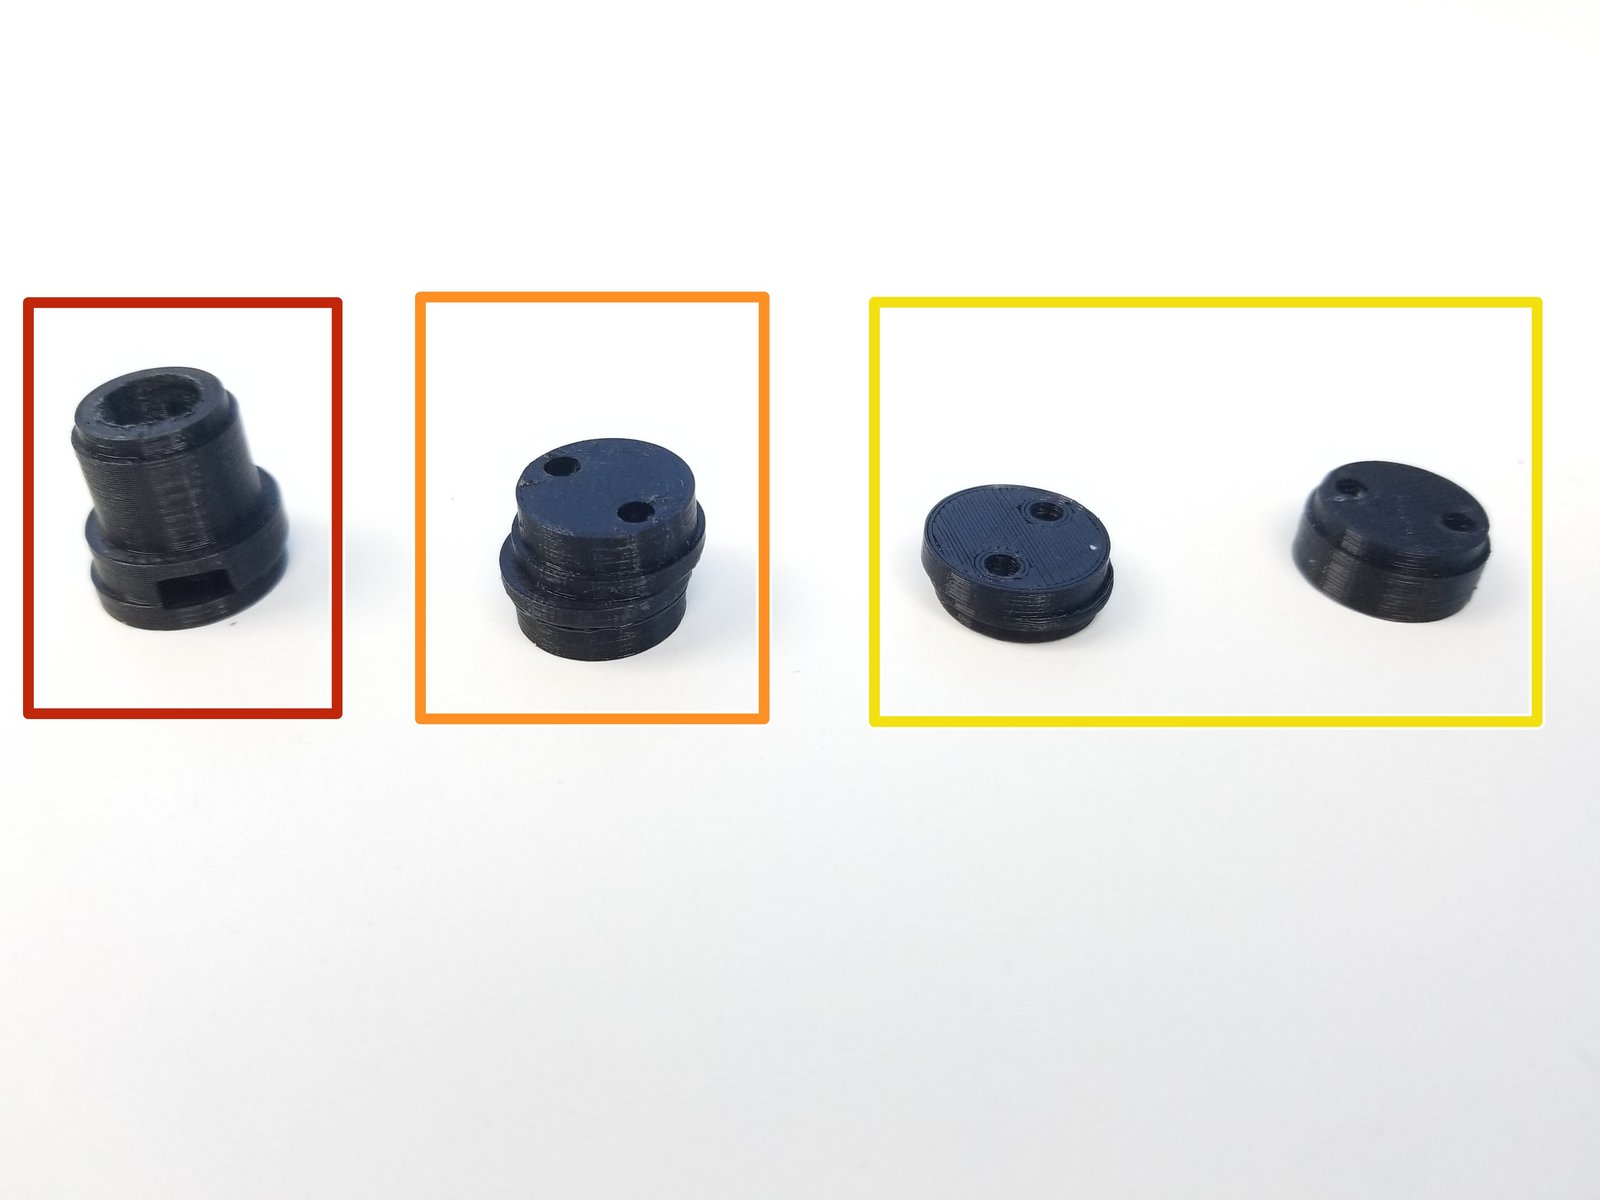
Input Shaft Consist of 4 components:
Motor Shaft Coupler
Eccentric Cam
Shaft Holder Cams (thin piece & thicker concentric piece)
- Note:
Shaft Holder Cams prevent the input shaft to go off on the axis of rotation
Step 6 Eccentric Input Shaft - 1
Click the large image to open full size.
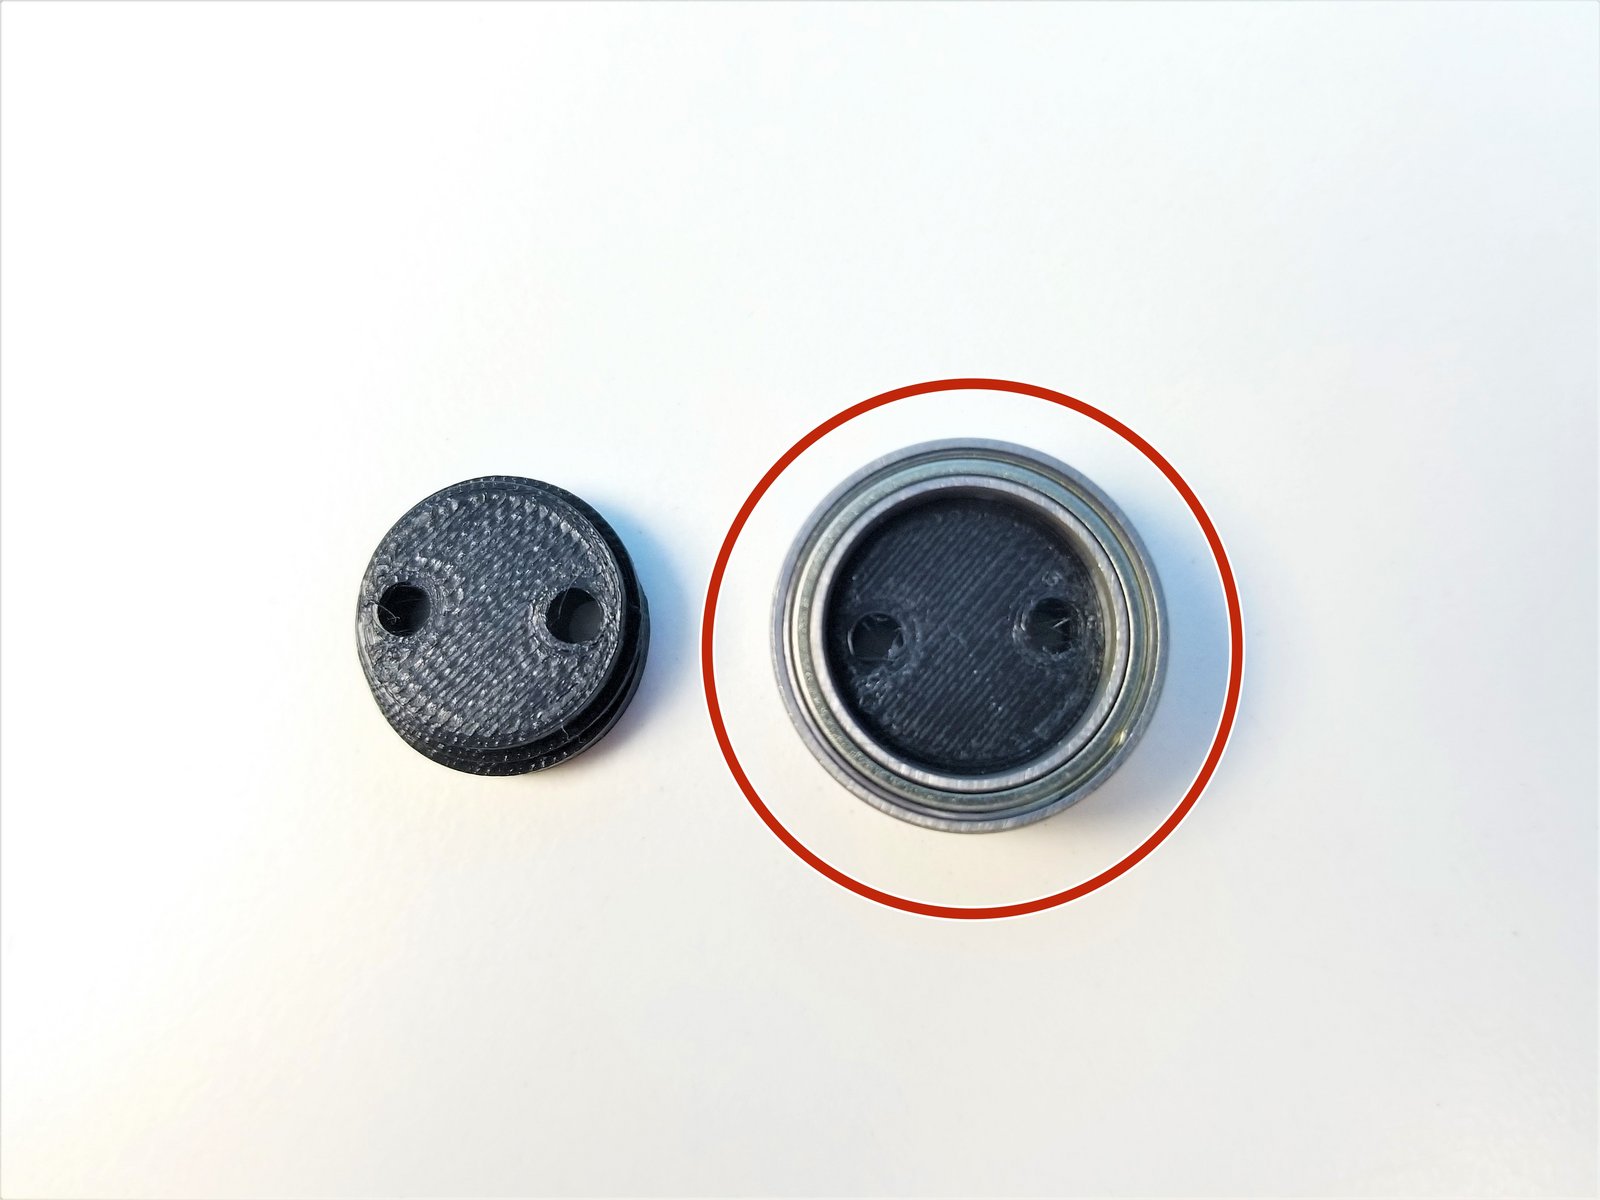
Put the 6702 Bearing on the Thicker Concentric piece of the Shaft Holder
- Note:
Notice that the thinner piece of the Shaft Holder has 2 sides, one where screw lined up to the center of the face and other which is eccentric
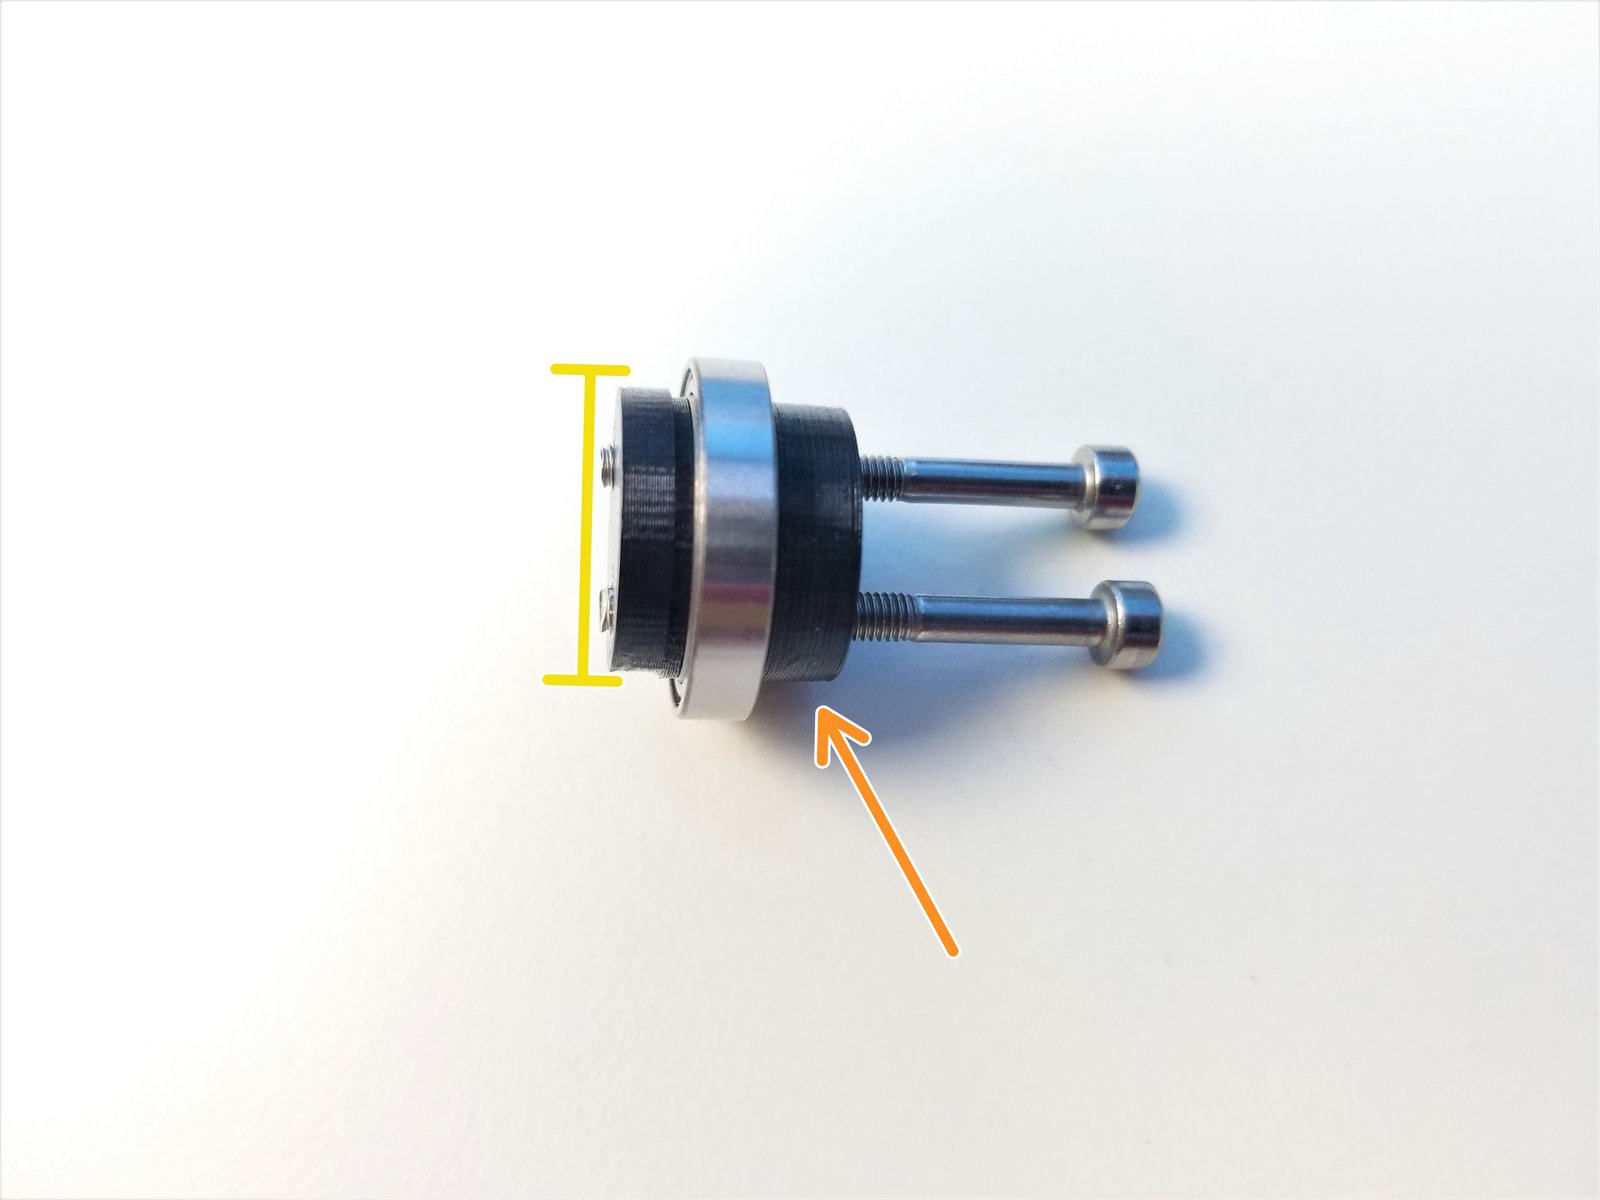
Clamp Shaft Holder Cam pieces using M3x30mm Screws
Thicker piece is the Screw Head side,
Only screw in until the tip of the screw is flushed with the face of the thinner piece
Step 7 Eccentric Input Shaft - 2
Click the large image to open full size.
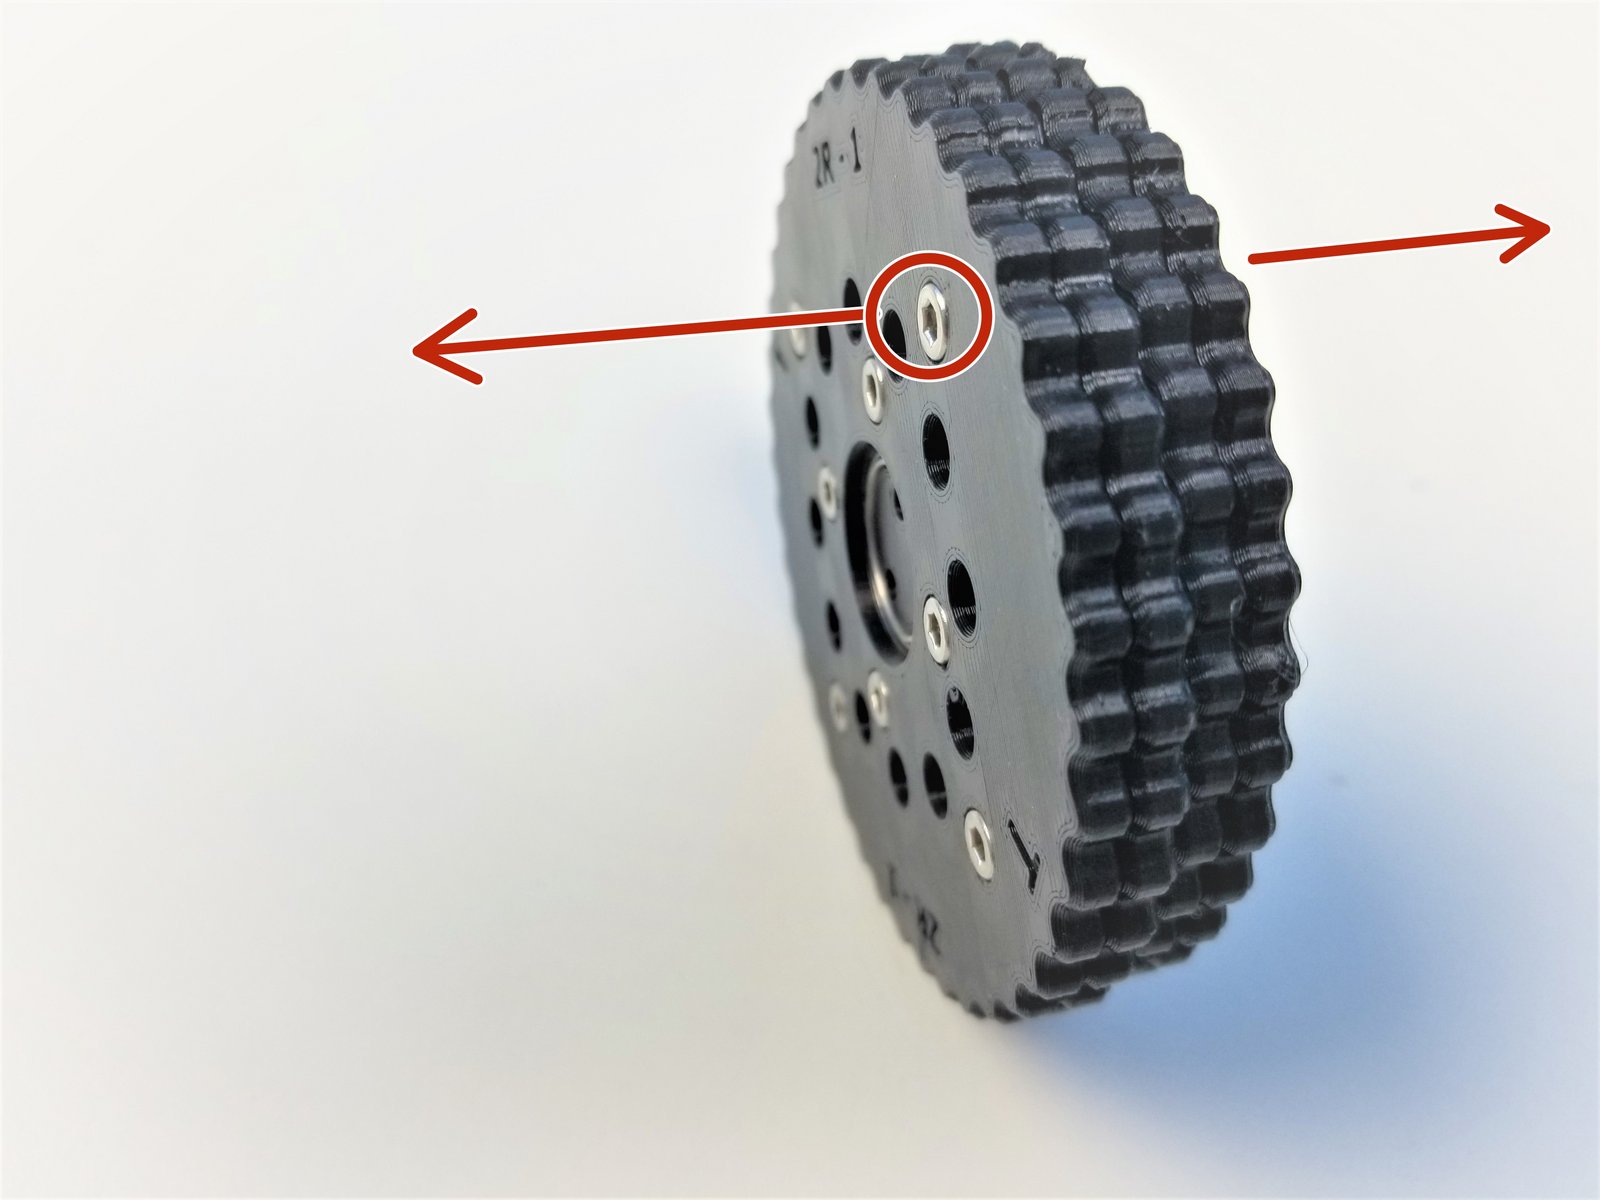
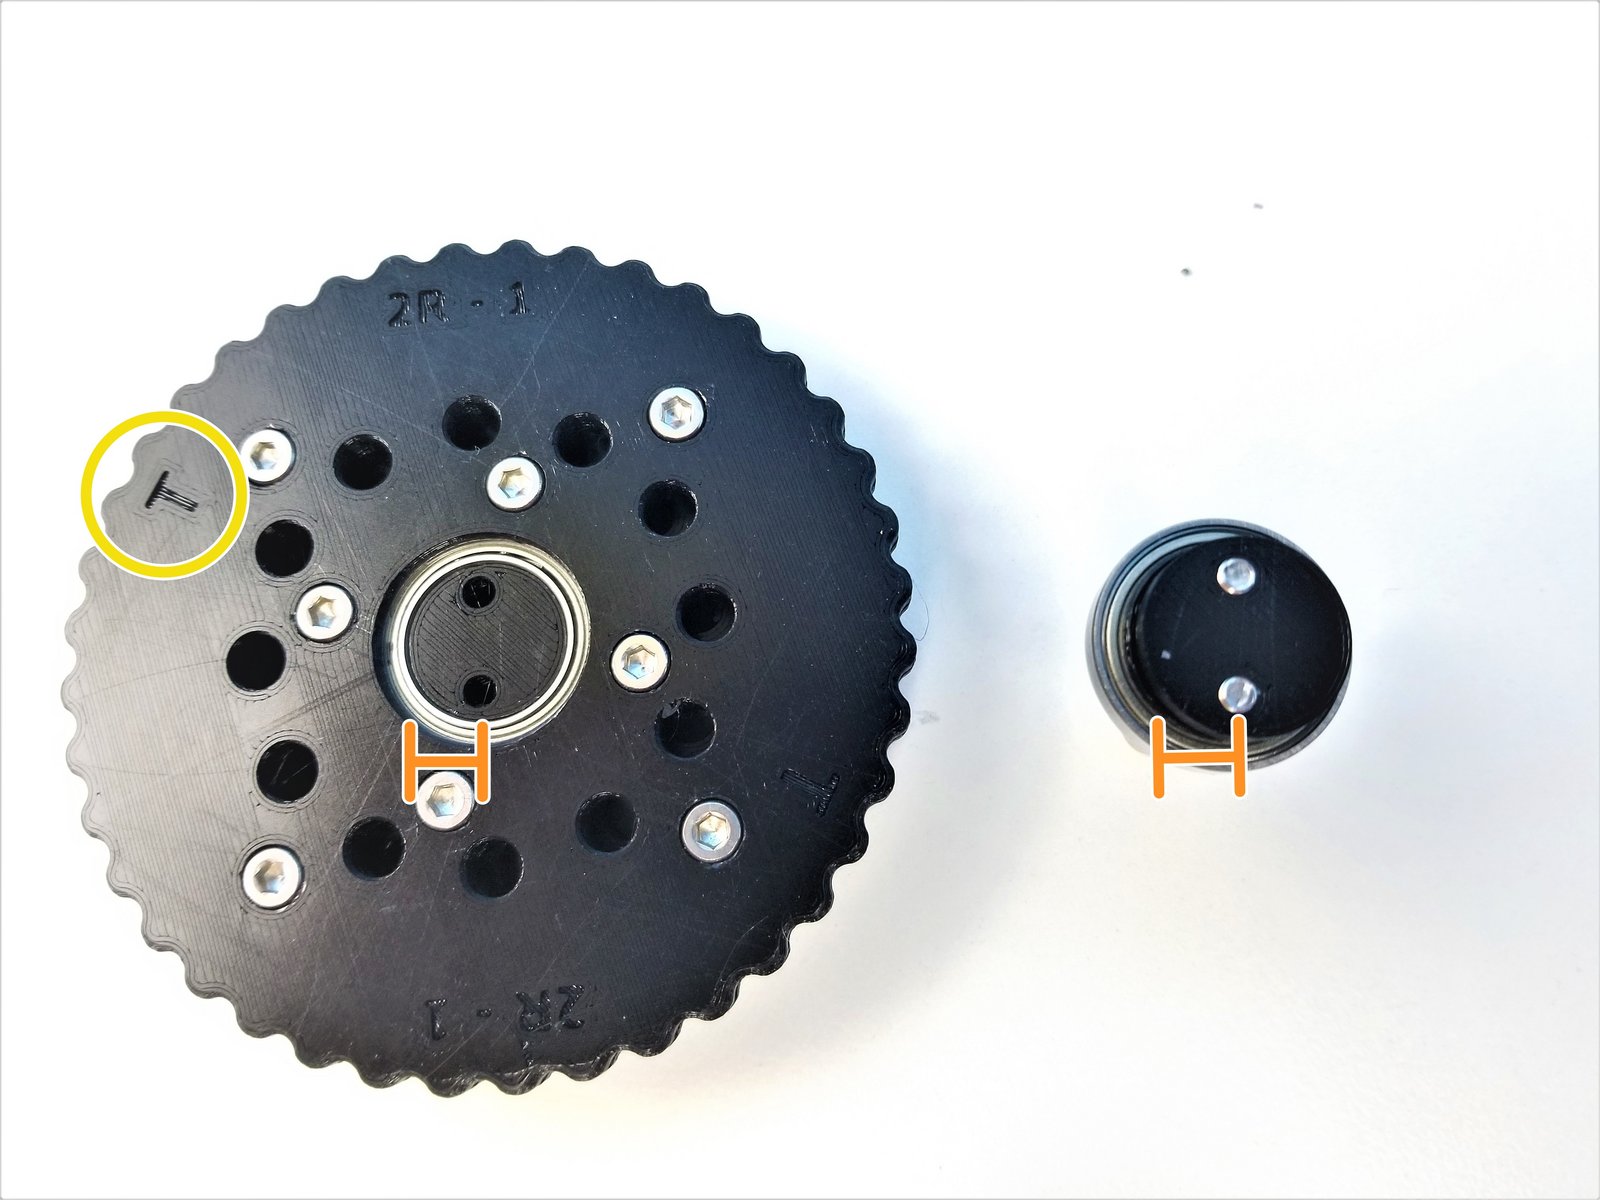
Insert Top & Bottom Rotors on the Eccentric Cam
The Screw Head side of each rotor is facing away from each other
Align the Eccentric Cam and Shaft Holder Cams and partially screw in the M3x30mm Screws.
Check that the T Rotor is facing the Shaft Holder Cam
Step 8 Eccentric Input Shaft - 3
Click the large image to open full size.
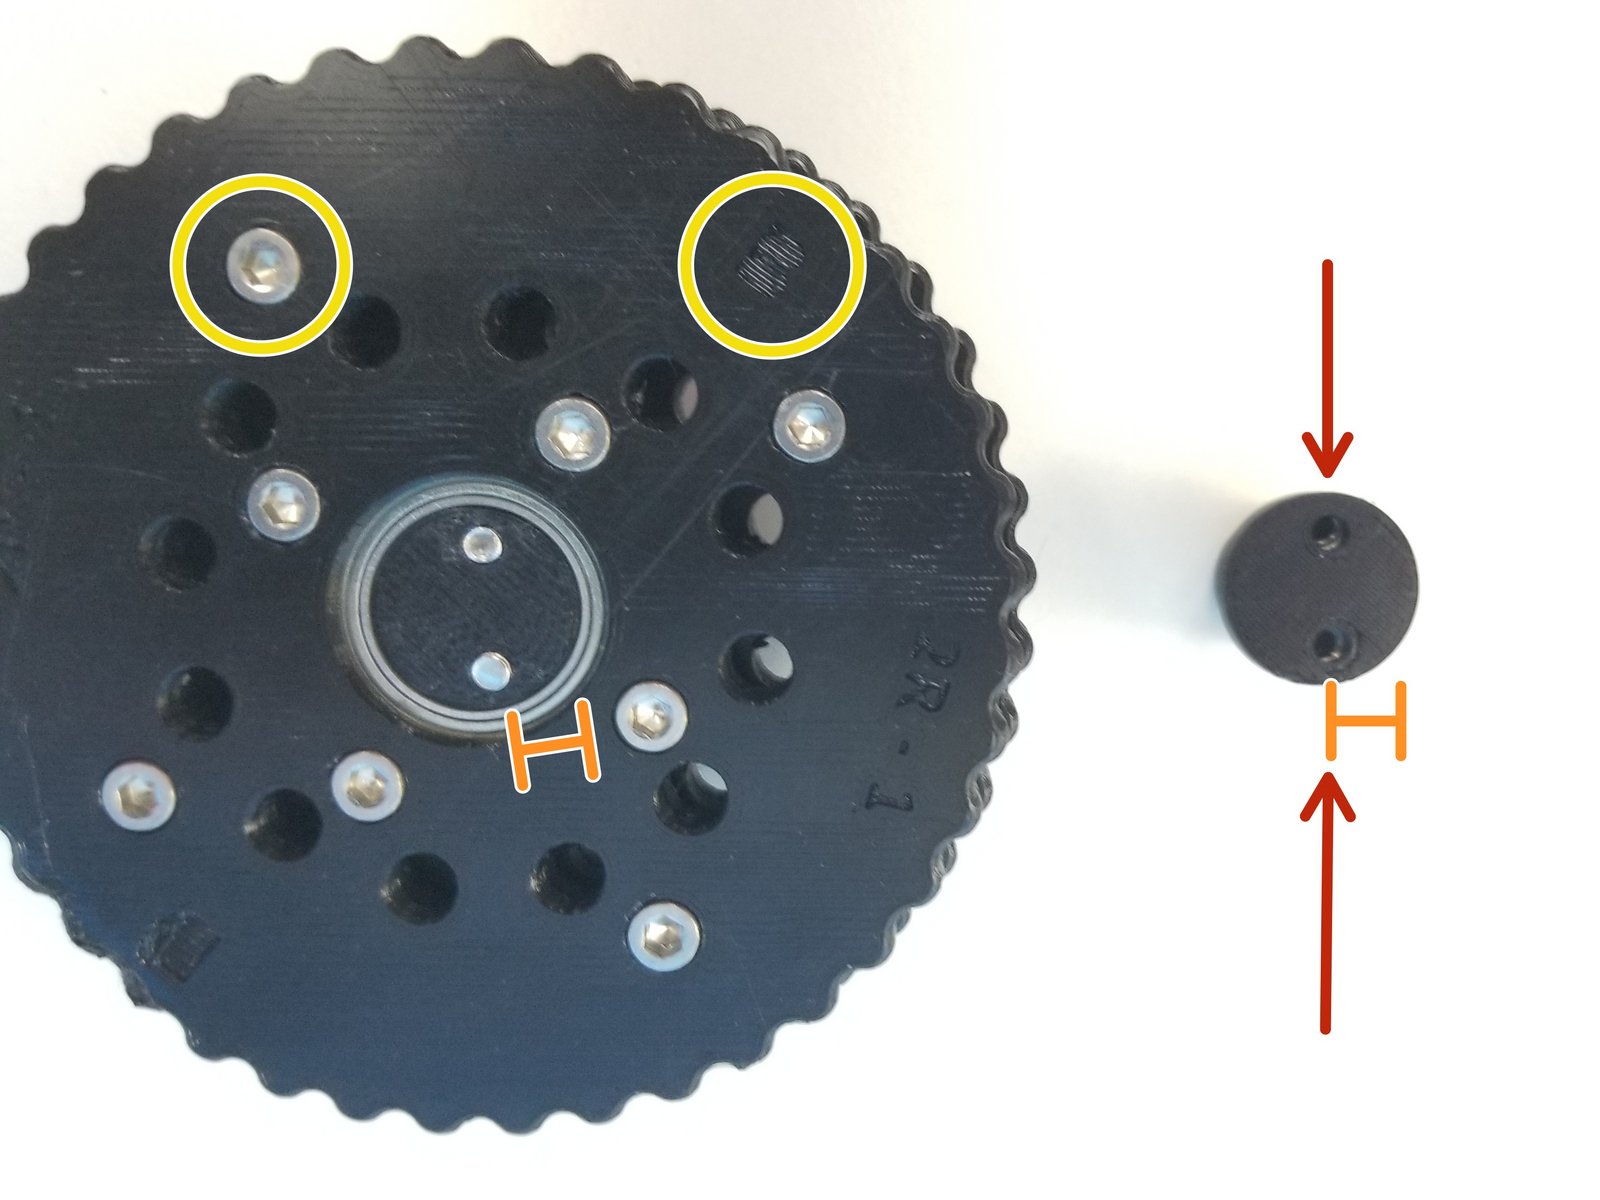
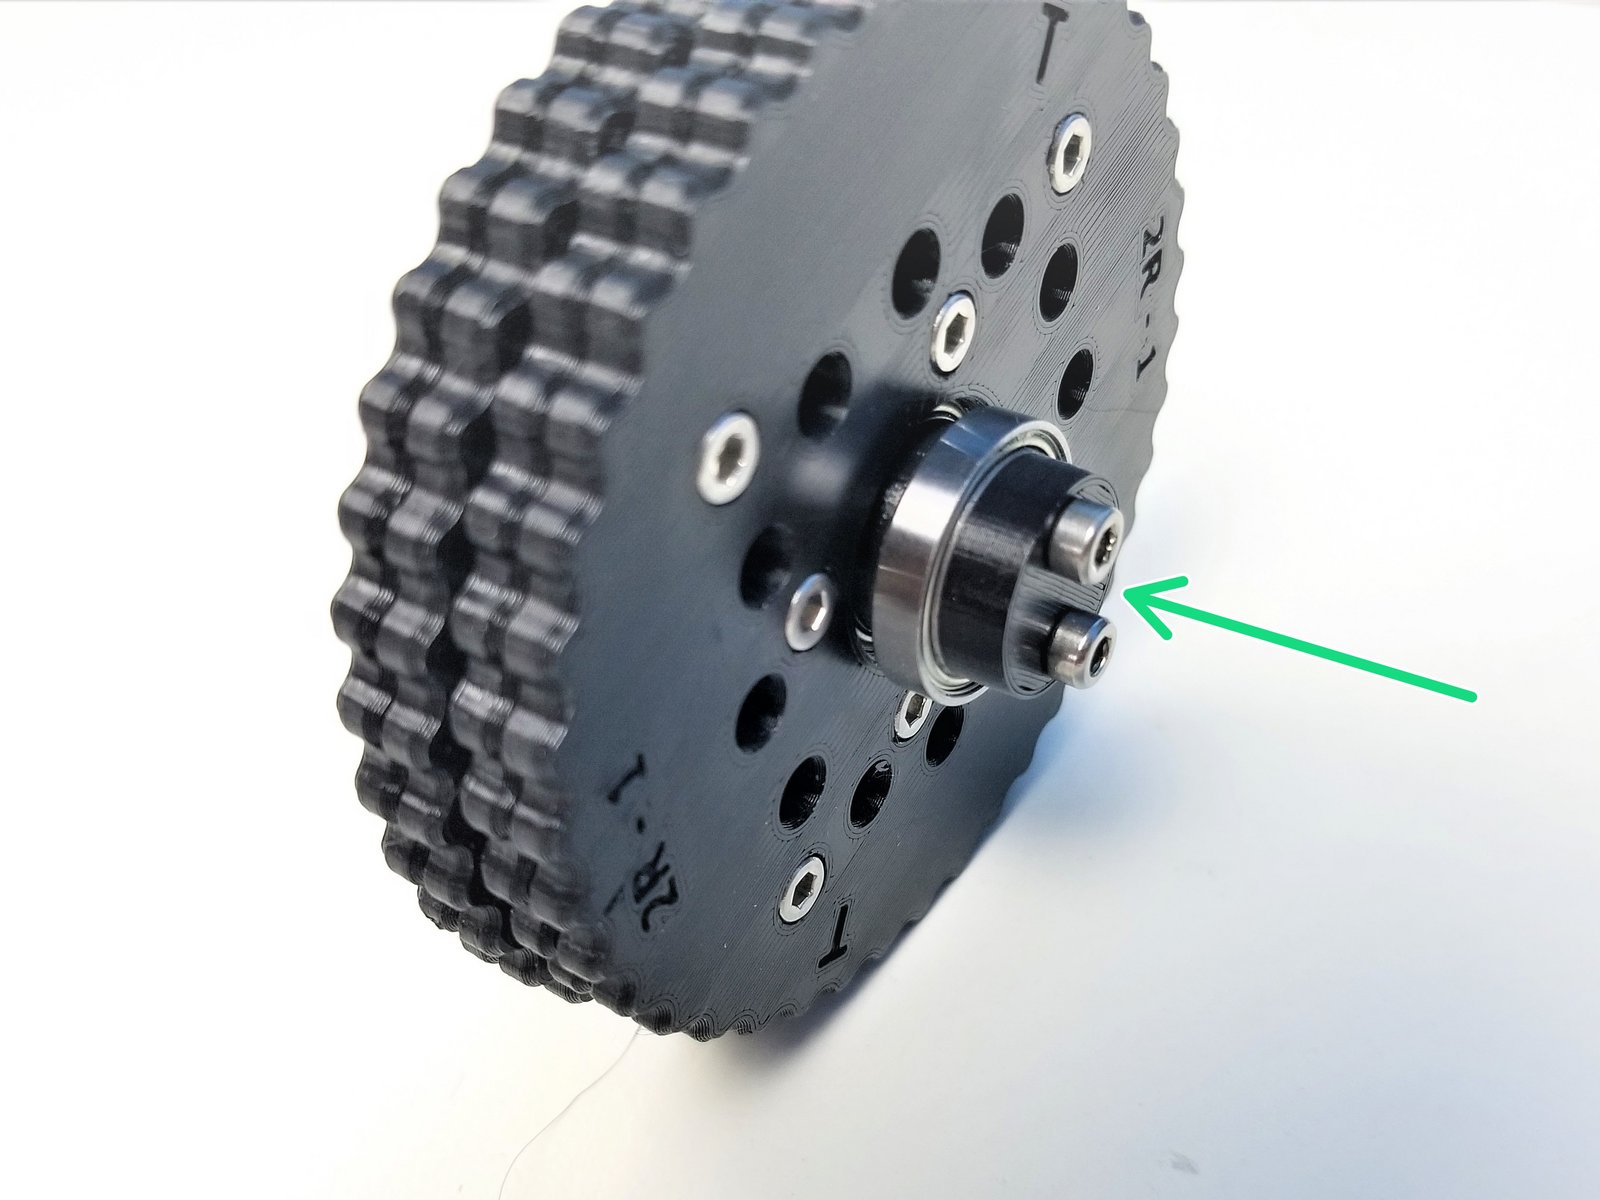
Insert M3 Hex nuts on the side of the Motor Shaft Coupler
Align the Coupler offset and Eccentric Cam offset
Make sure the B Rotor and its Screw Head side facing the Coupler
Screw in the rest and Tighten it
Step 9 Shoulder Gearbox Housing - Parts
Click the large image to open full size.
- Note:
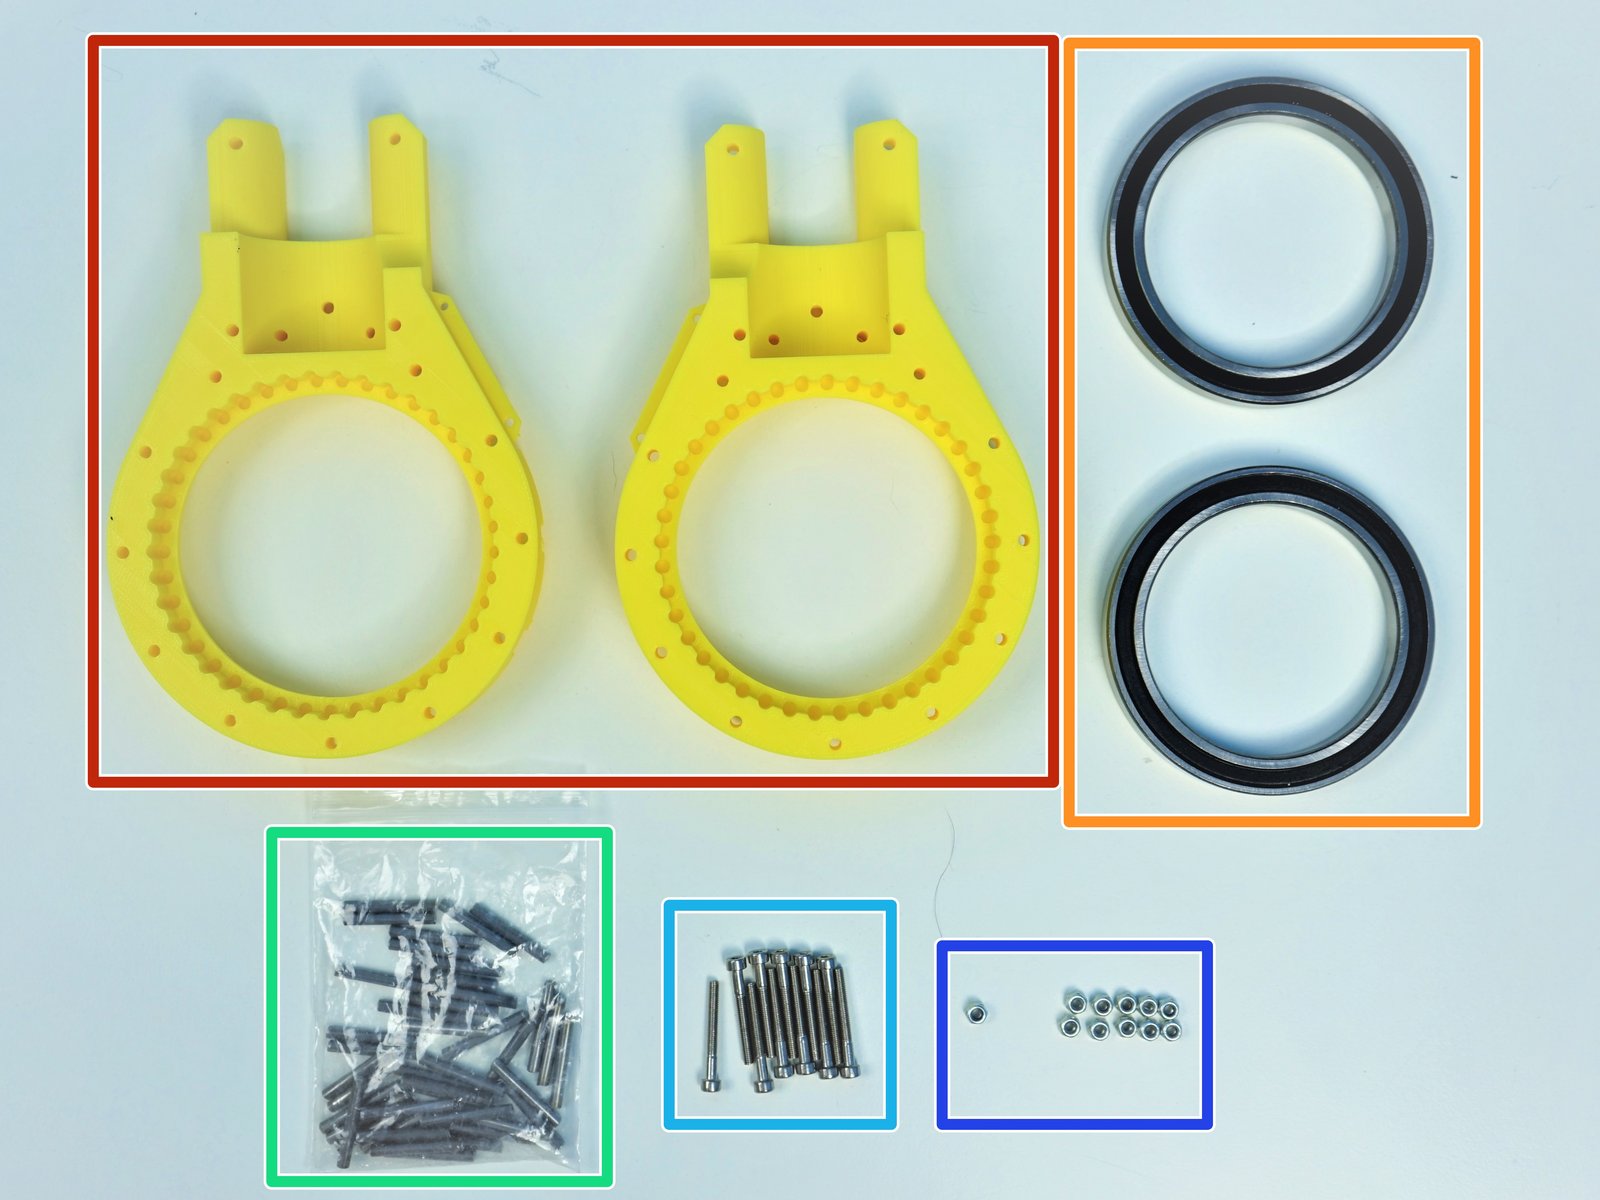
Prepare the following components:
Assembled Input Shaft and Rotors
[3D] - 2GB Shoulder GB Housing Top Halves
6813 Bearings [65x85x10mm] (x2)
Steel dowel pin 91595A130 - [3x24mm] (x41)
M3x25mm Screws (x11)
M3 Nylock Nuts (x11)
Step 10 Shoulder Gearbox Housing - Housing Preparation
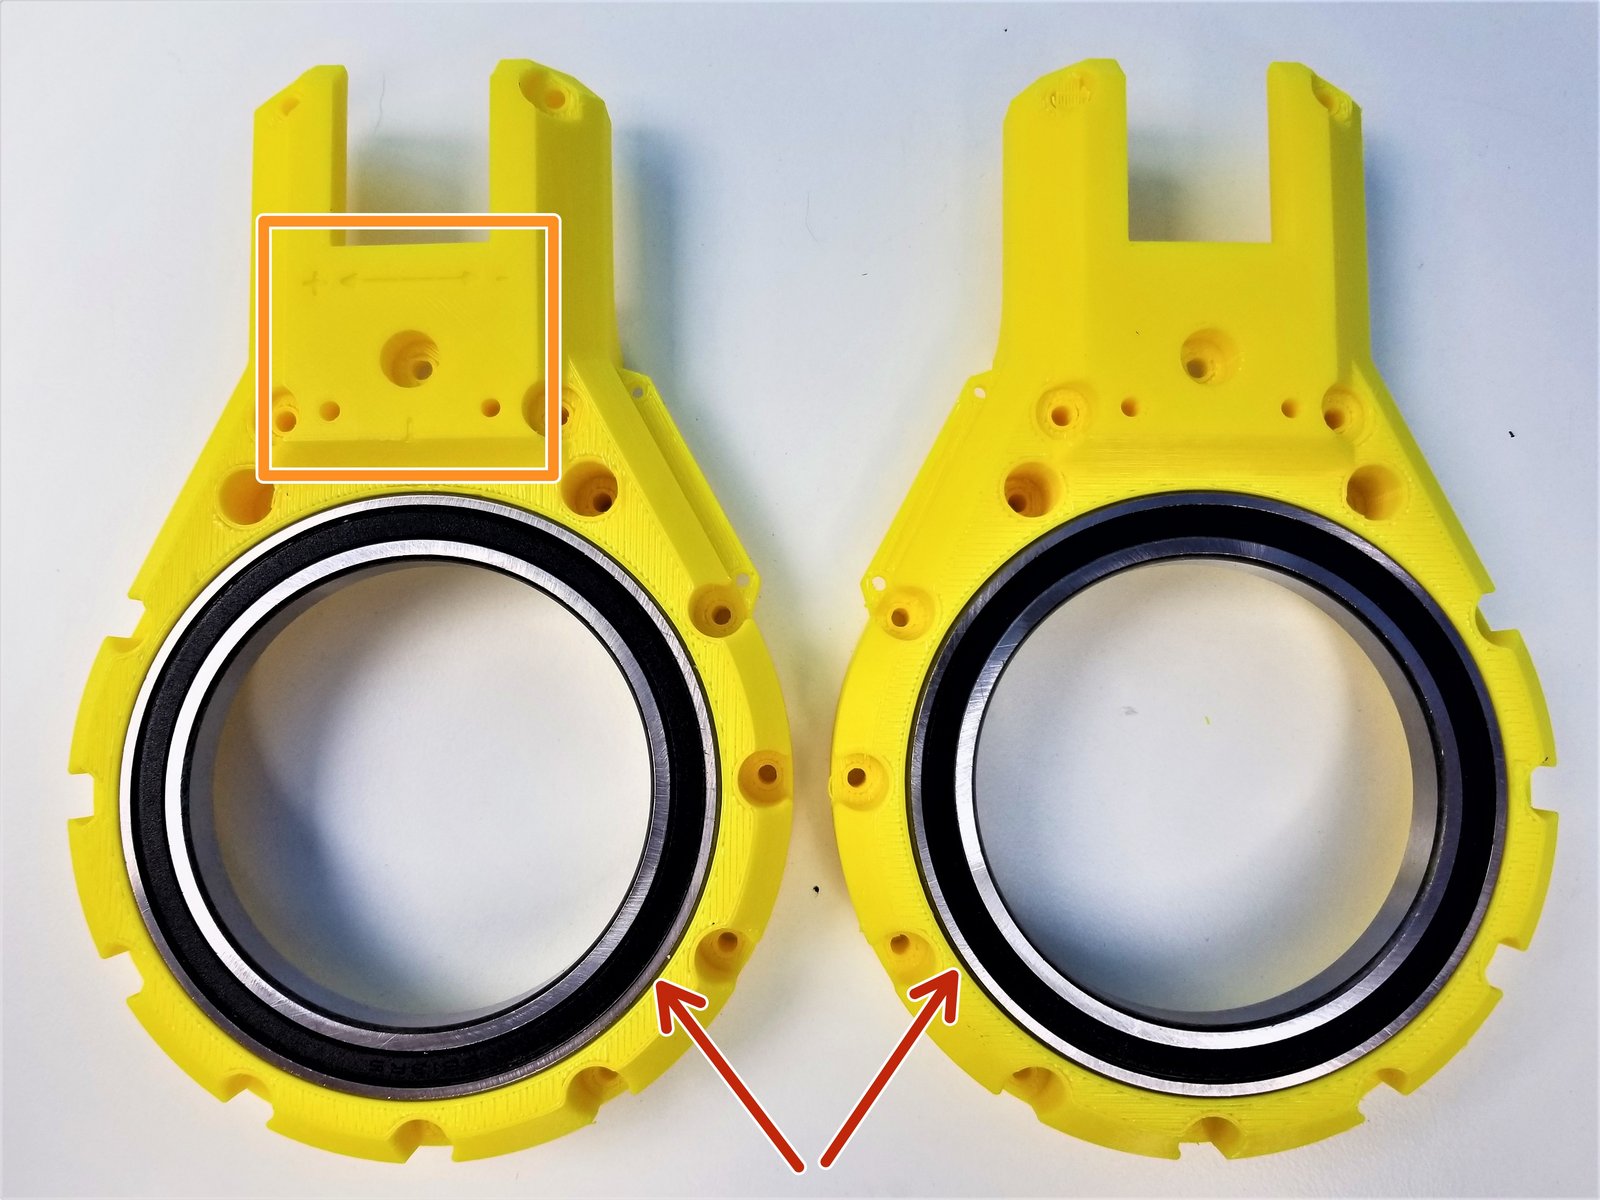
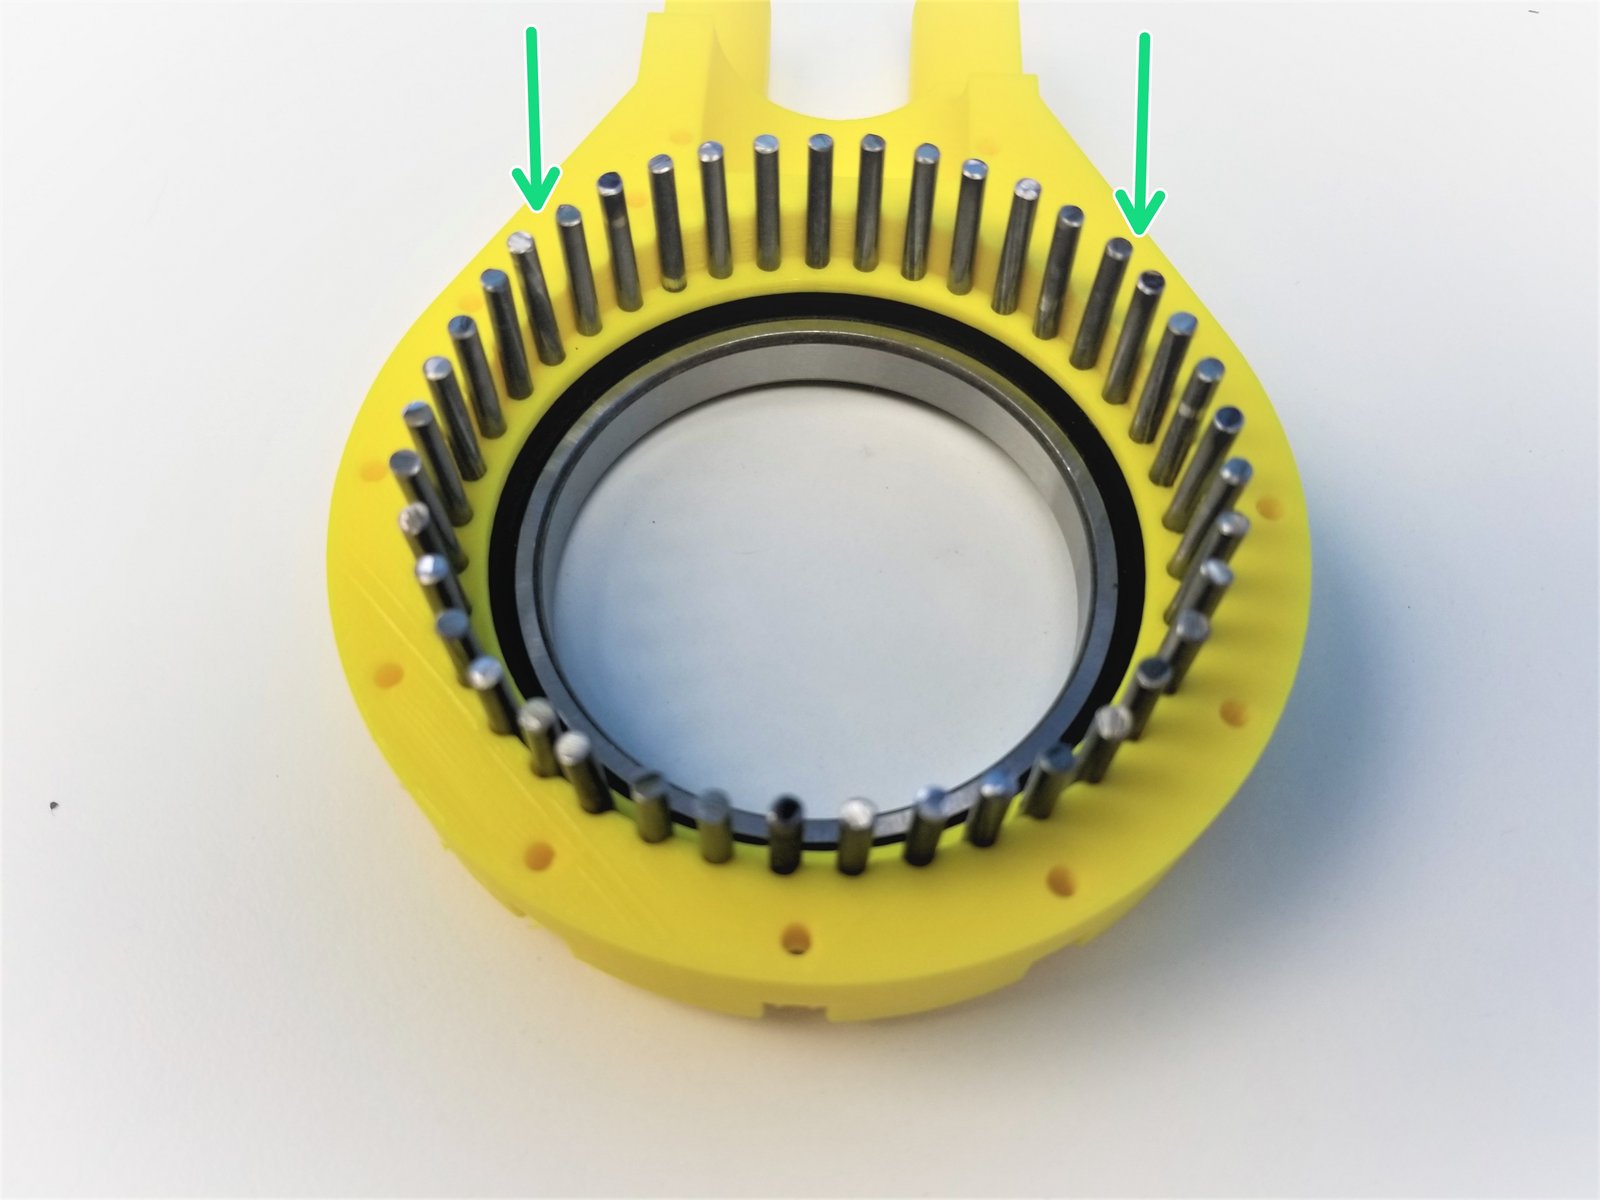
Click the large image to open full size.
Insert 6813 Bearings on the Housing parts
- Note:
3D-printed housing parts consist of a motor side part and a sensor side part
The side with Directional Label is the Motor Side
Insert all 41 Steel Pins on the Sensor Side Half of the Housing.
Step 11 Shoulder Gearbox Housing - Rotor Alignment
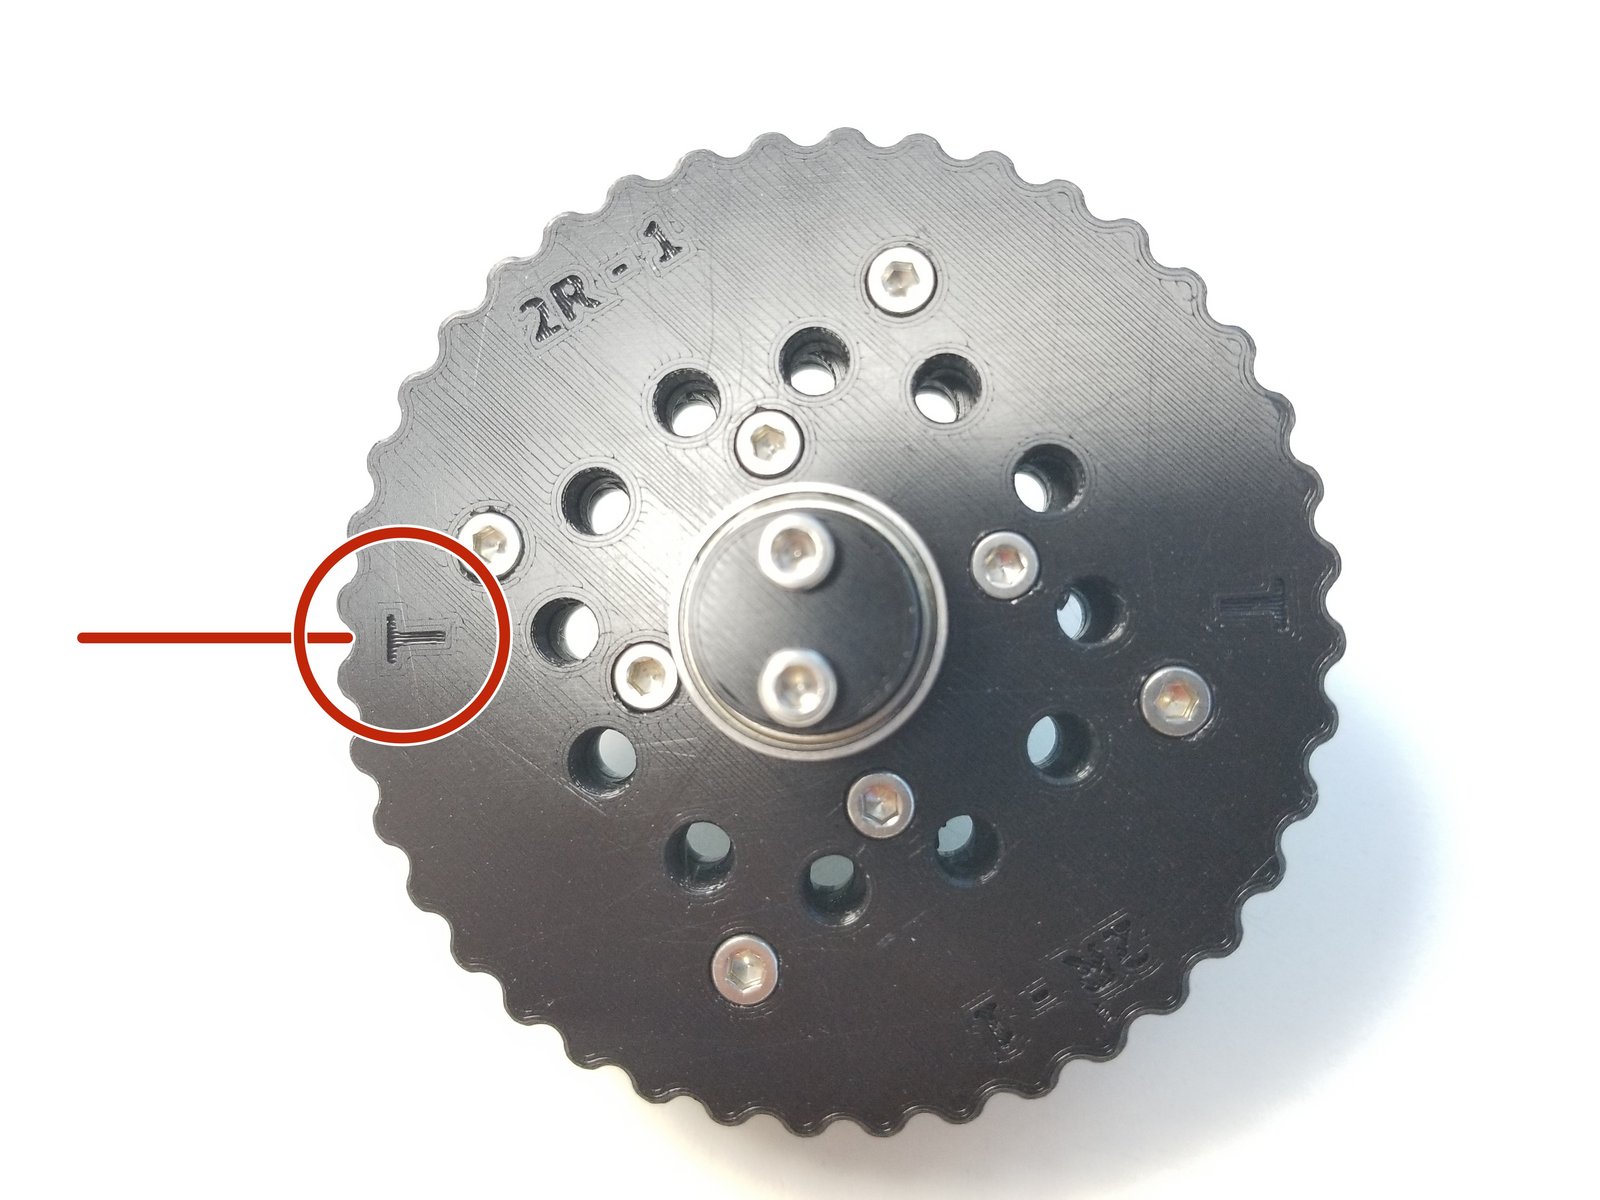
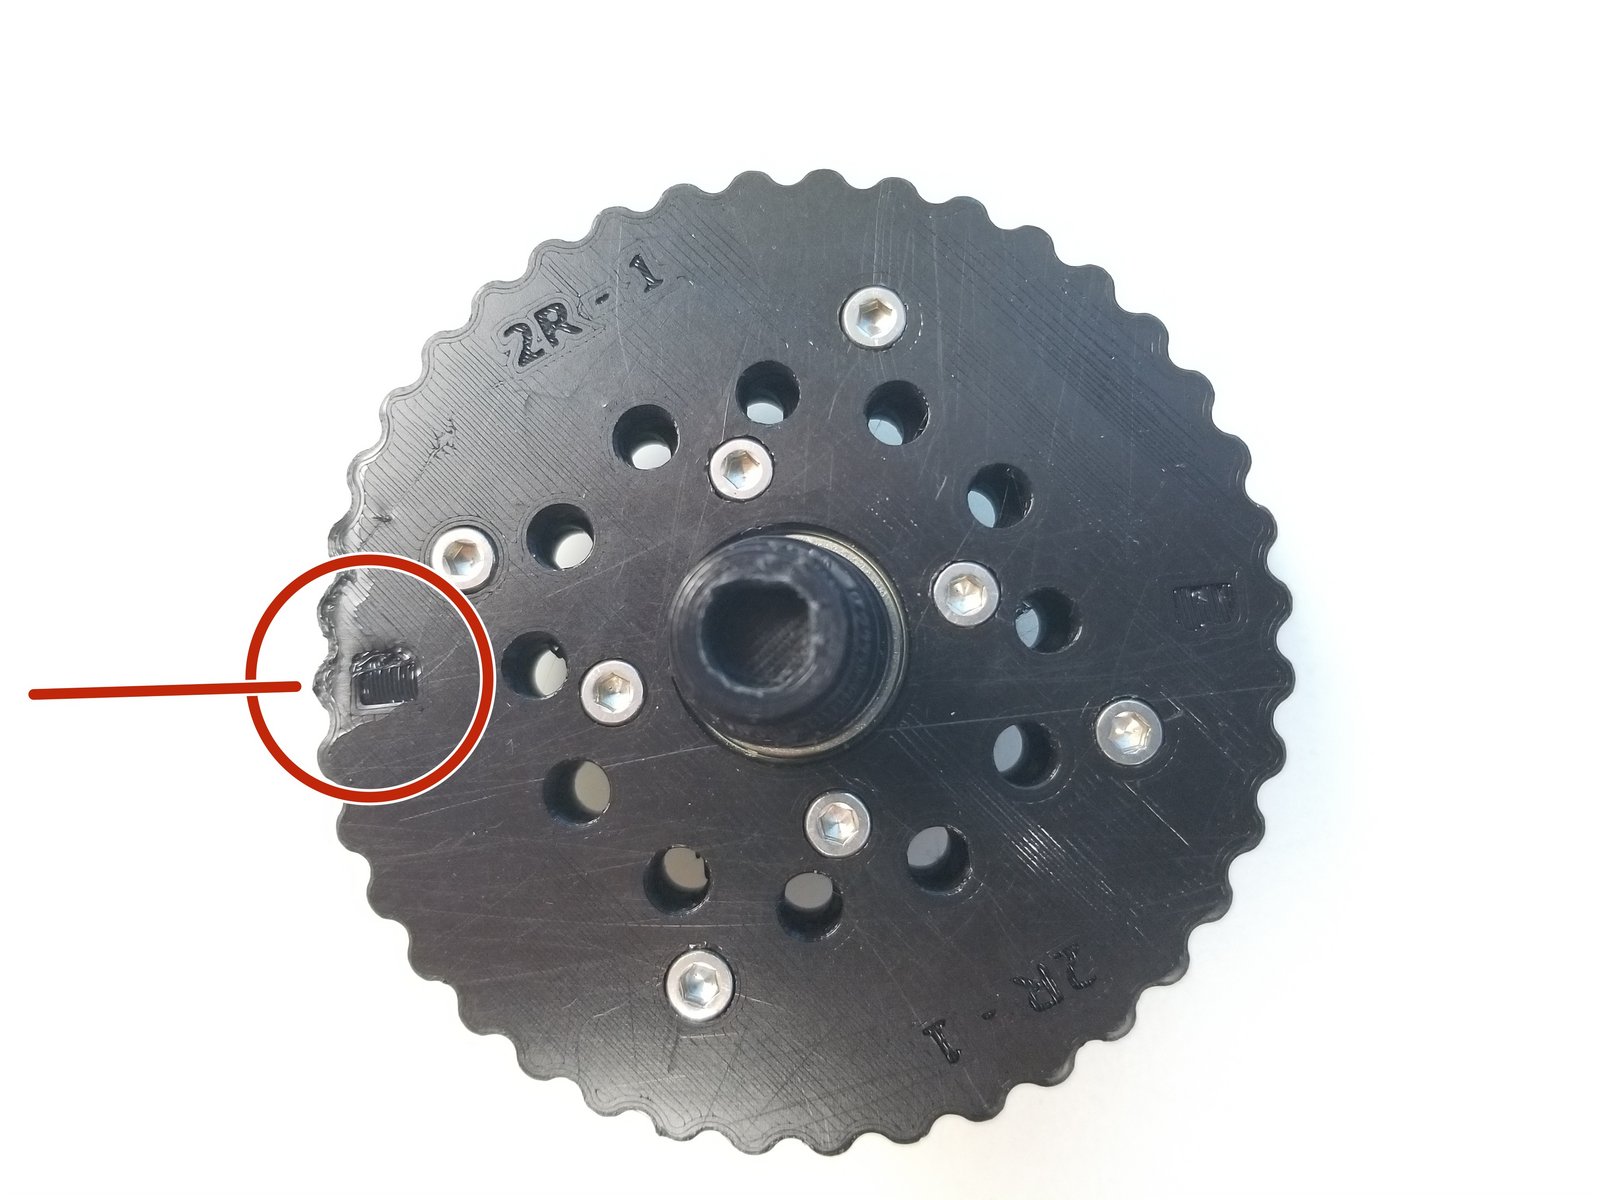
Click the large image to open full size.
- Warning:
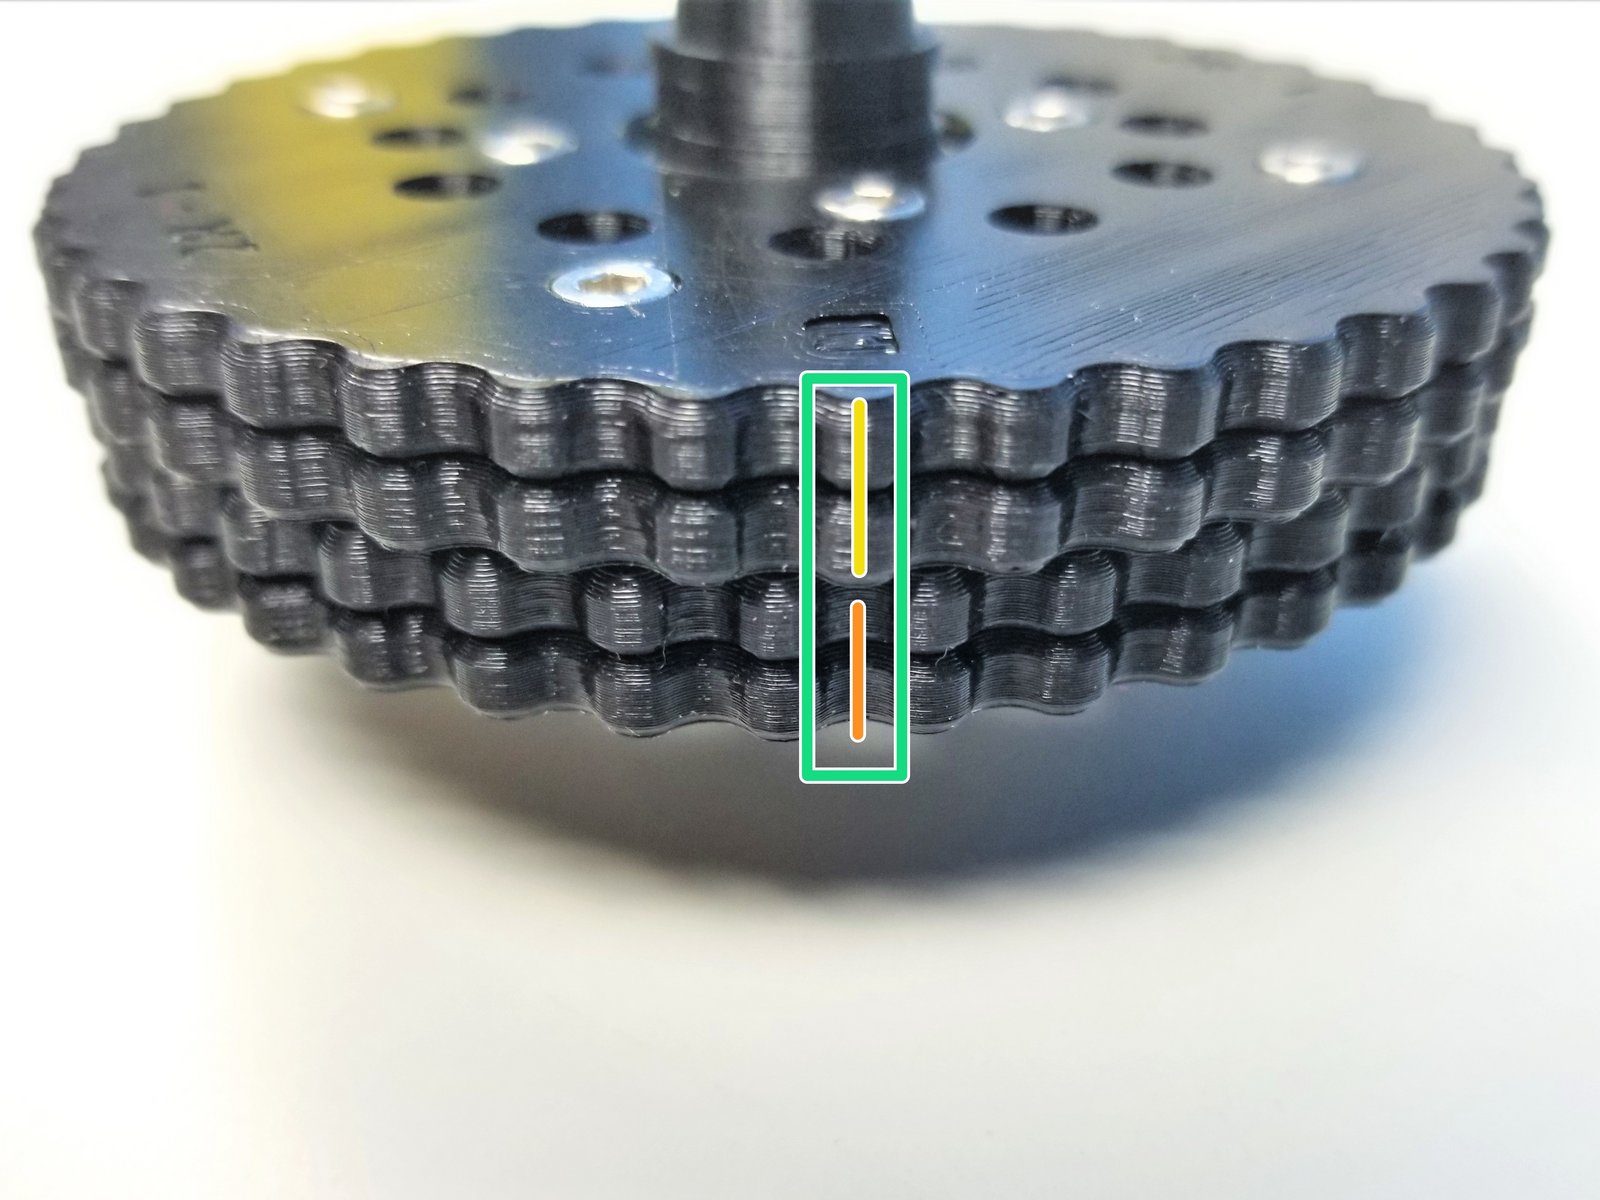
Alignment of the rotor is critical for these gearbox to work.
- Note:
Notice that there are 2 "T" Labels on the T rotor, and same with B rotor with "B" Labels
T is aligned in between 2 teeth of the Top Rotor while B is aligned to the middle of a tooth
Make a Sharpie Mark in between the teeth of T Rotor Where the "T" is Labeled
For B Rotor, Make a sharpie mark on the tooth where the "B" is Labeled.
The Correct Alignment will look something like the Third Picture
Step 12 Shoulder Gearbox Housing - Housing Clamp
Click the large image to open full size.
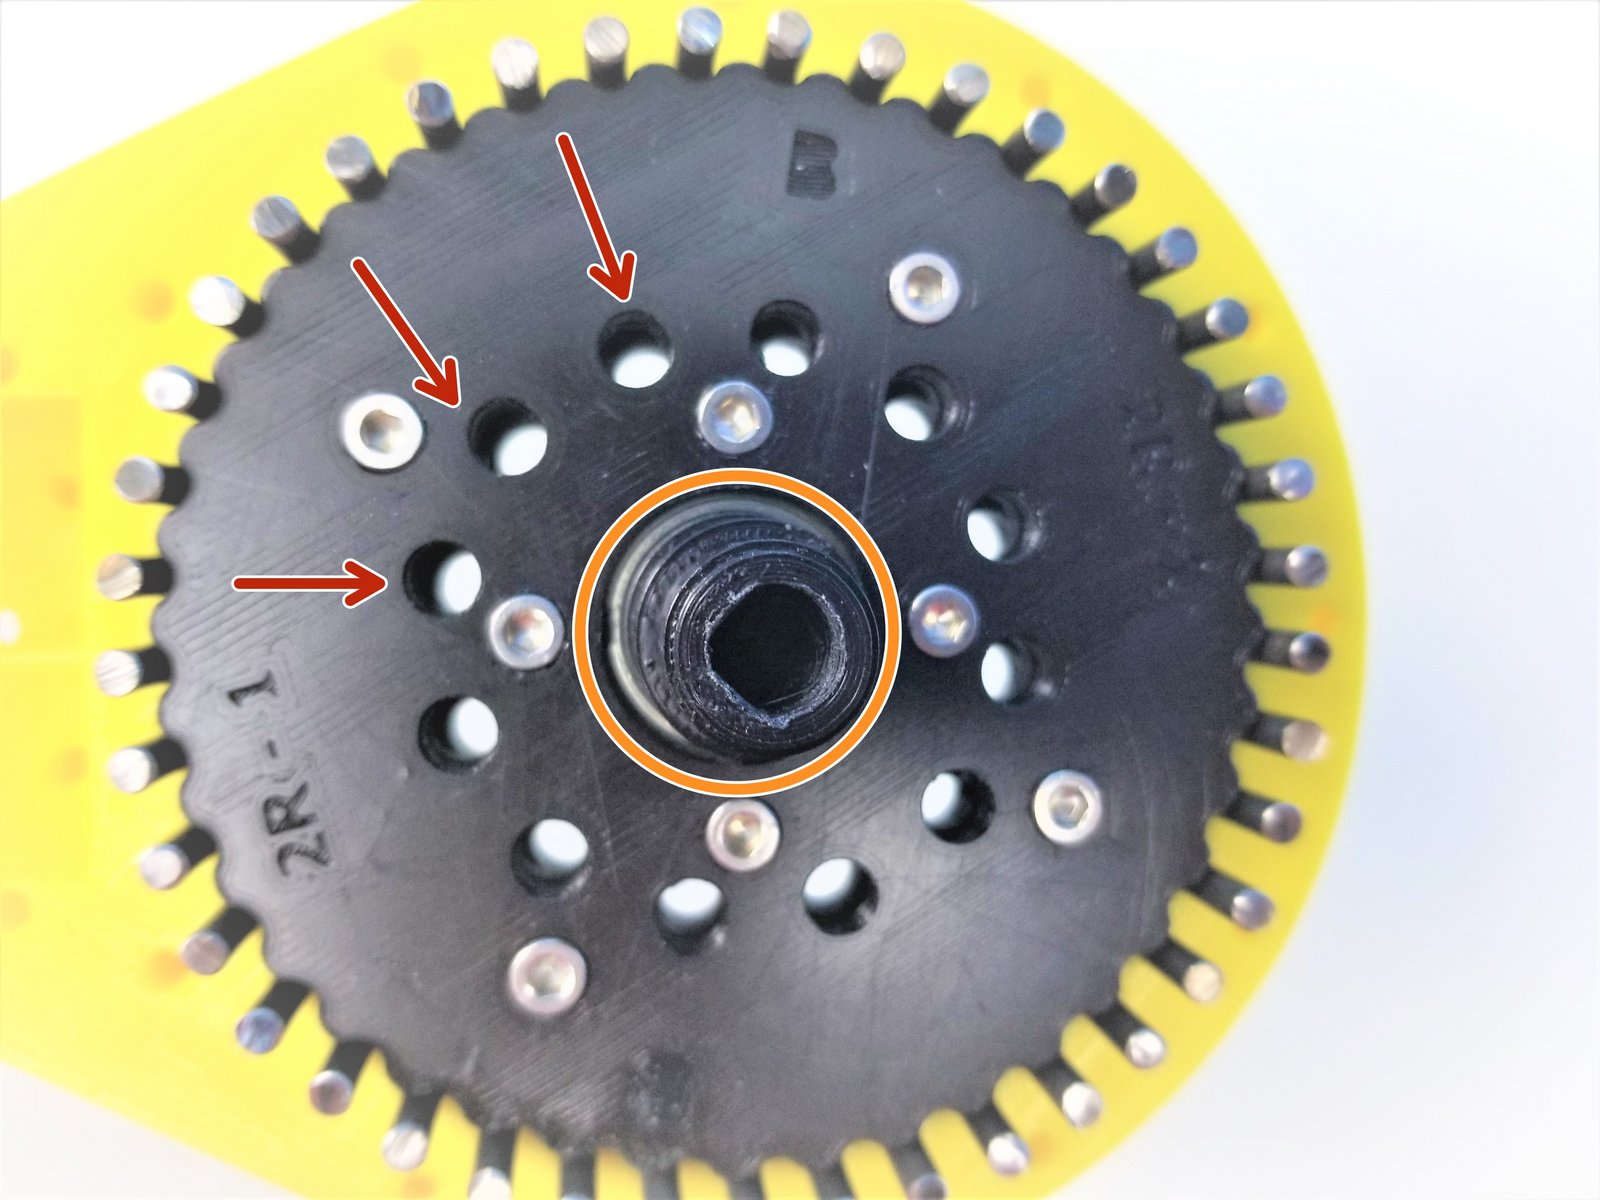
Once the Rotor is Properly aligned, all 12 inner holes will have the same space between them when looking directly above it
- Warning:
The Angle of the picture taken of the aligned Rotors are a bit off.
Carefully insert the Rotor while maintaining this position on the Housing with the pins.
- Warning:
Make sure the Motor Shaft Adapter side of the shaft is Pointing out
Press the second half of the housing into place.
- Note:
Verify that you can manually turn the eccentric shaft in the center and that the rotors smoothly turn inside the housing. Tight printing and misaligned rotors can cause the gearbox to jam.
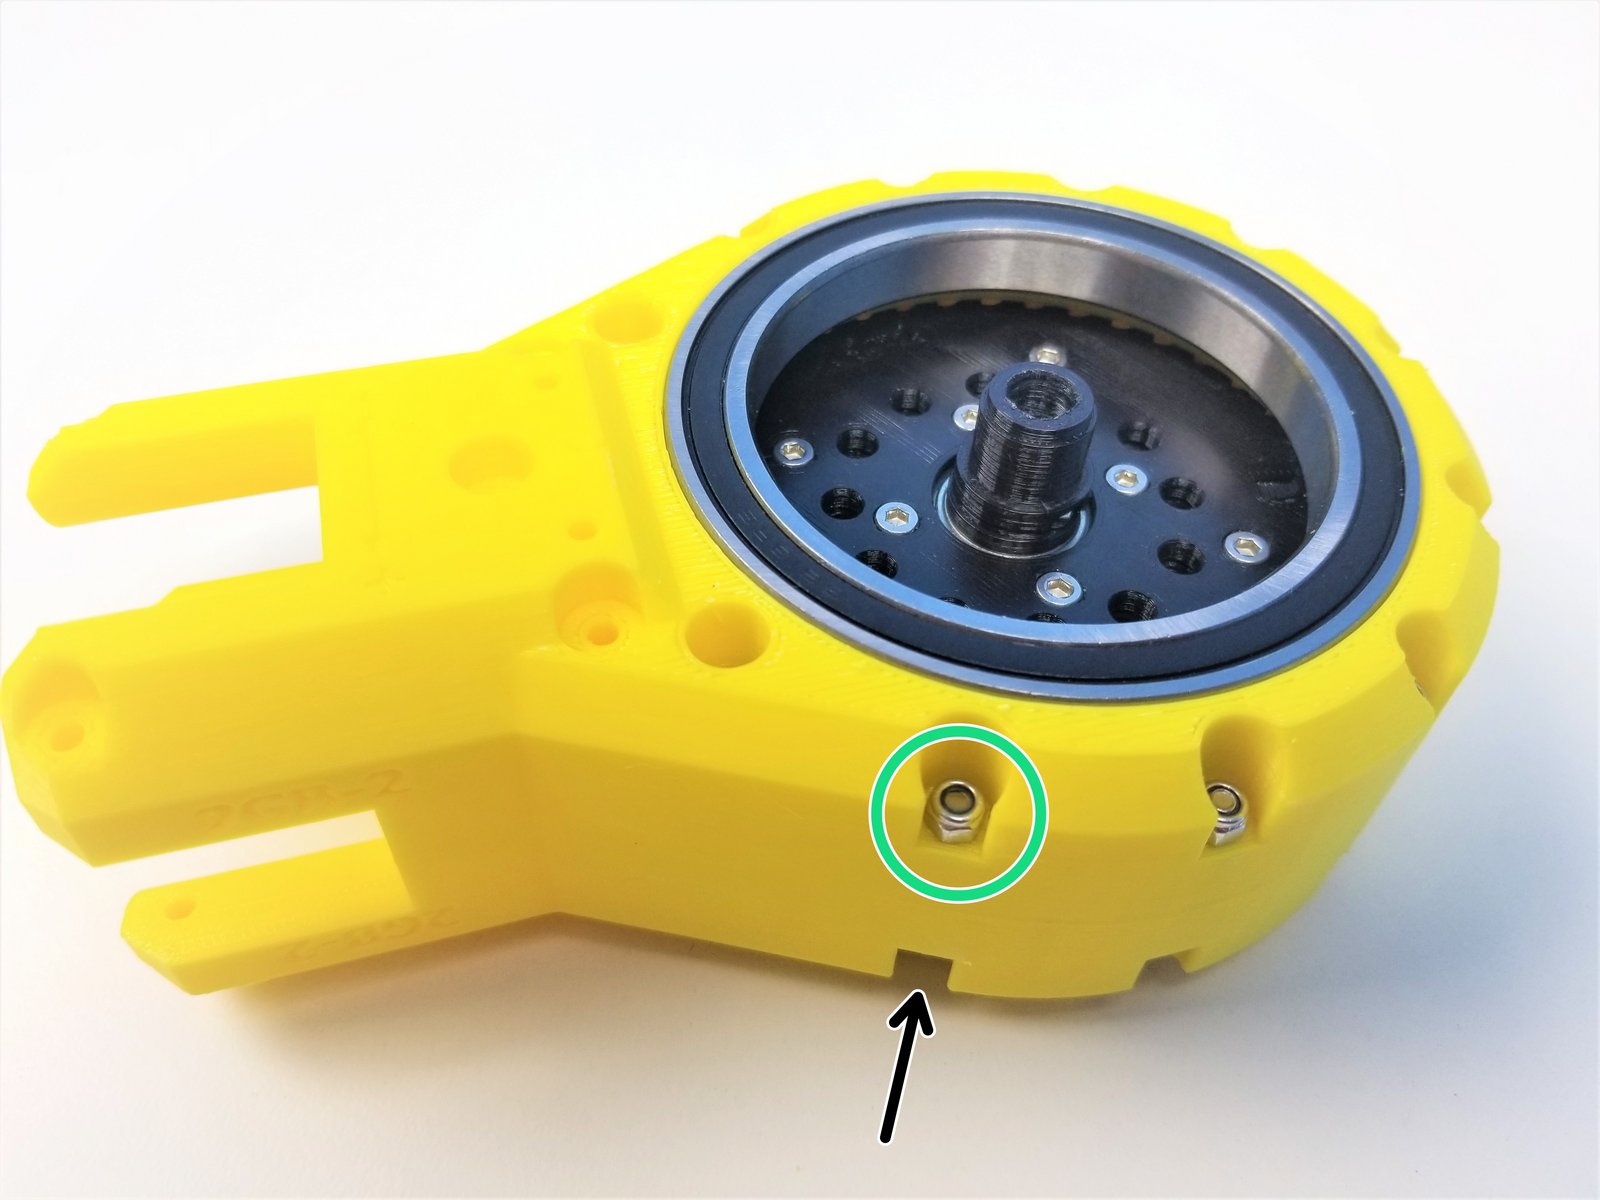
Clamp the other half of the Housing using M3x25mm Screws and Nylock Nuts
Secure tightly using the 5.5mm Socket Driver to hold the Nuts.
Step 13 Shoulder Gearbox Bottom - Parts
Click the large image to open full size.
- Note:
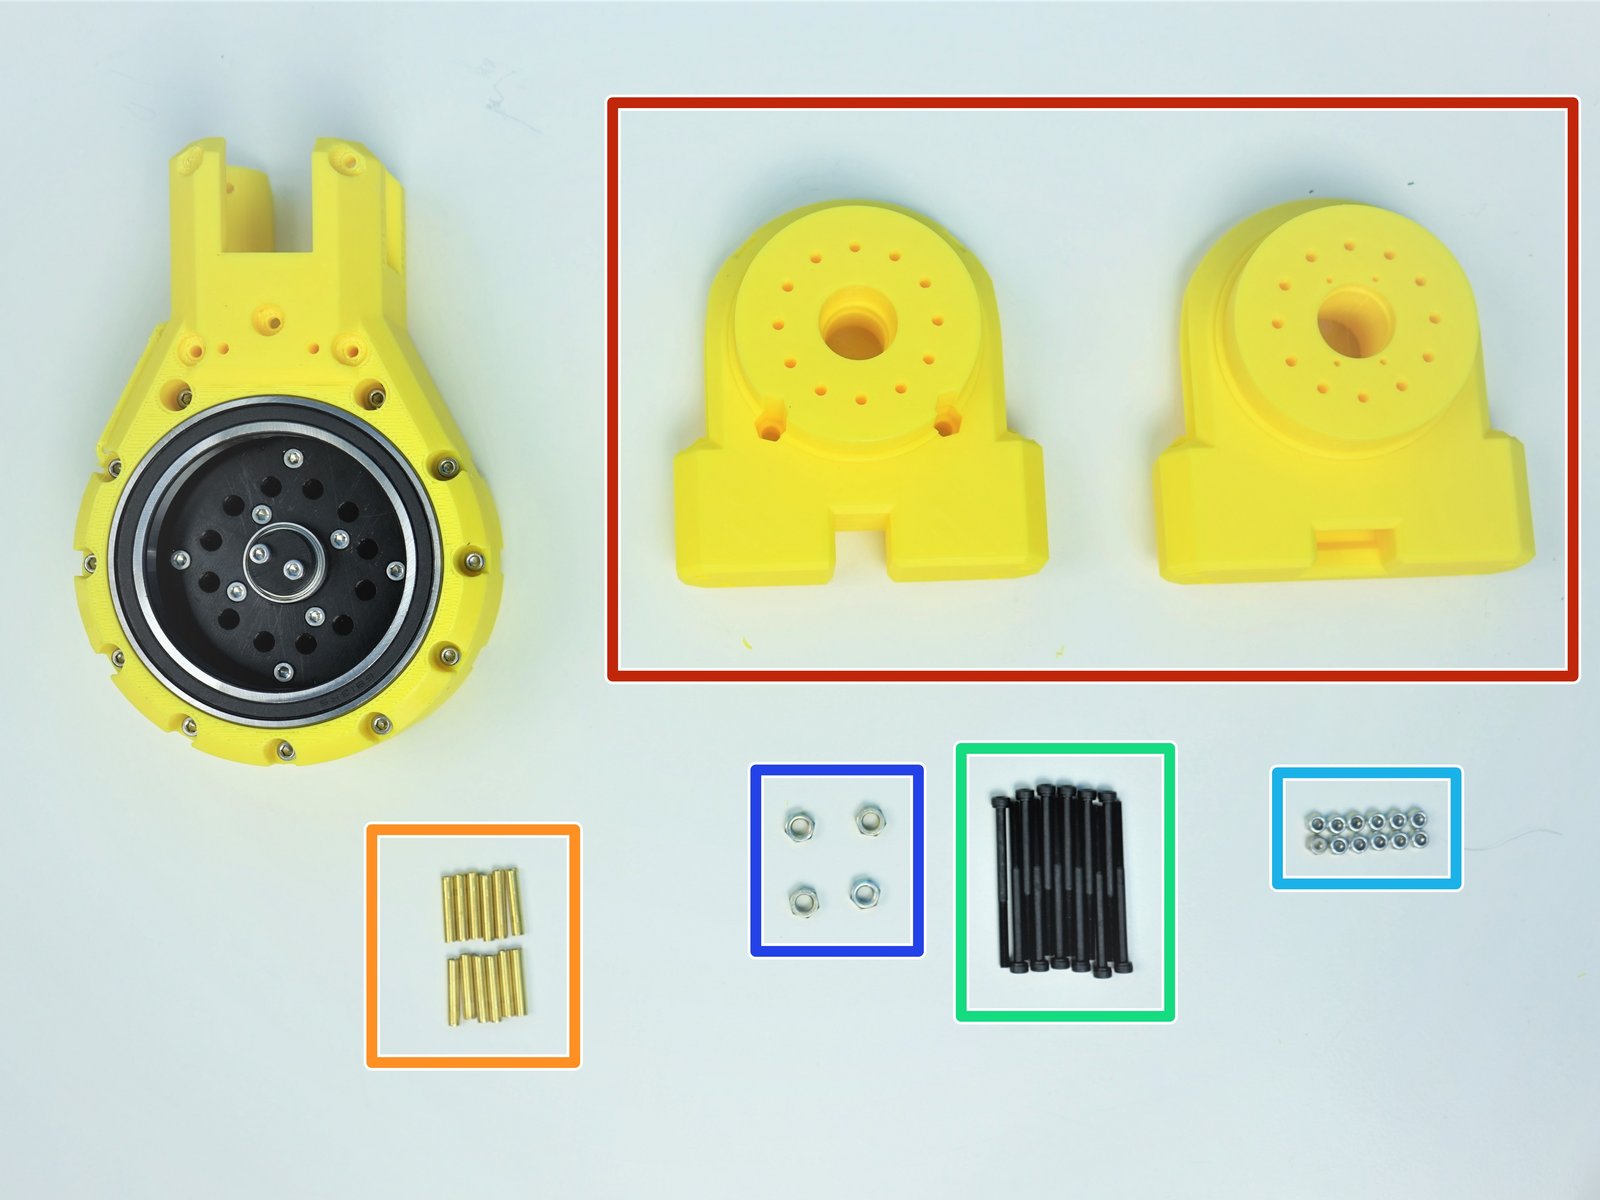
Prepare the following components:
Assembled Shoulder Gearbox Top
[3D] - 2GB Shoulder GB Bottom Halves
Brass Tubes [3.5x18.5mm] (x12)
M3x45mm Screws (x12)
M3 Nylock Nuts (x12)
M5 Hex Nuts (x4)
Step 14 Shoulder Gearbox Bottom - 1
Click the large image to open full size.
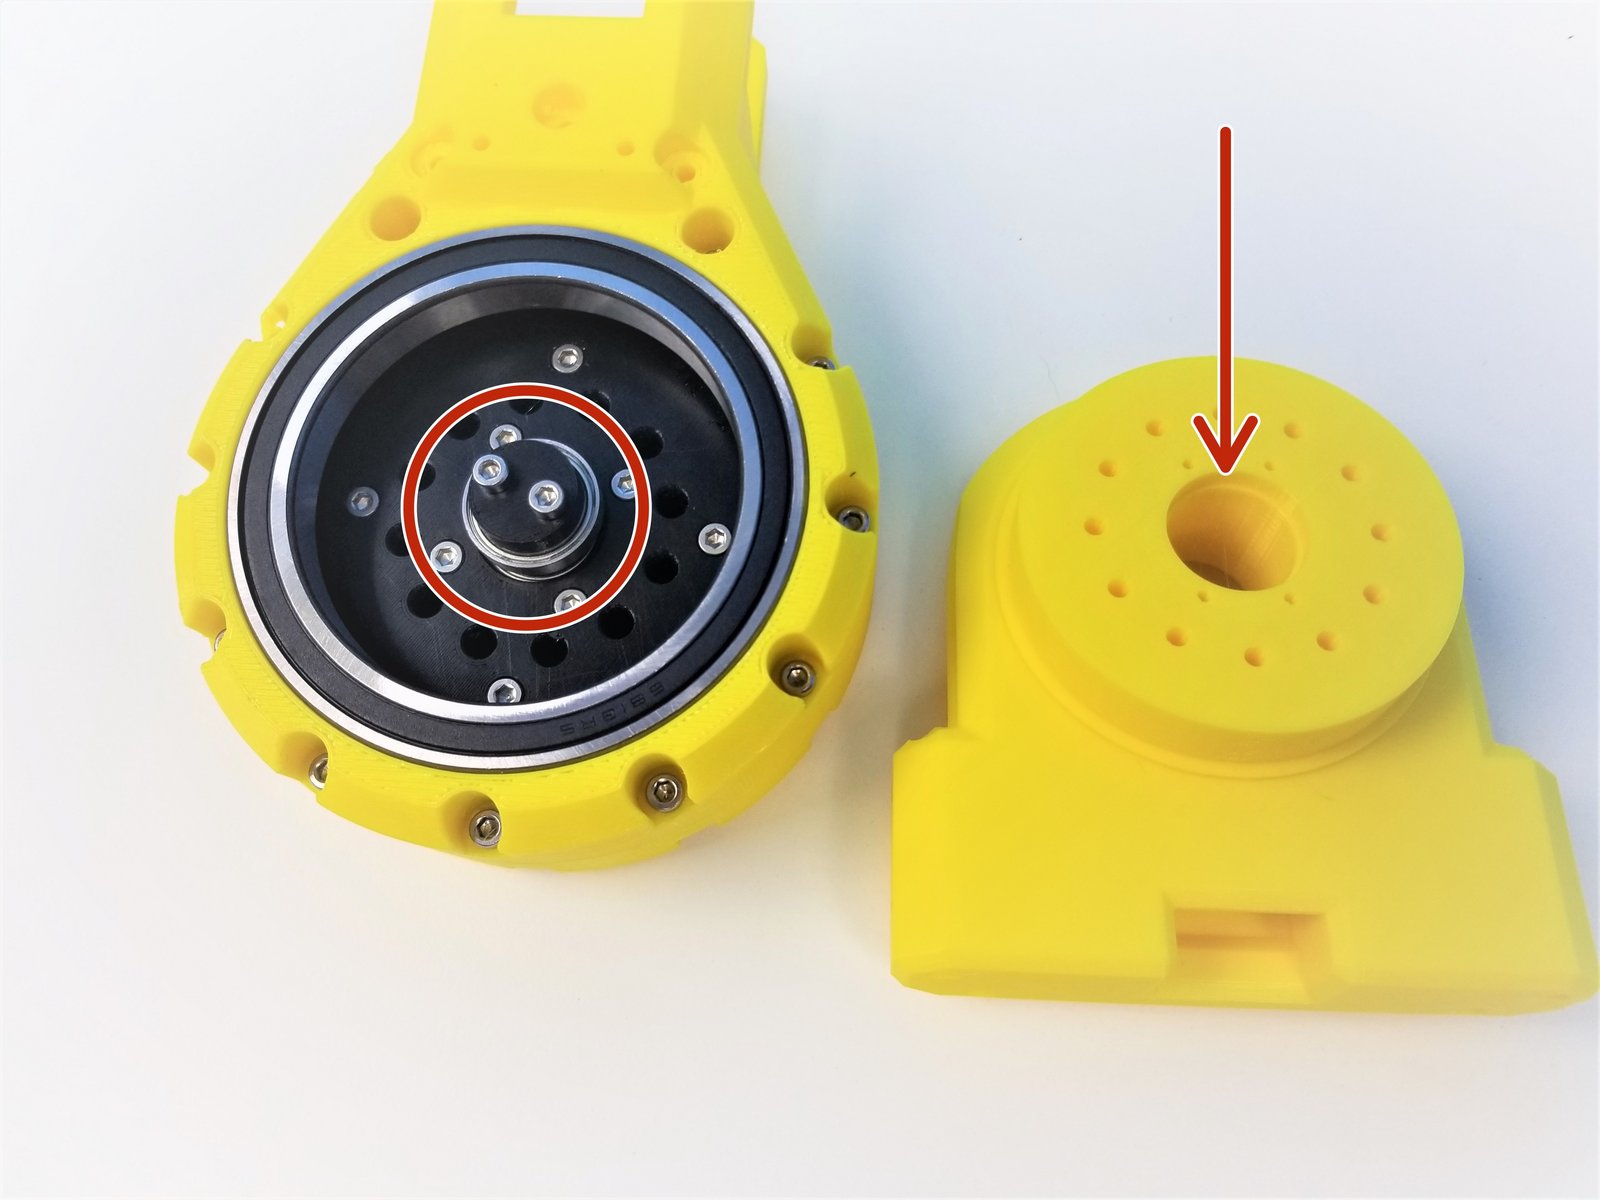
Align the Bearing Insert of the Gearbox Bottom Sensor Side Piece to the Shaft Holder Cam Bearing of the Input Shaft
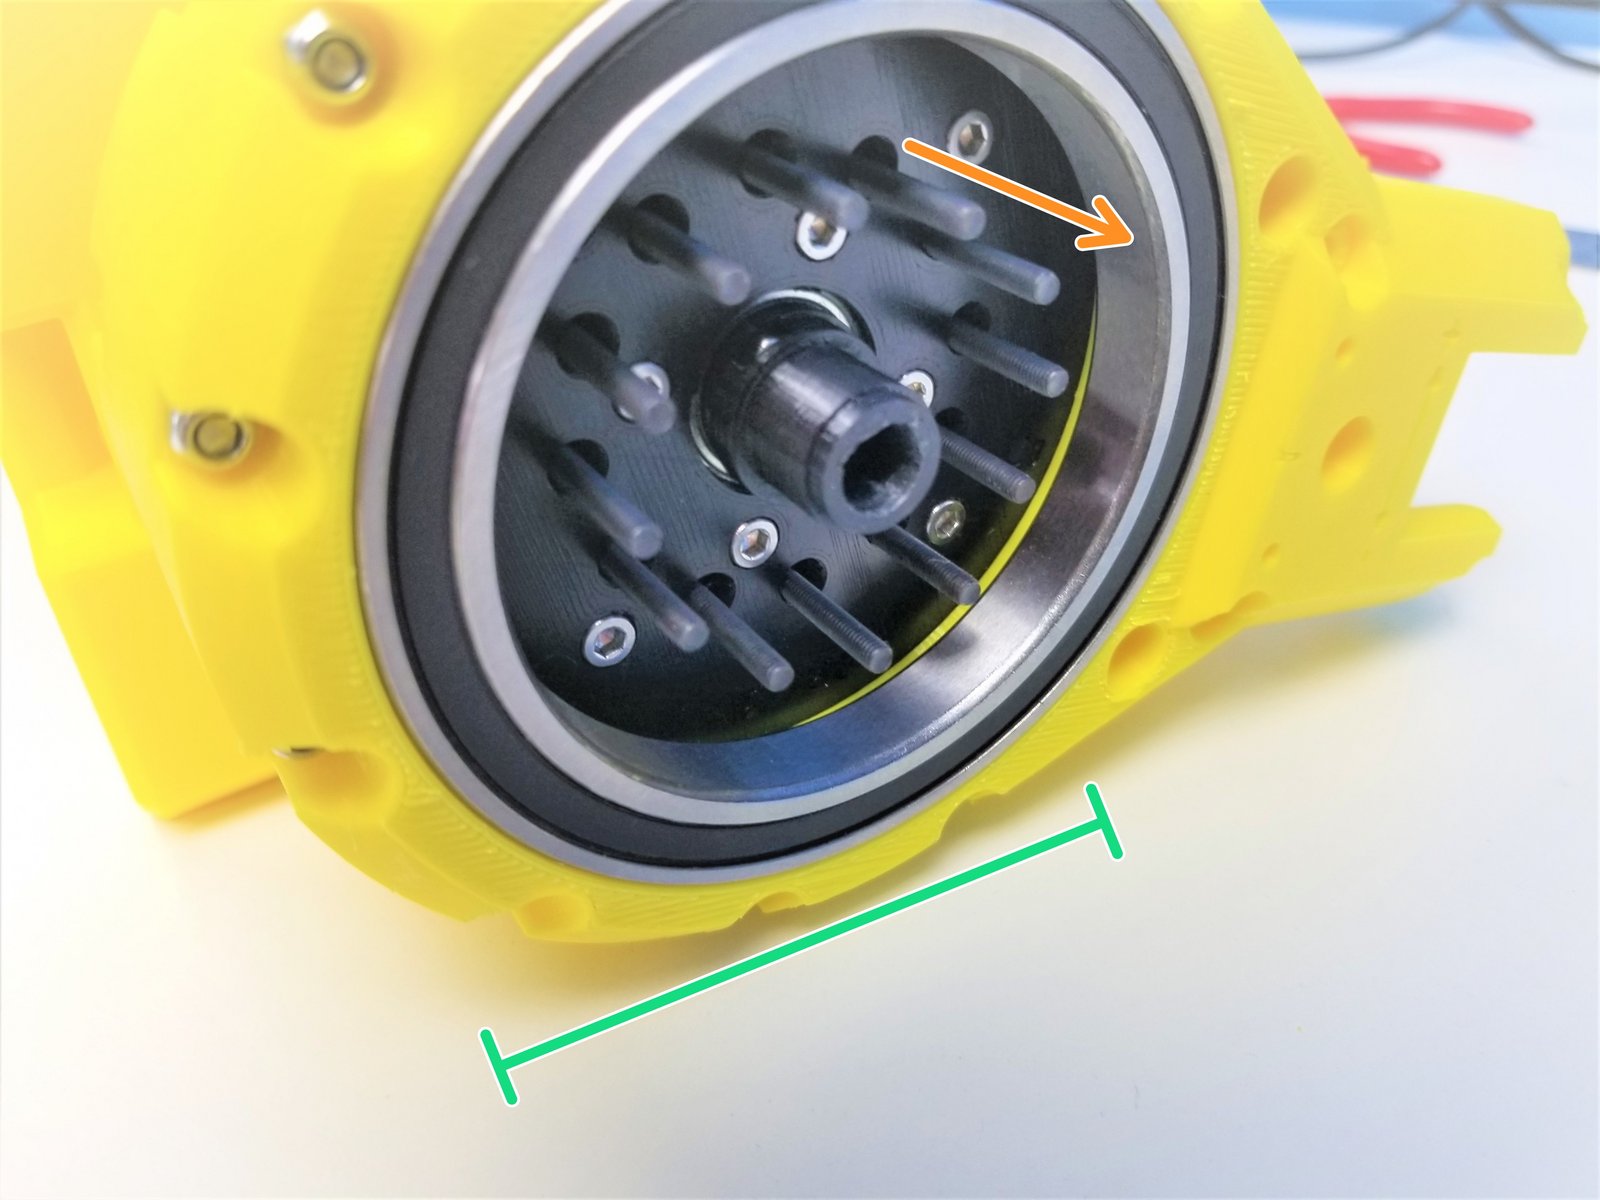
Insert M3x45mm Screws all the way through
- Warning:
If Screws aren't going in correctly, you will have to re do the steps, go to aligning the Rotor Step
Keep the Gearbox laying on its side for easier assembly
Step 15 Shoulder Gearbox Bottom - 2
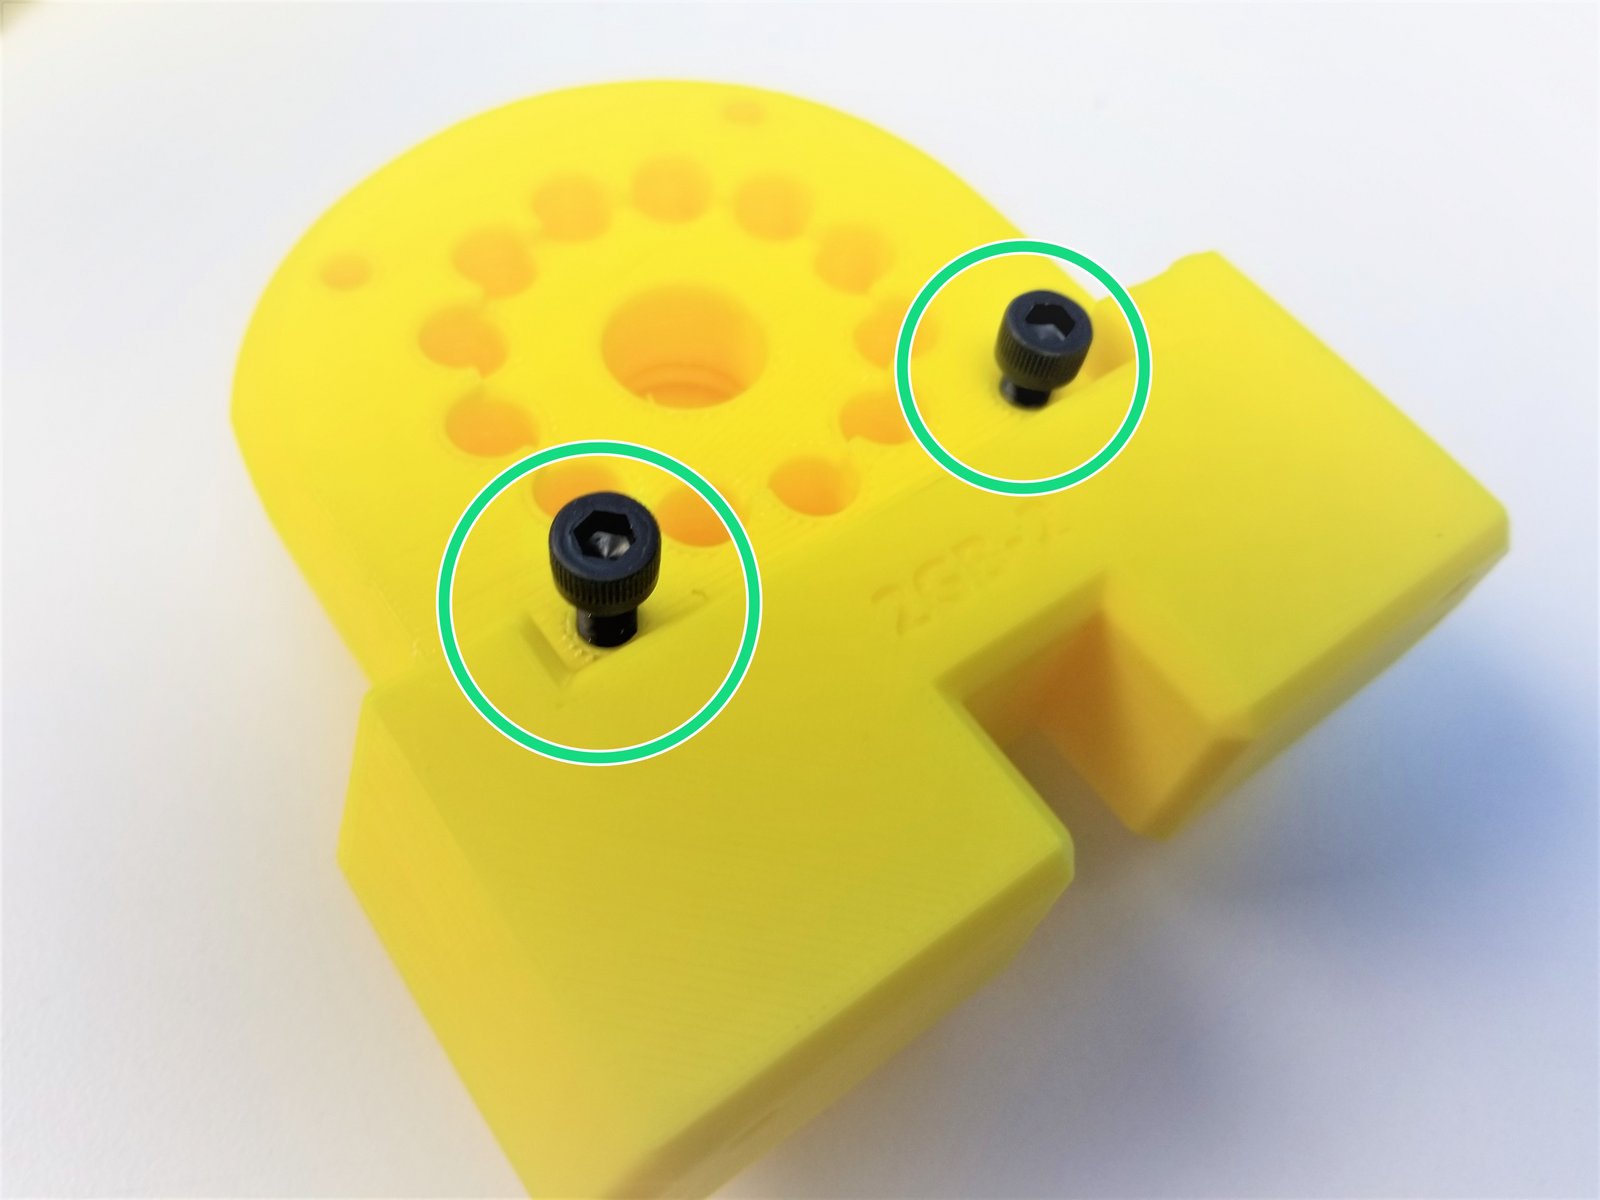
Click the large image to open full size.
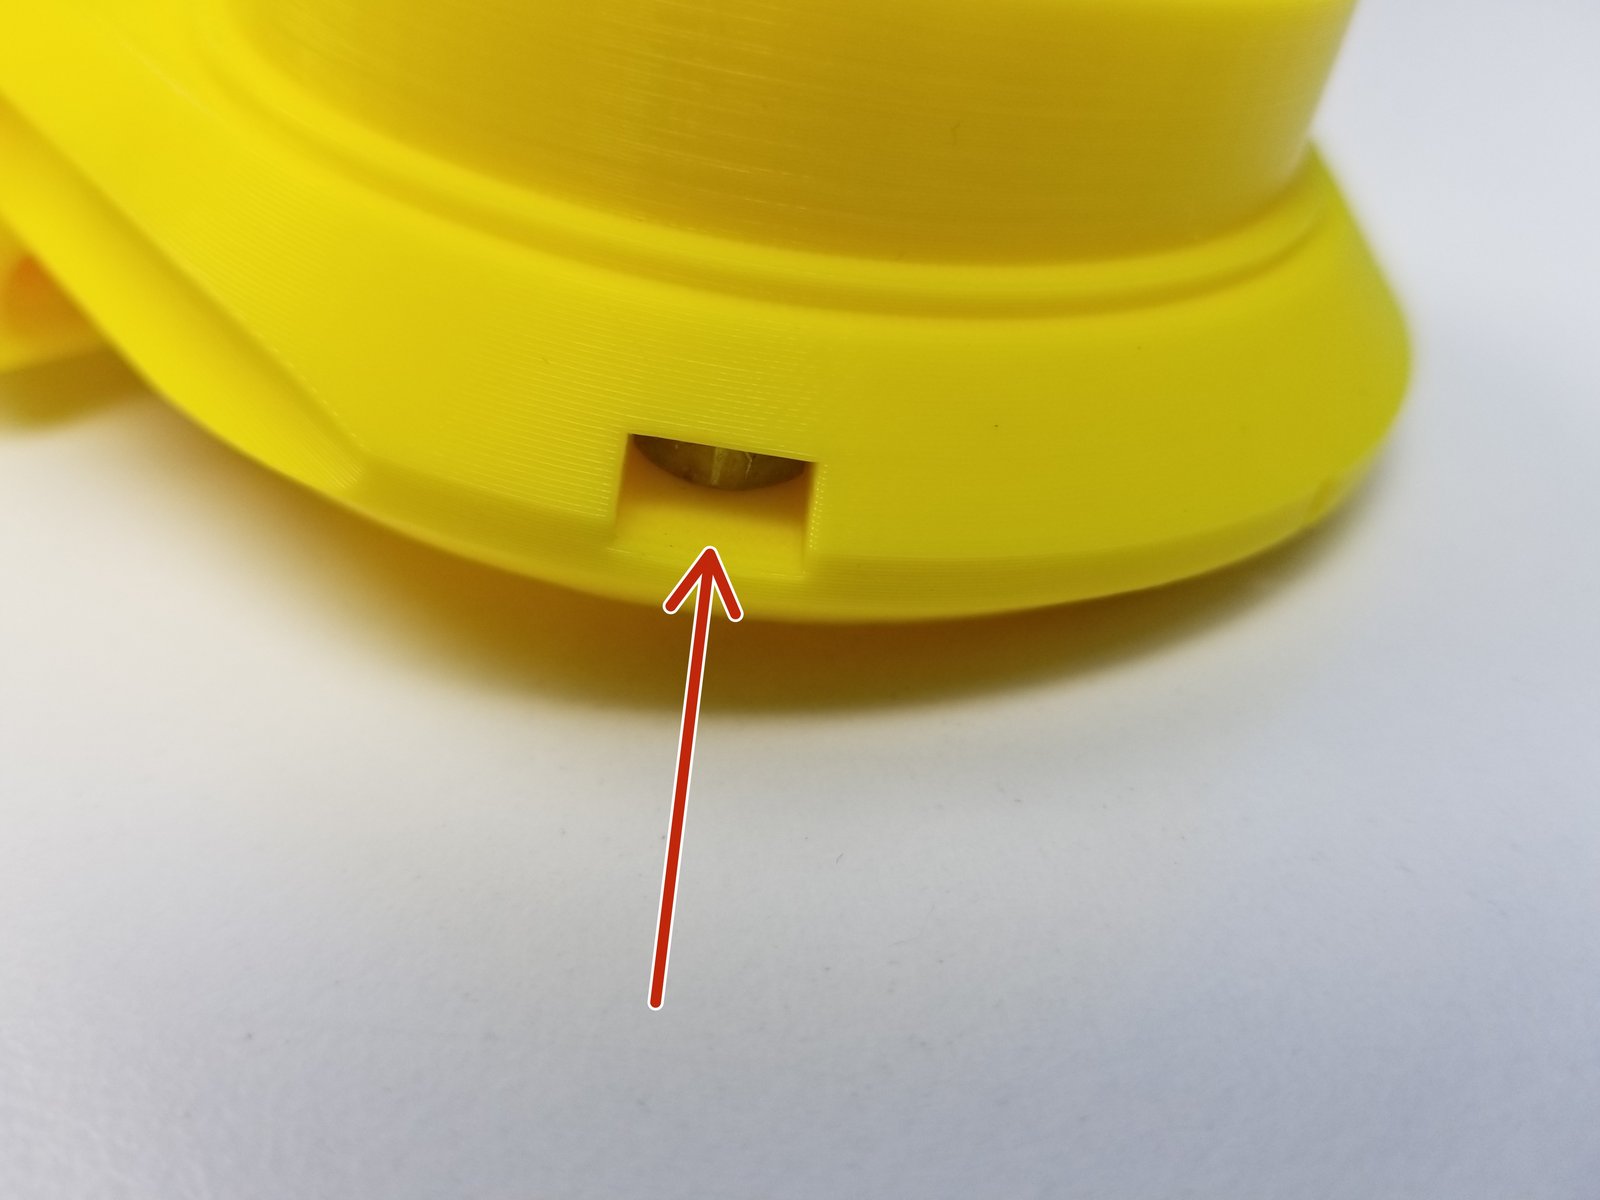
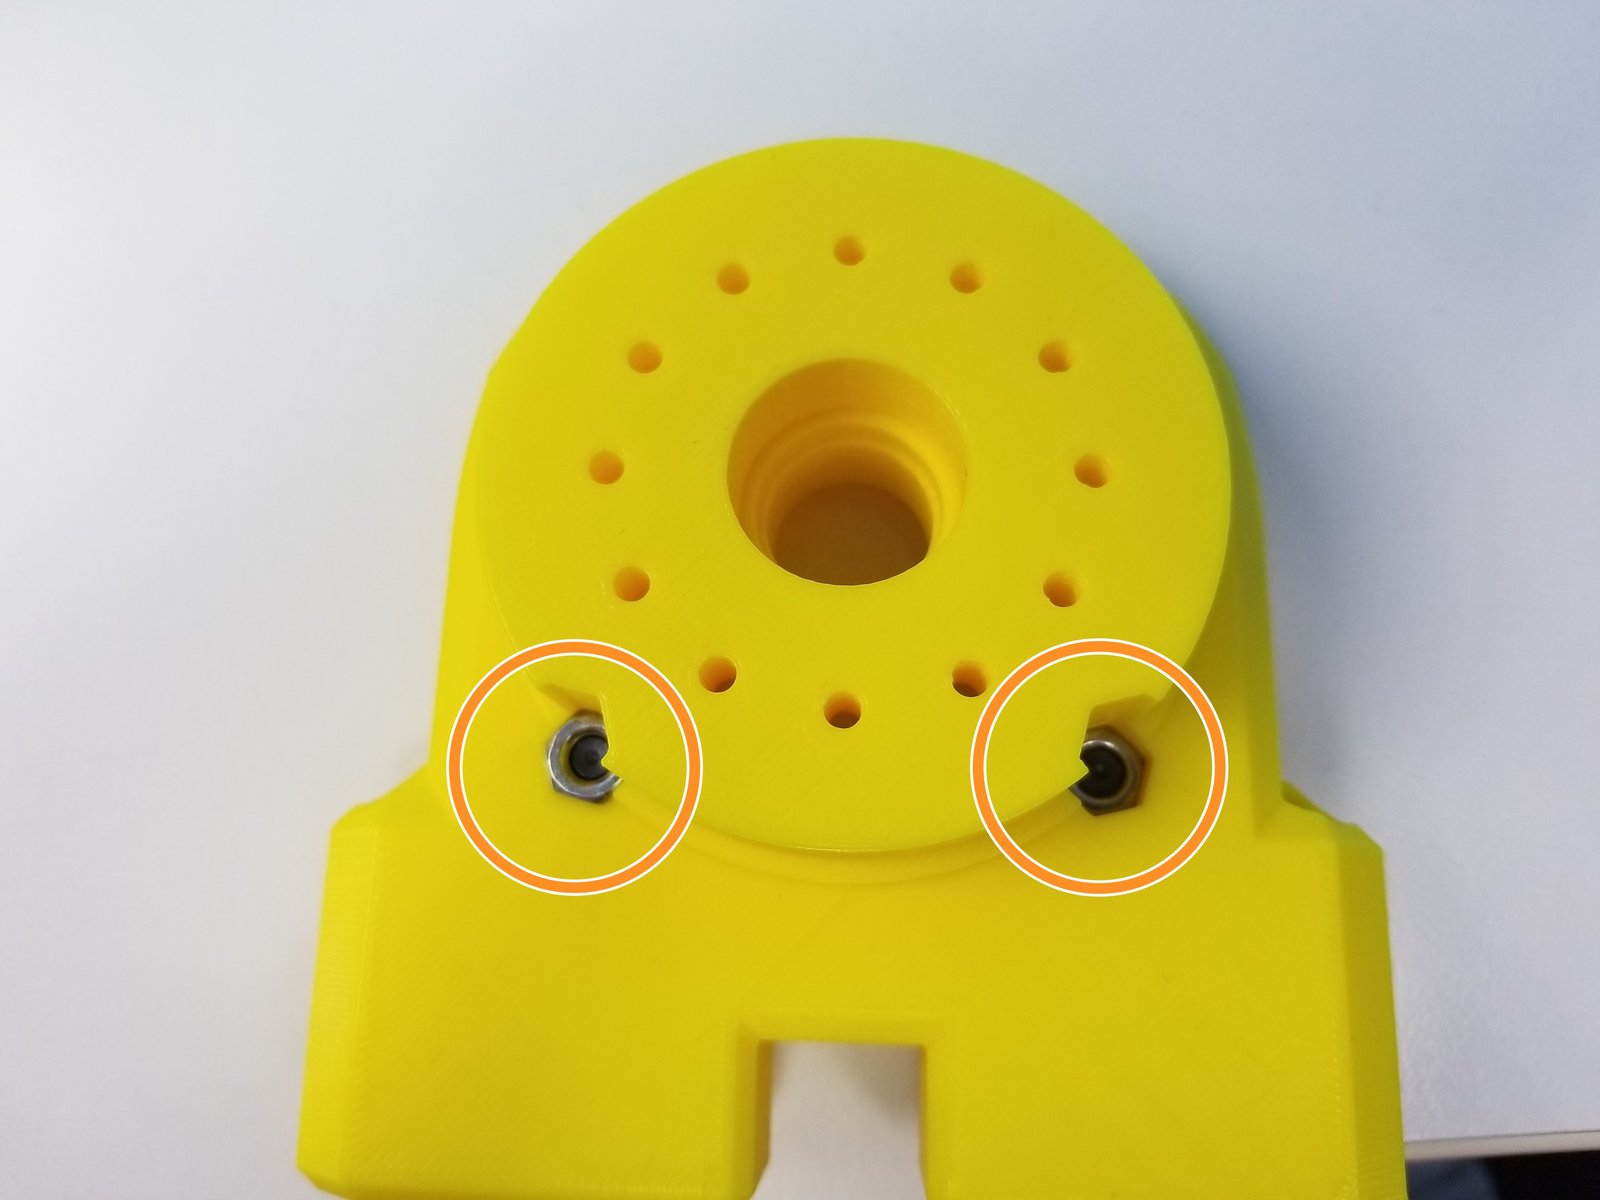
Insert M5 Hex Nuts on the side insert of the Motor Side Bottom Half
Insert the other two M5 Hex Nuts on the bottom inserts
[Opt.] if the nuts are too loose in the insert, use M5x20mm Screws (or any M5 screws) to hold it in place during assembly
Step 16 Shoulder Gearbox Bottom - 3
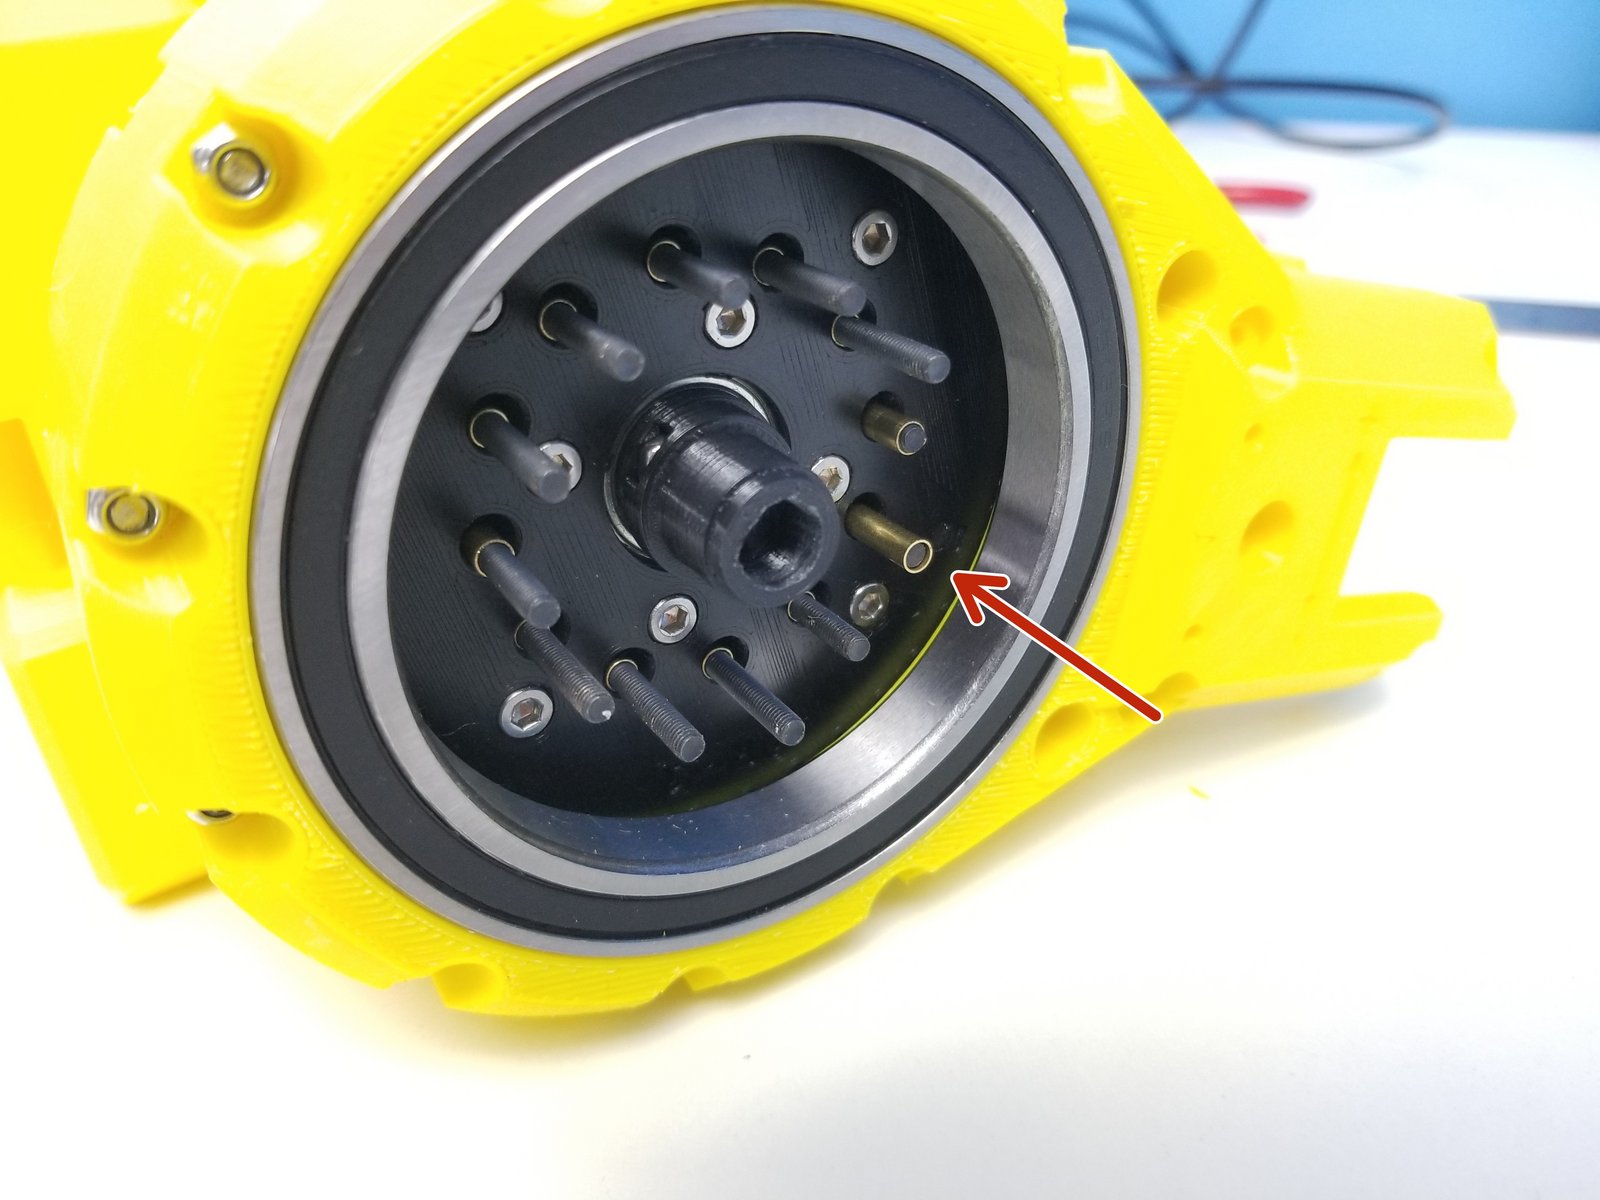
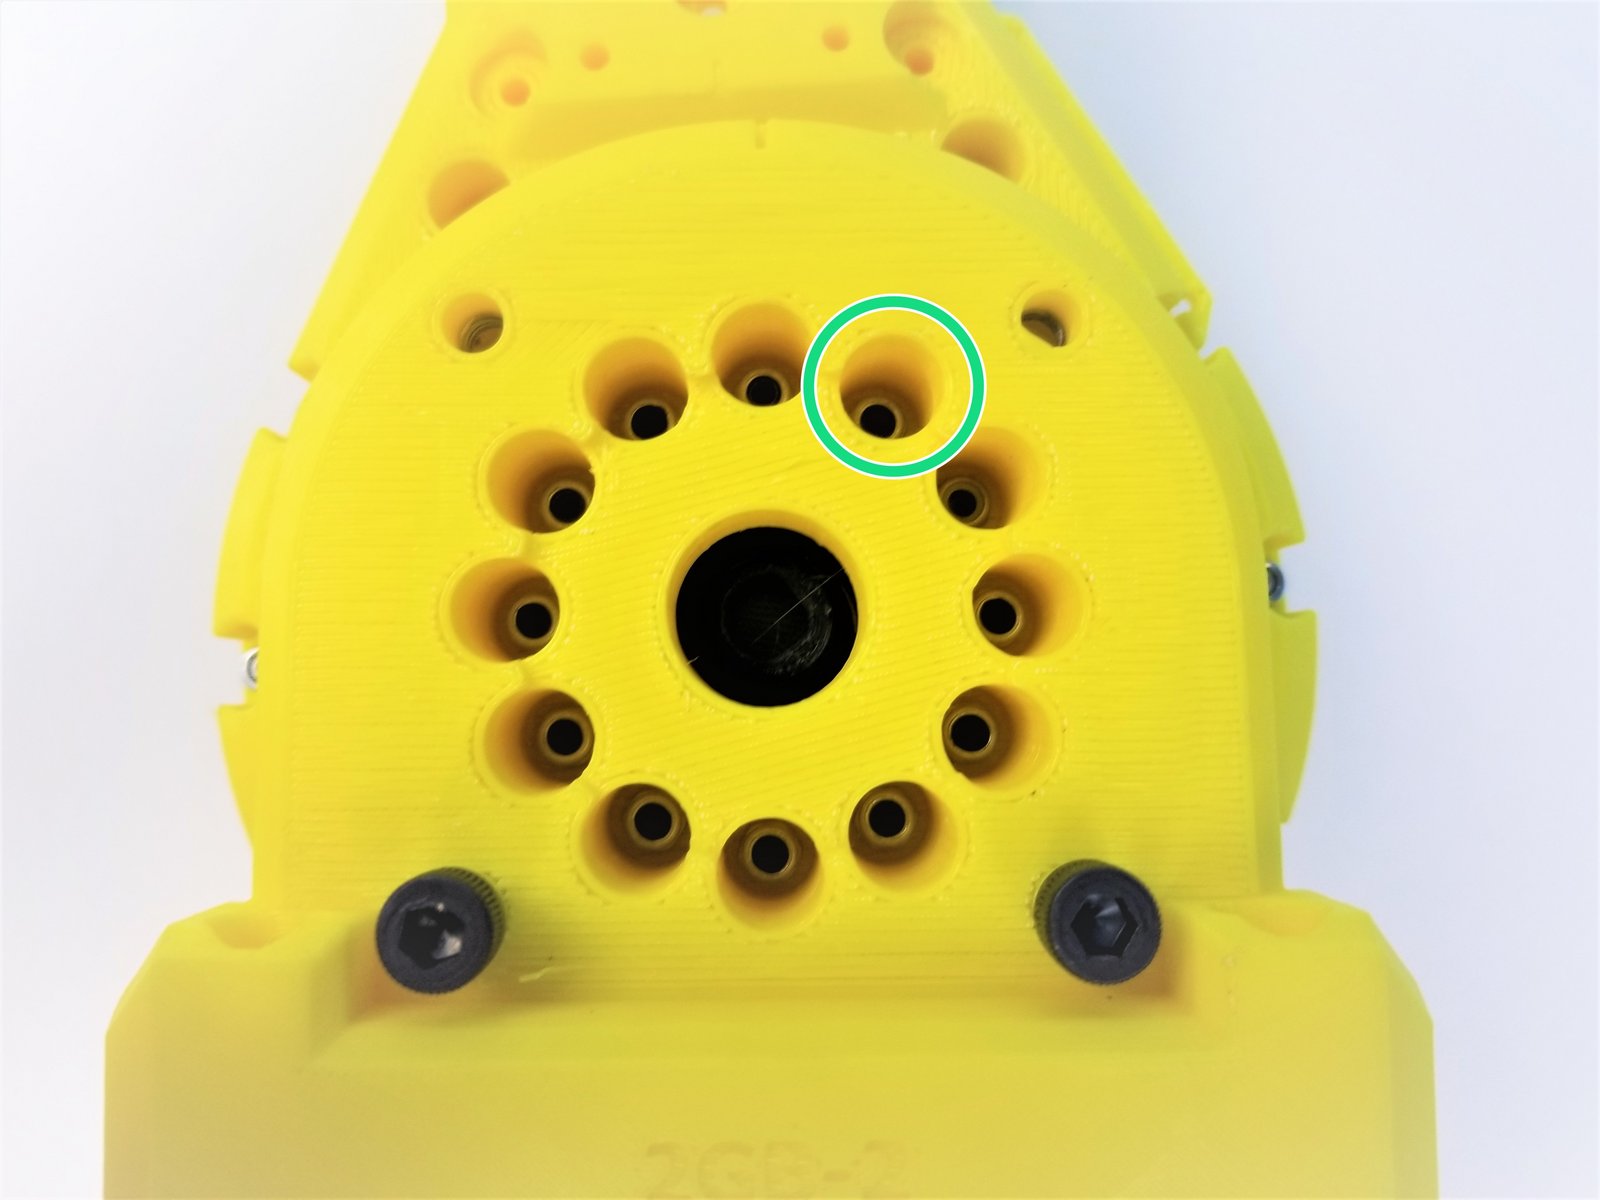
Click the large image to open full size.
While keeping the Gearbox on its side, insert 3.5x18.5mm Brass Tubes on each Screws
Insert the Motor Side of Shoulder Gearbox Bottom and secure it with M3 Nylock Nuts using the Alan Key and Socket Driver
Step 17 Shoulder Gearbox Motor
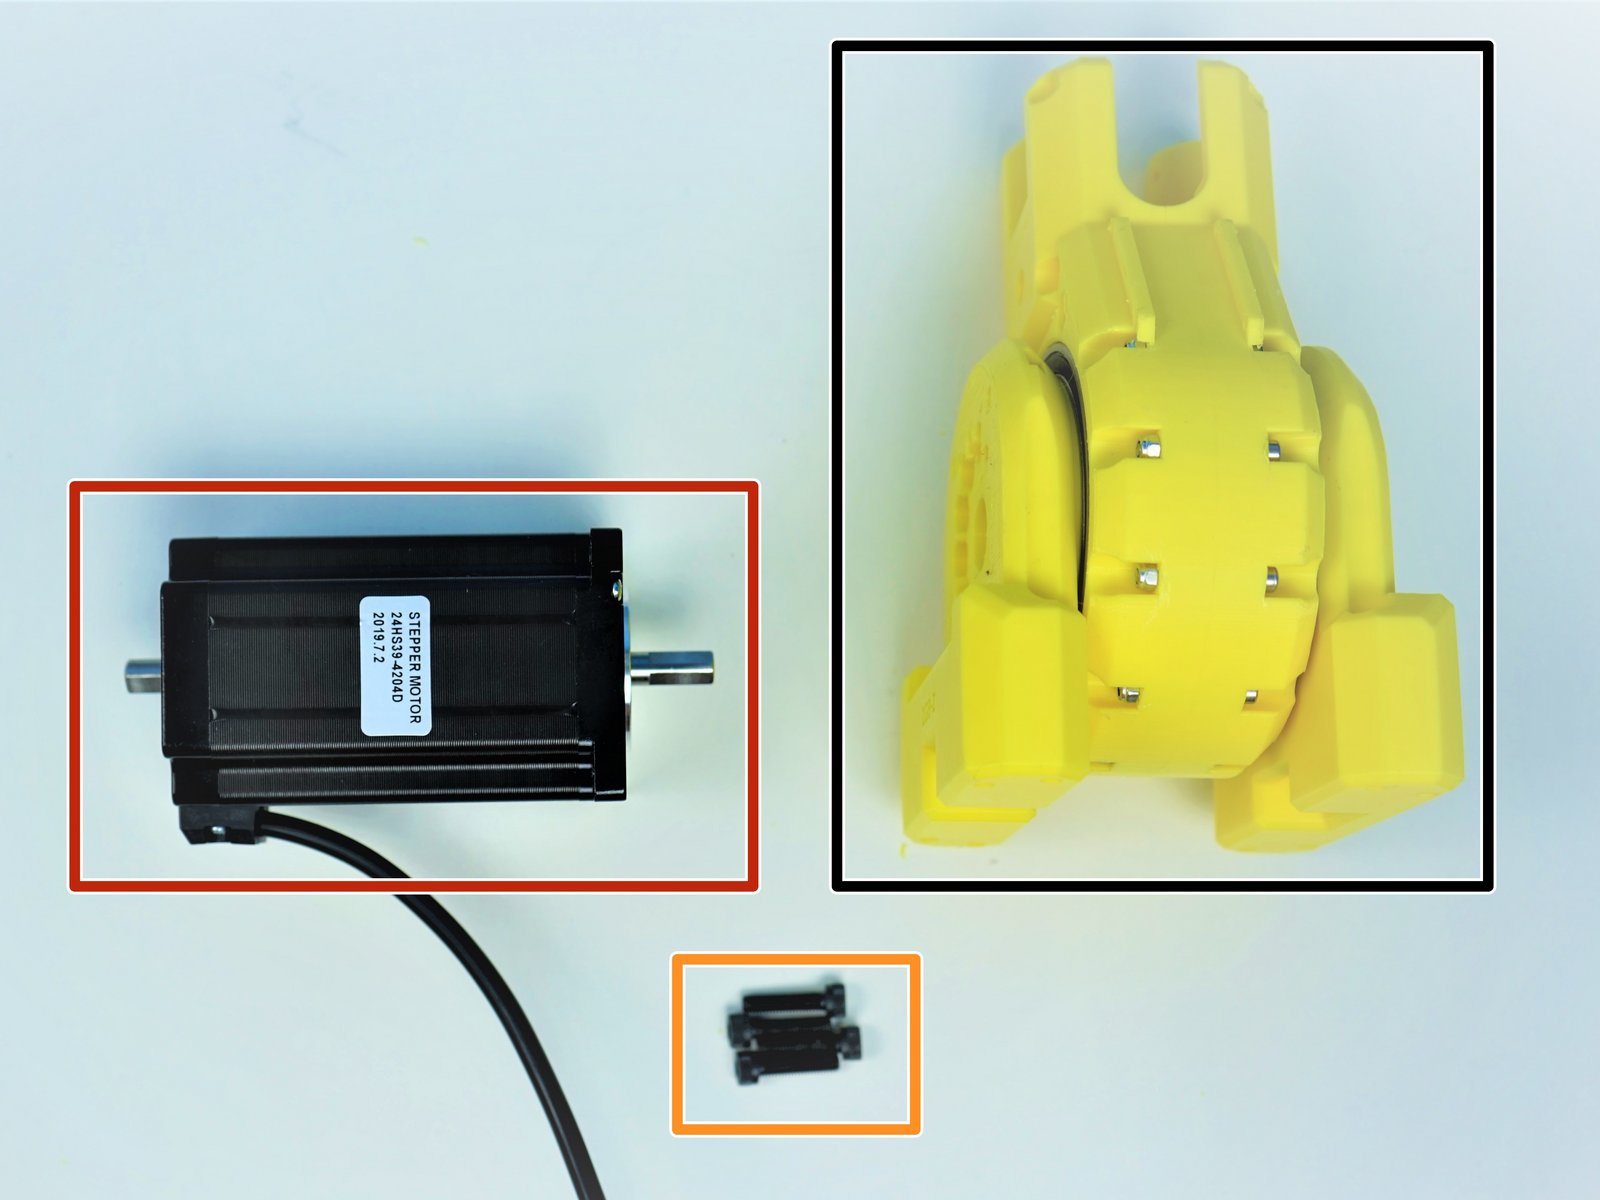
Click the large image to open full size.
- Note:
Prepare the following components:
Assembled Shoulder Gearbox
NEMA24 100mm Motor
M5x20mm Screws (x4)
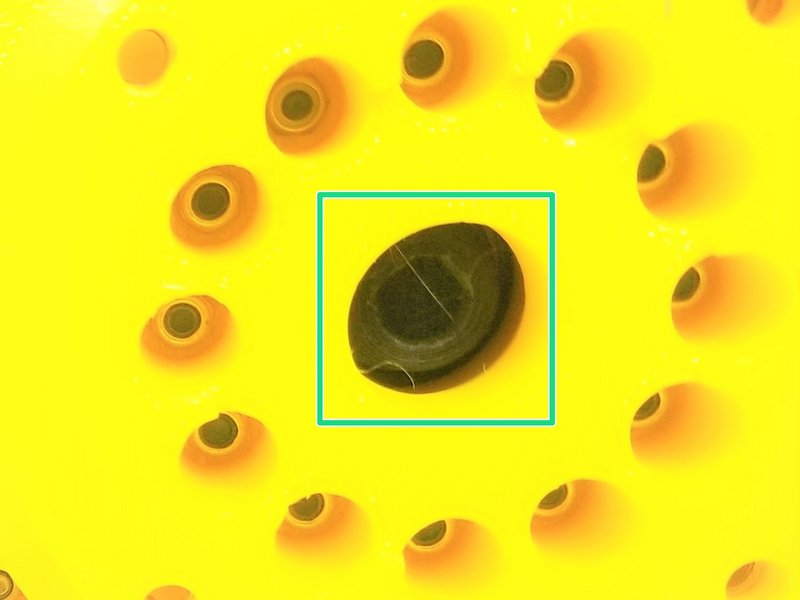
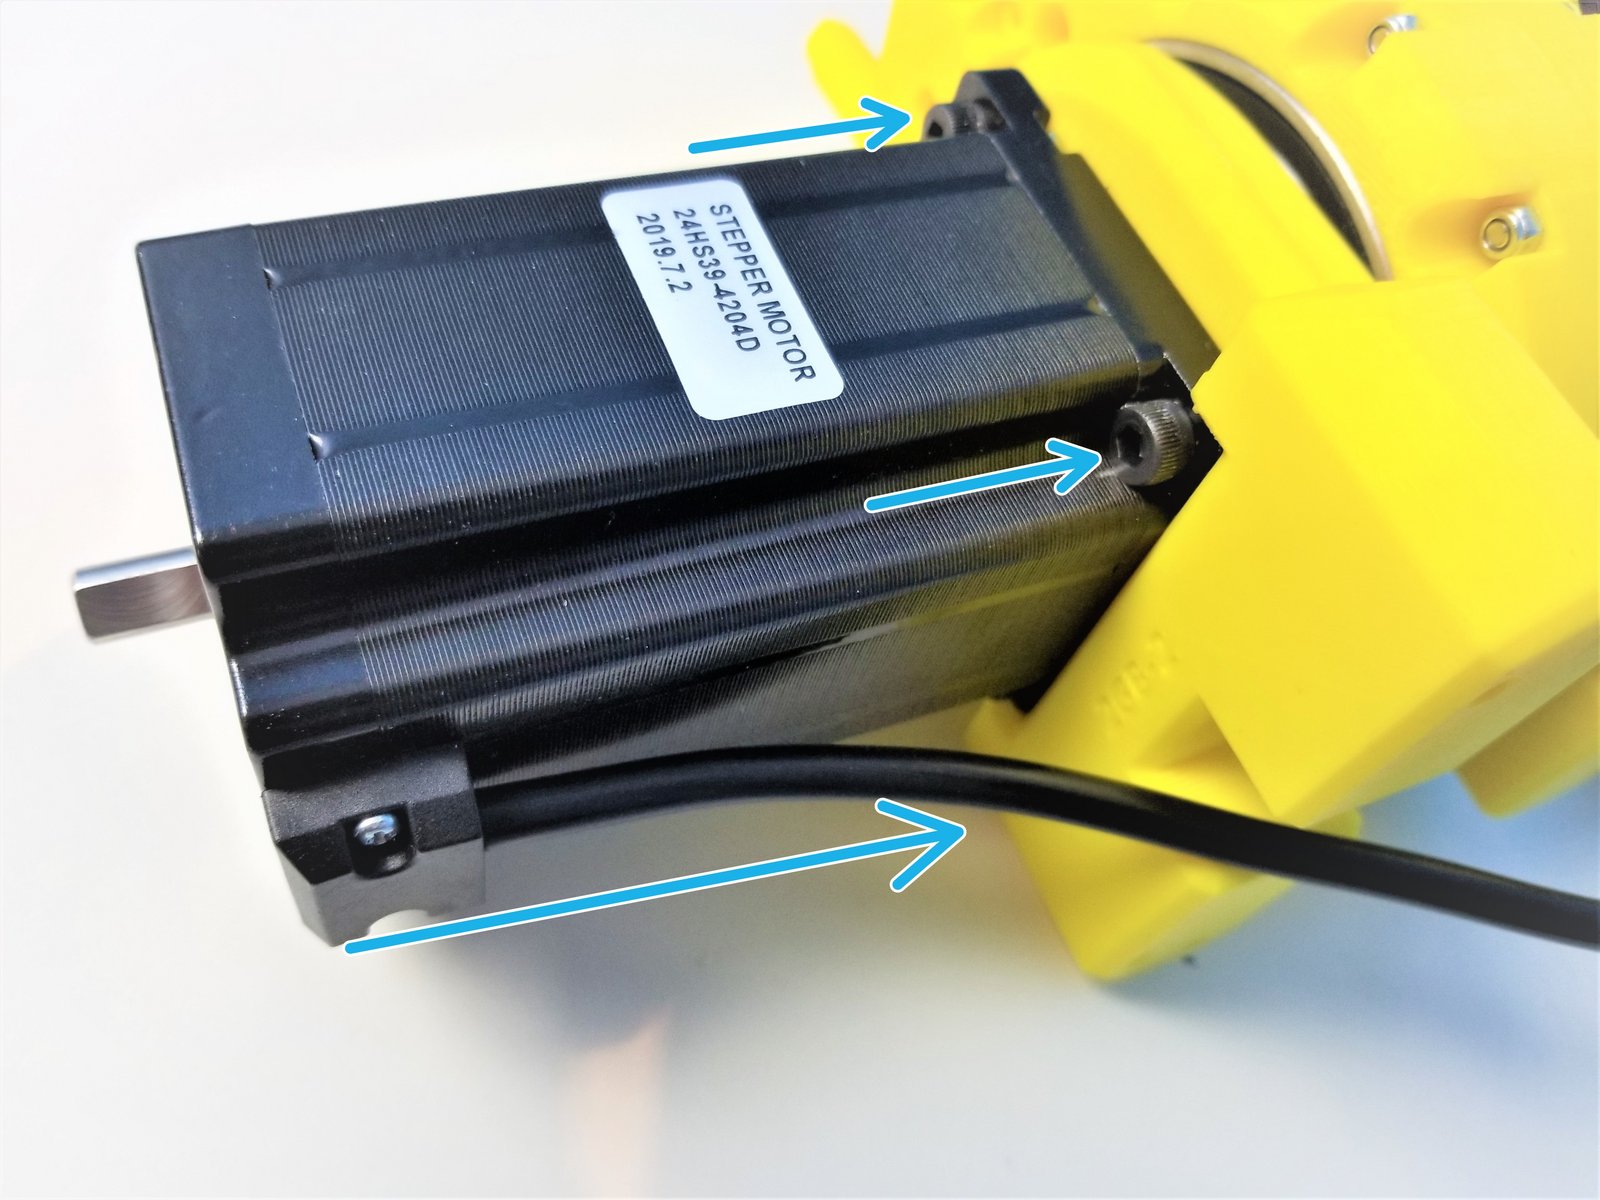
Align the D-Cut of the Motor Shaft to the Gearbox Input Shaft and insert the motor all the way through.
Align the motor body so the cable is pointing towards the bottom and secure the position using M5x20mm Screws
Step 18 Shoulder Gearbox Sensor - Parts
Click the large image to open full size.
- Note:
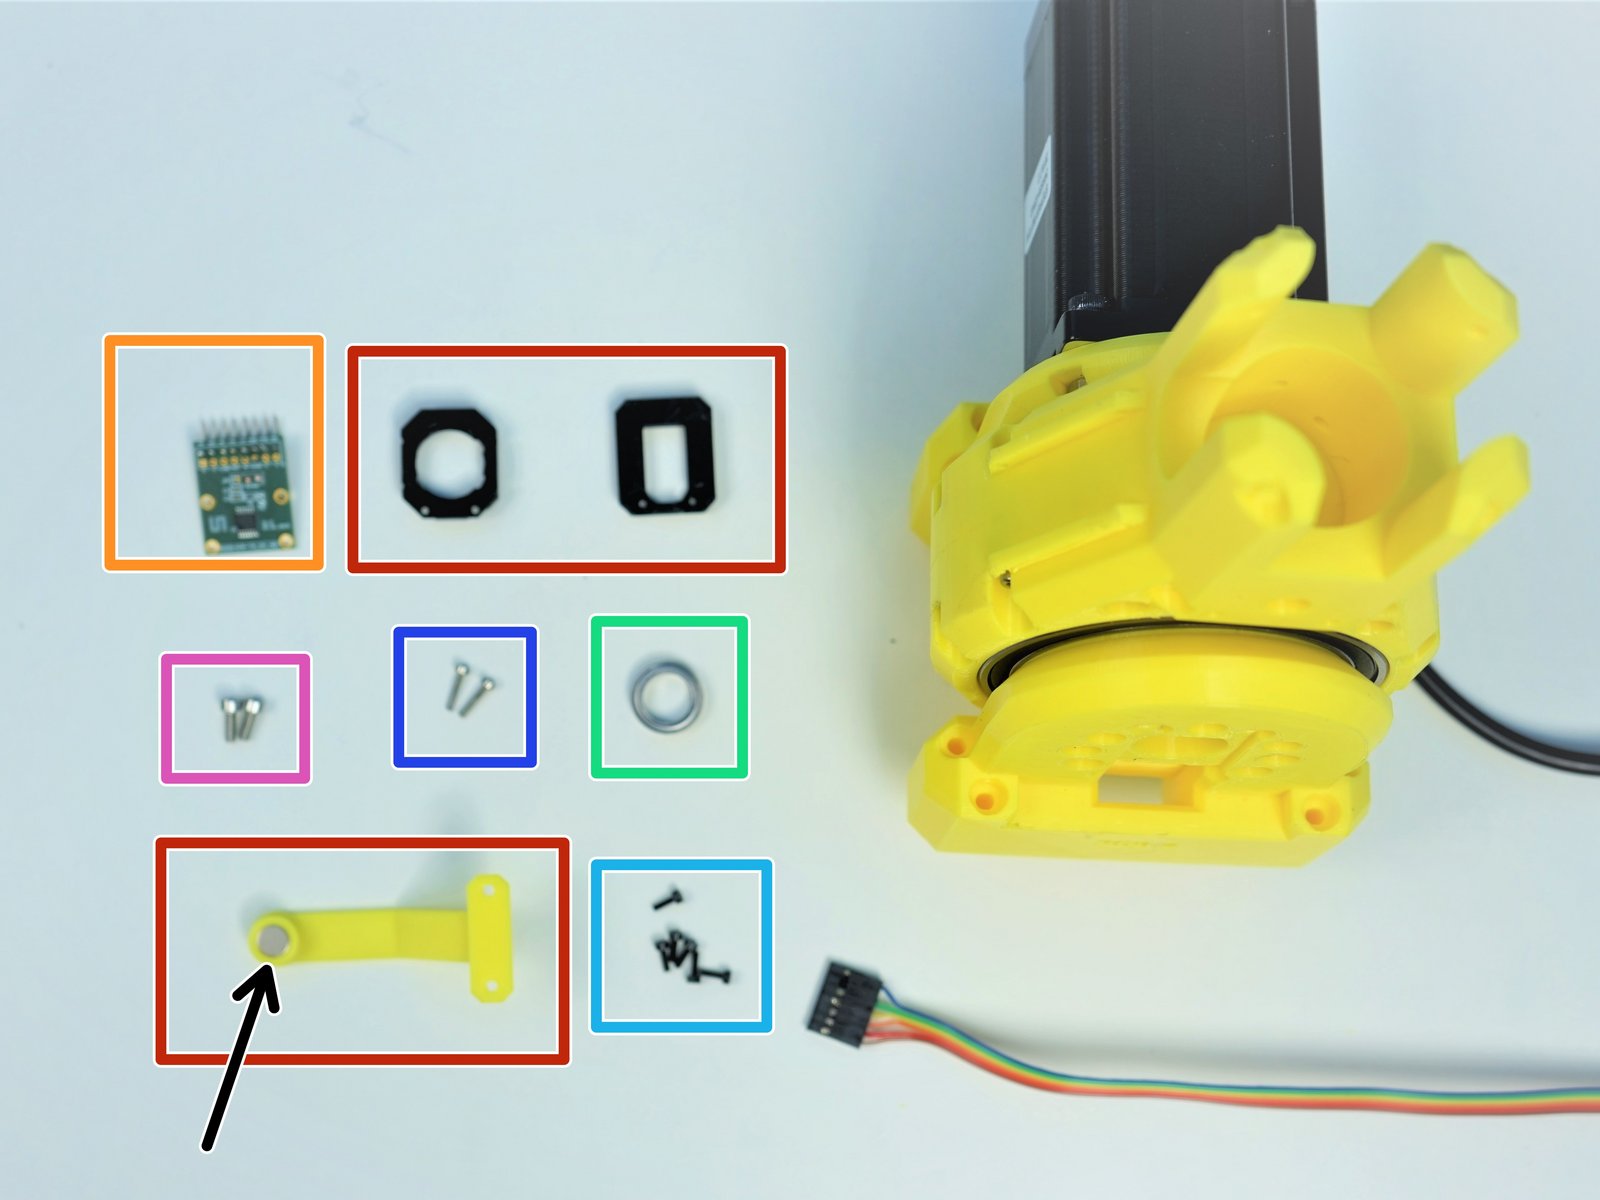
Prepare the following components:
[3D] - Sensor Adapter and Magnet Holder Parts
AS5147 Sensor [right angle headers on Label Side]
8x2.5mm Neodymium Magnet
6701 Bearing [12x18x4mm] (x1)
M2x6mm Screws (x6)
M2x10mm Screws (x2)
M3x8mm Screws (x2)
Step 19 Shoulder Gearbox Sensor - Preparation
Click the large image to open full size.
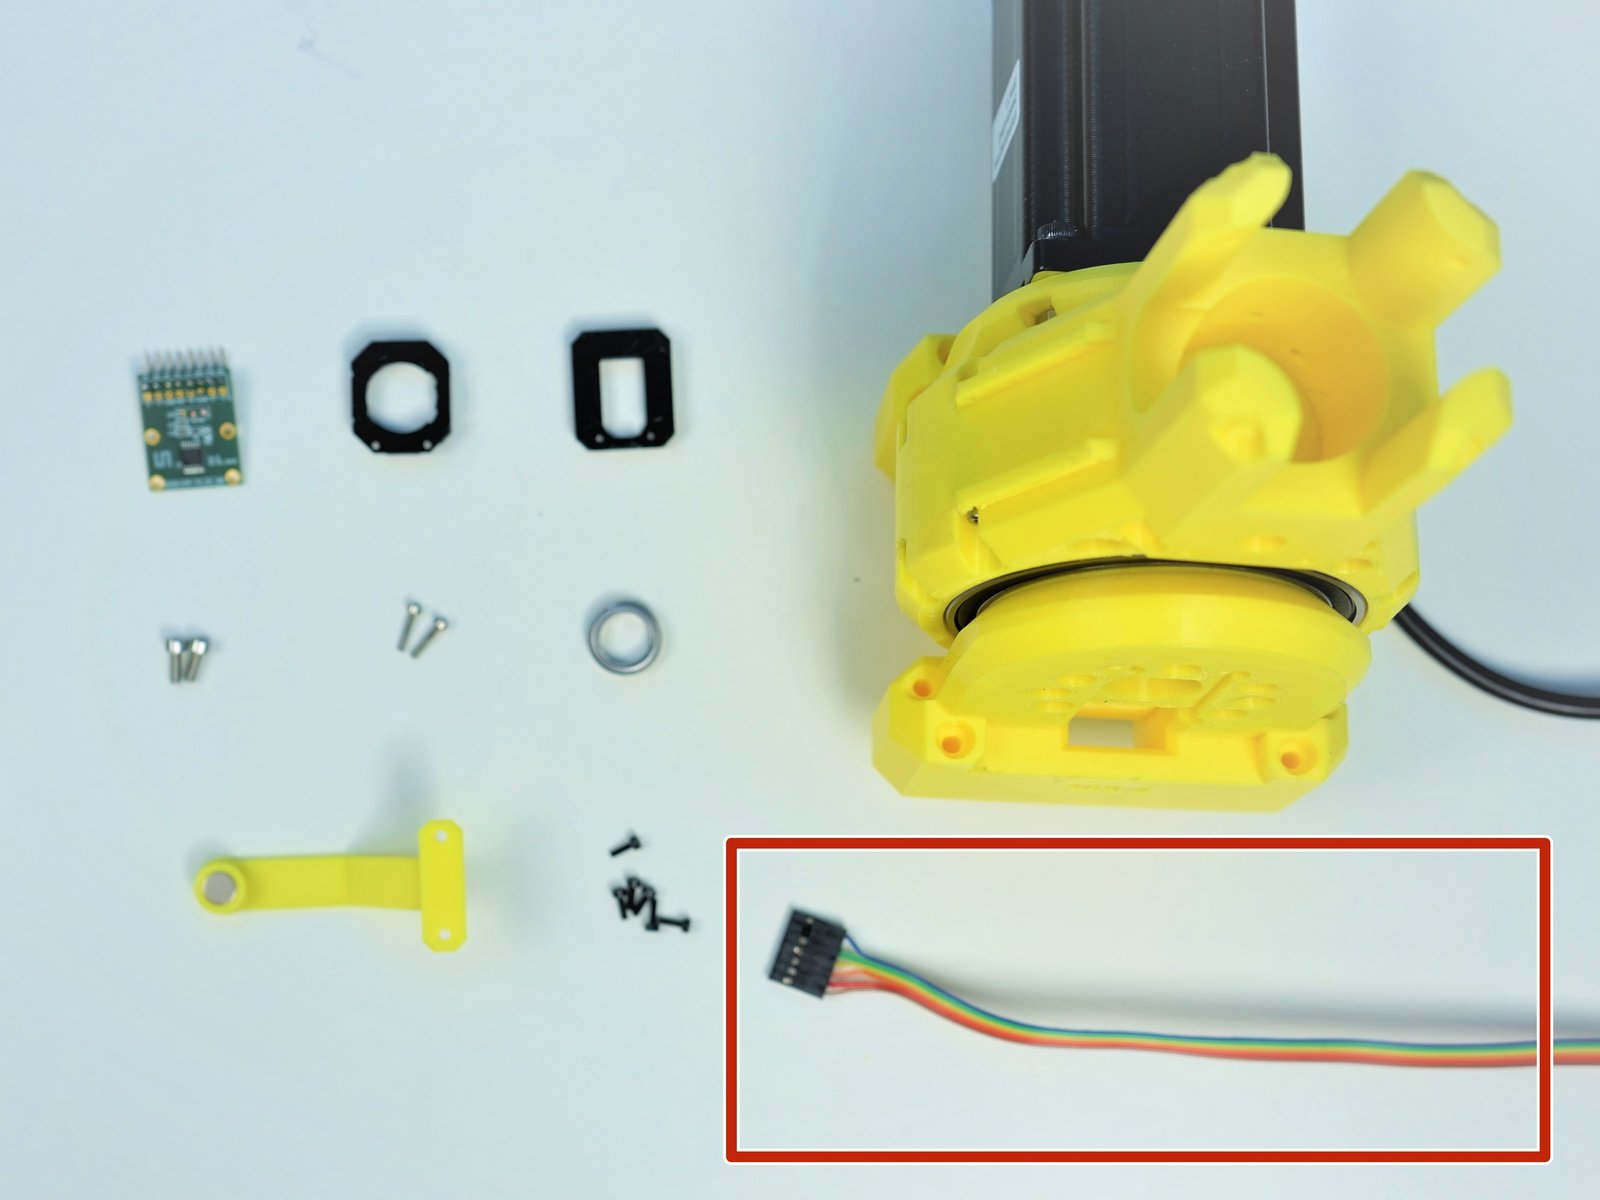
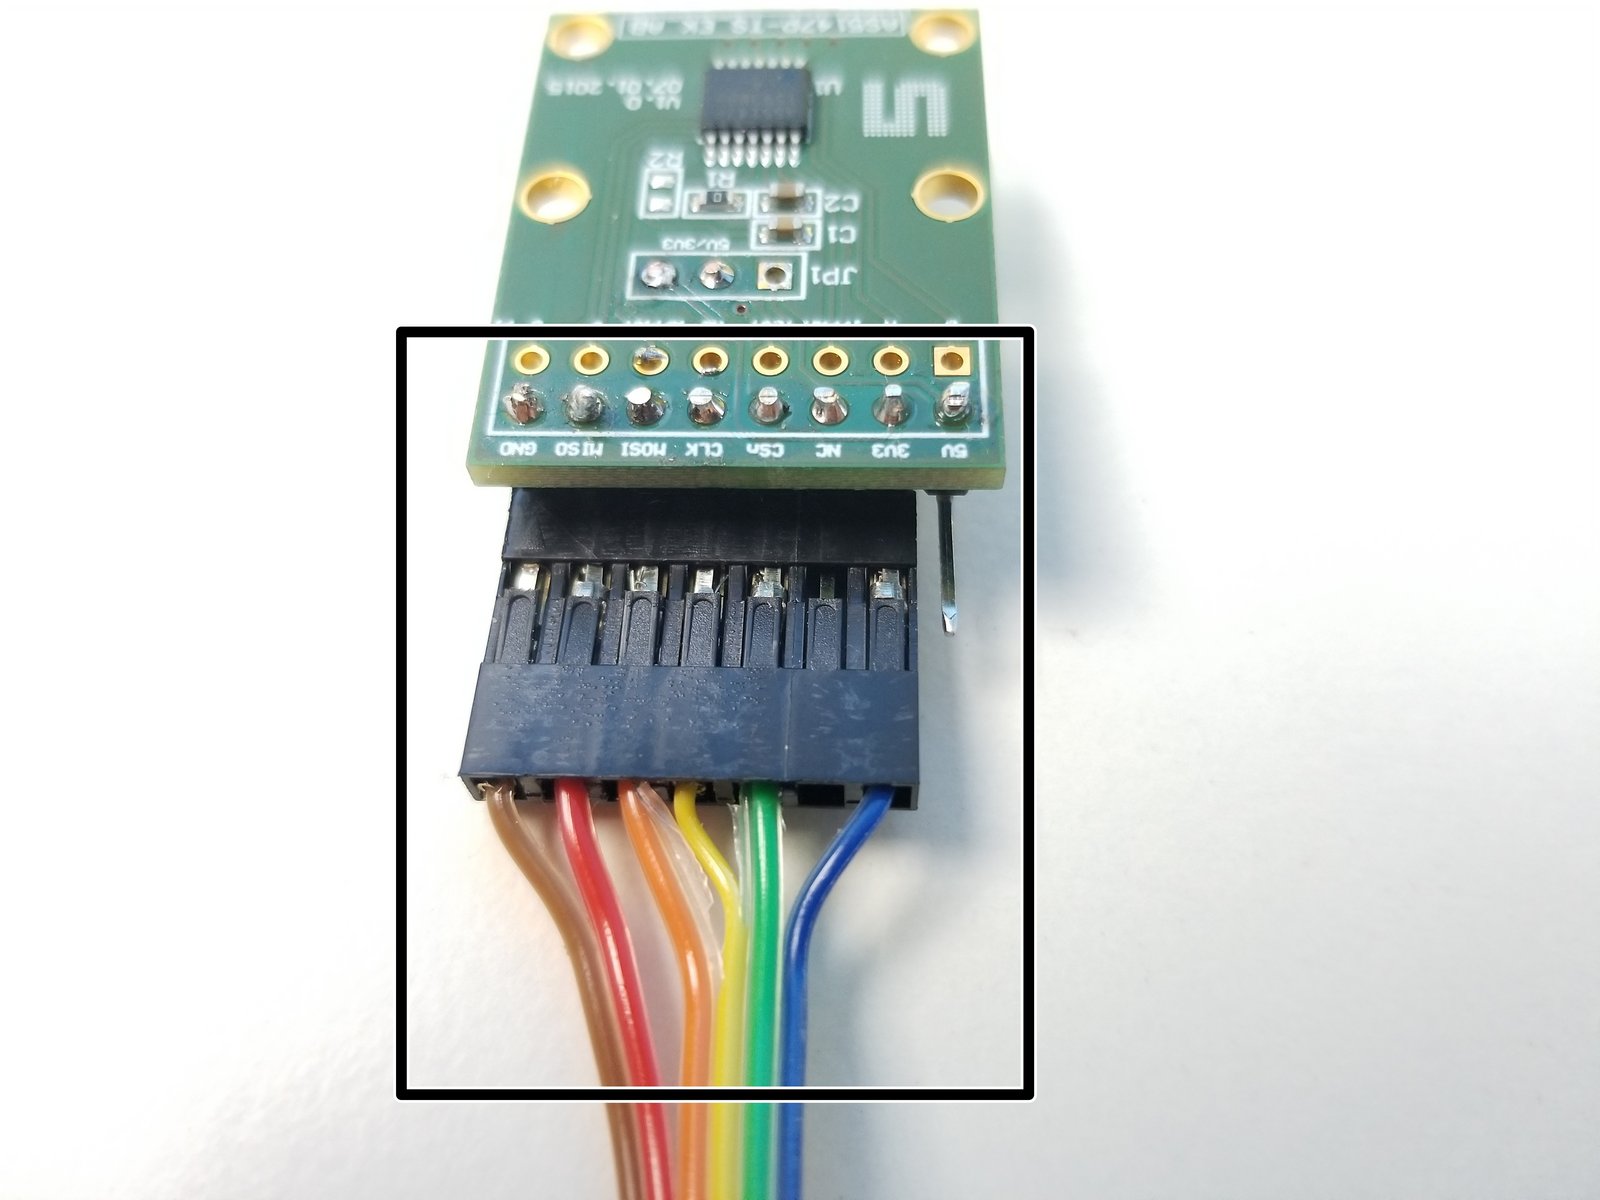
Also prepare 6-pin Ribbon Cable F/O - Brown to Blue {sensor 1 Shoulder} - [365mm]
- Warning:
There is a separate assembly guide for all sensor cable which shows the length of each as well.
Connect the Cable to the AS5147 Sensor as shown in the second picture
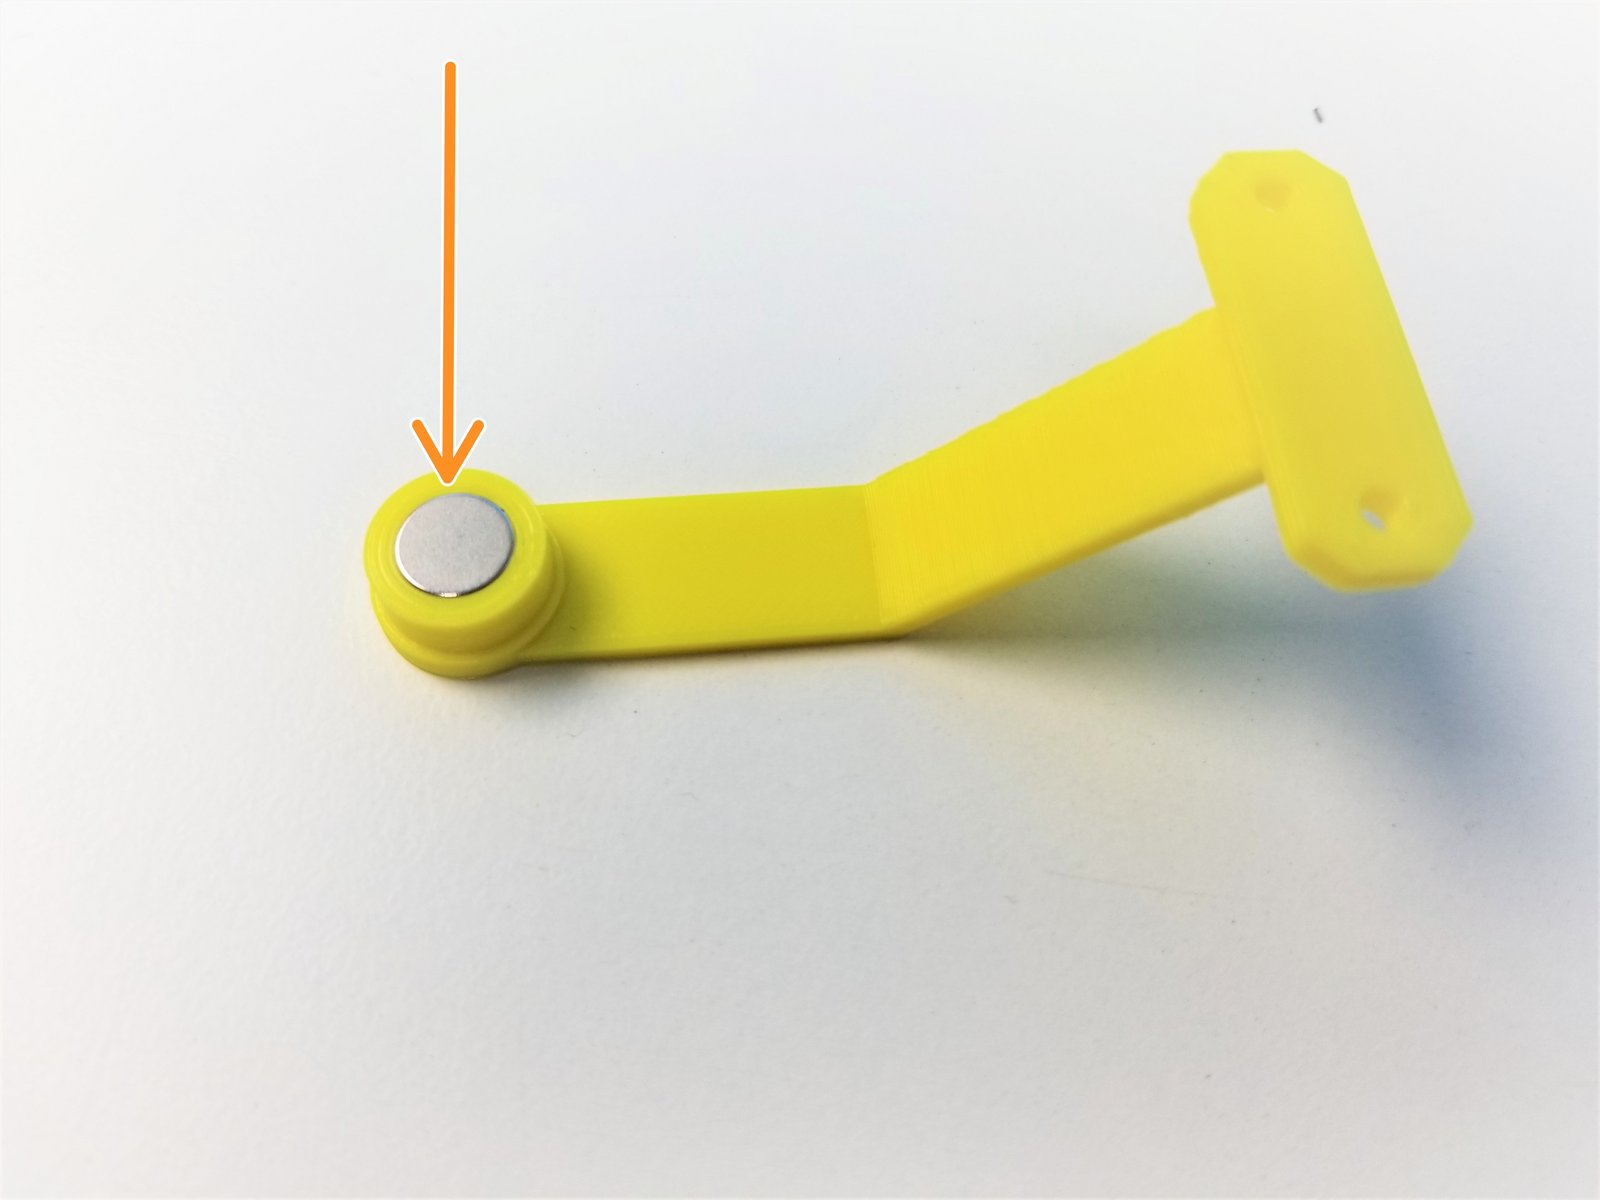
Insert the Neodymium Magnet in the Shoulder Magnet Holder
Step 20 Shoulder Gearbox Sensor - 1
Click the large image to open full size.
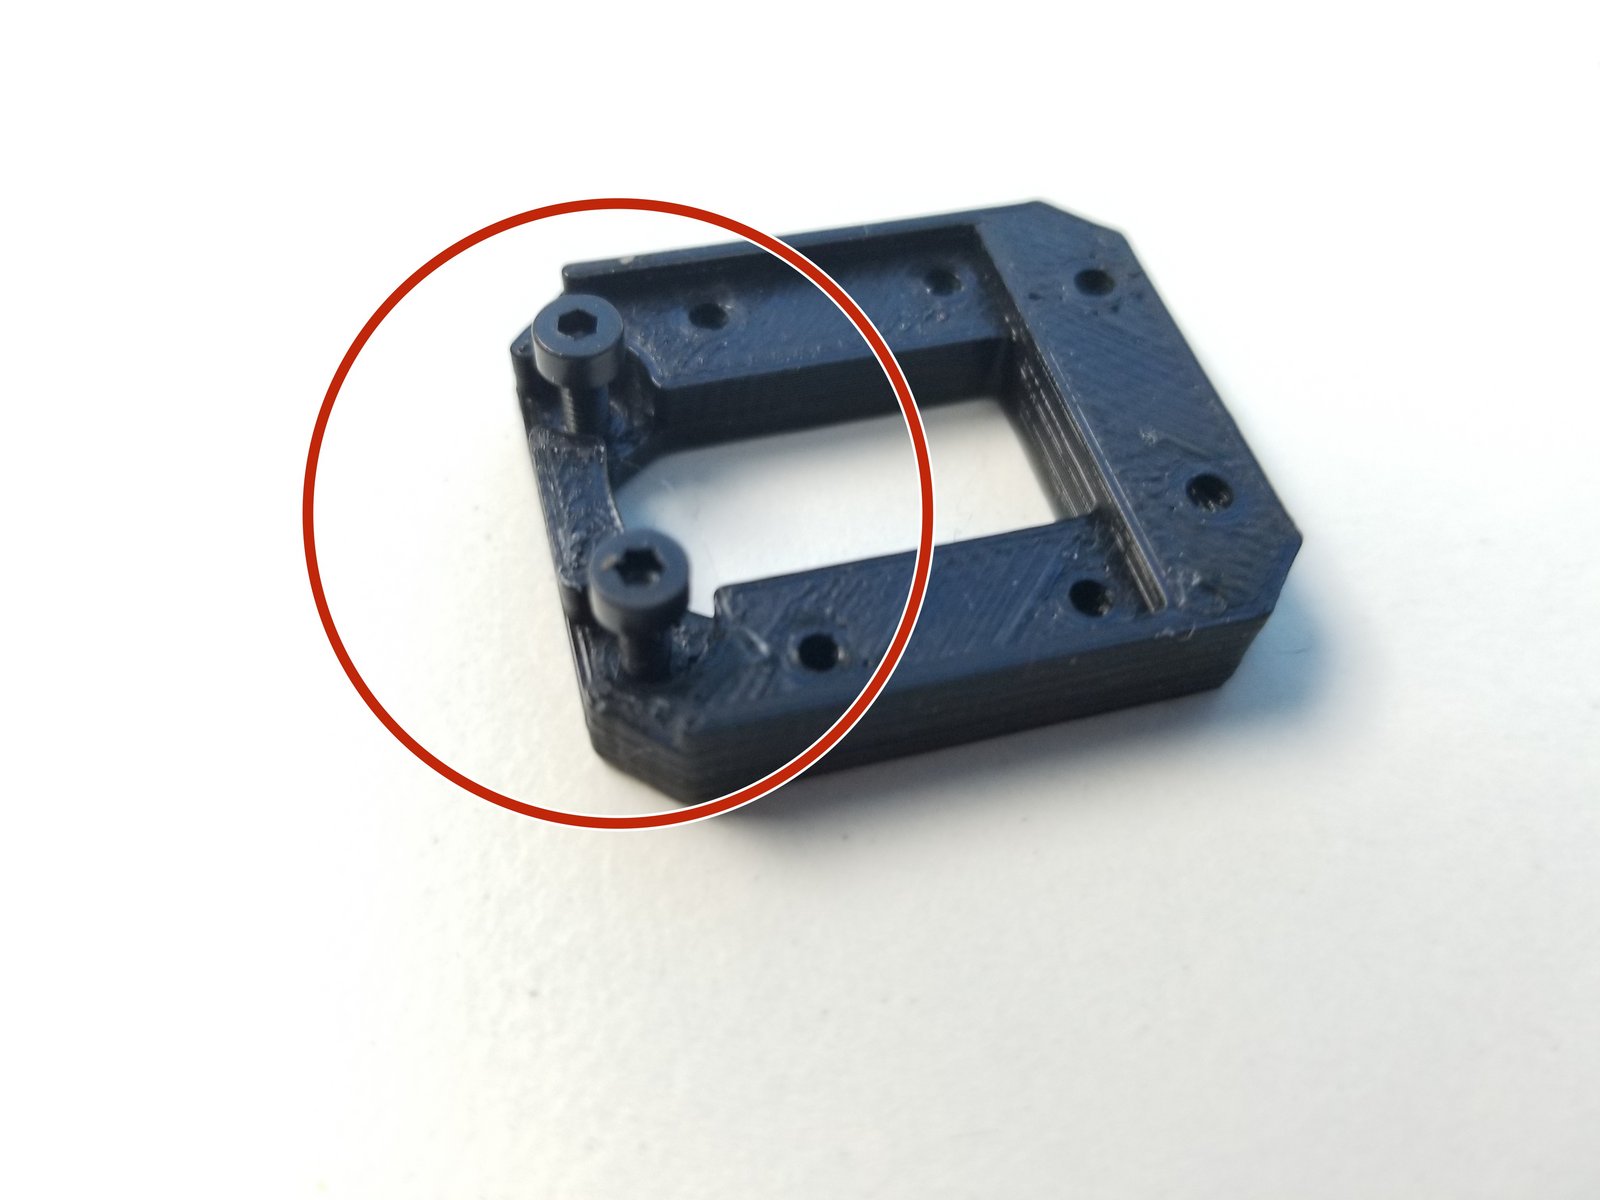
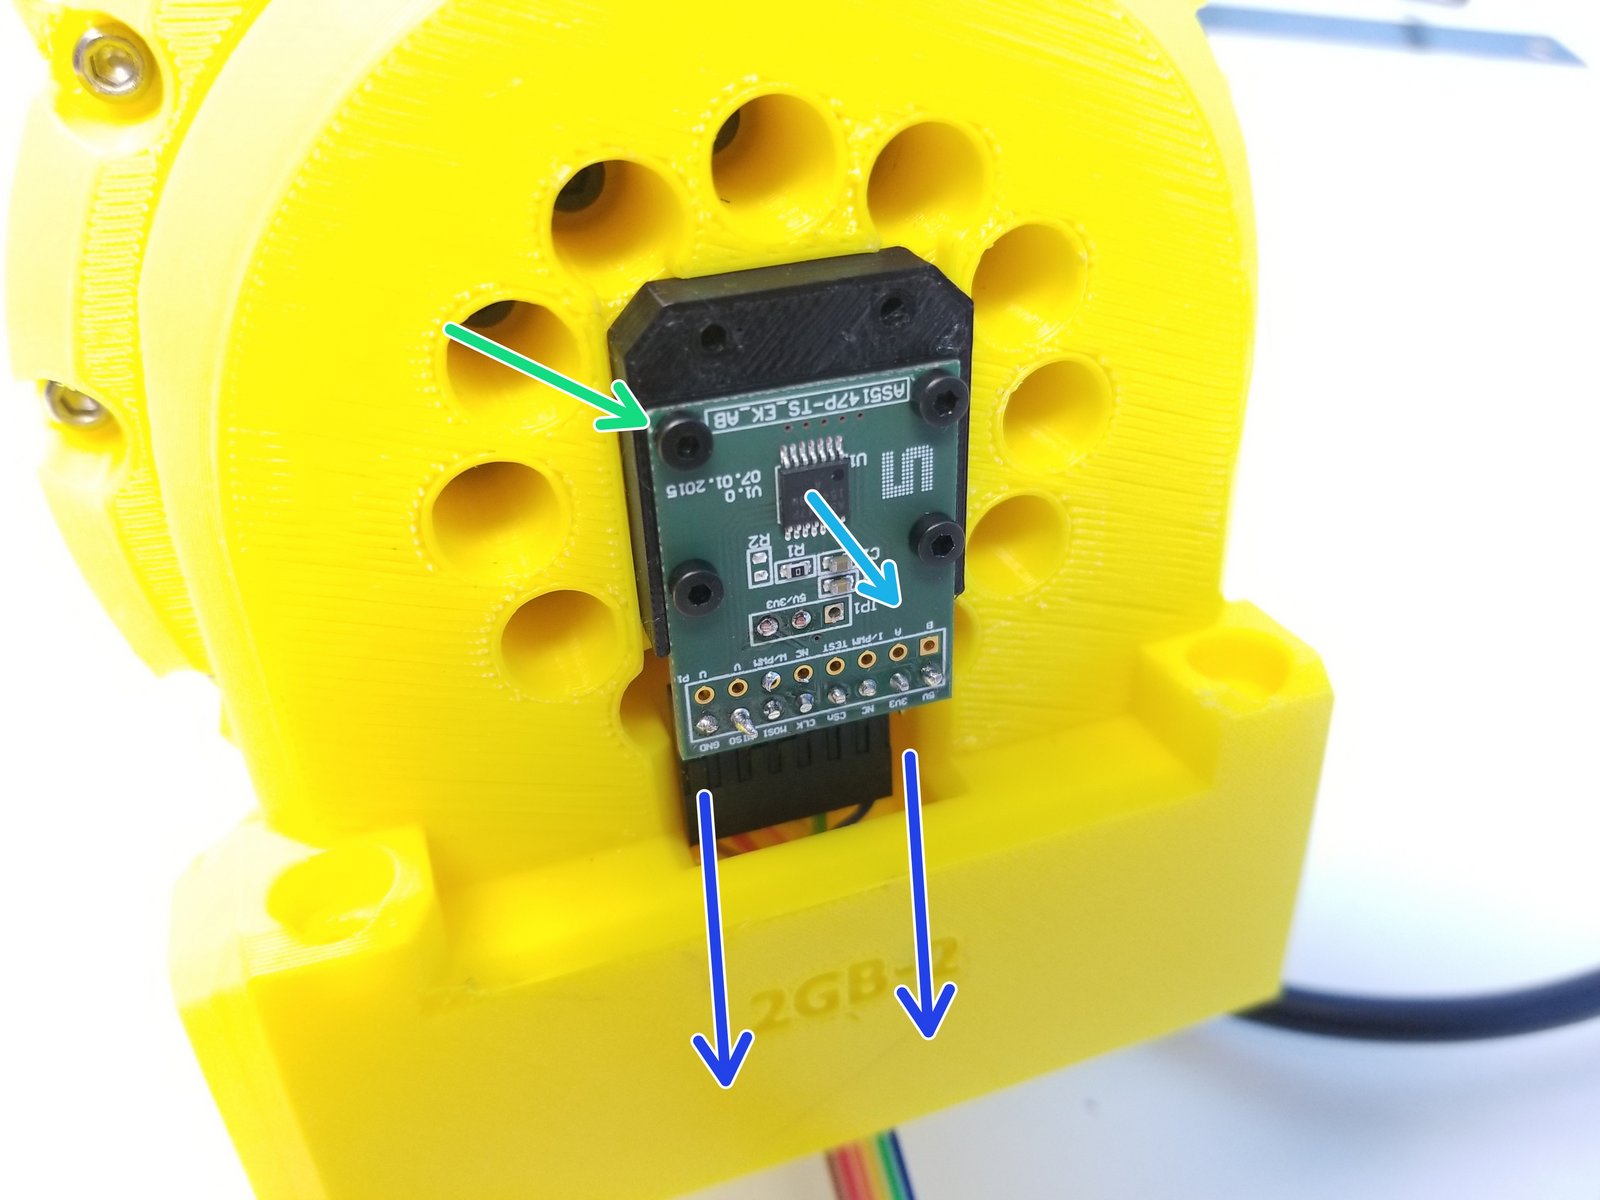
Partially screw in two M2x6mm screws in the Sensor Adapter with the screw head insert.
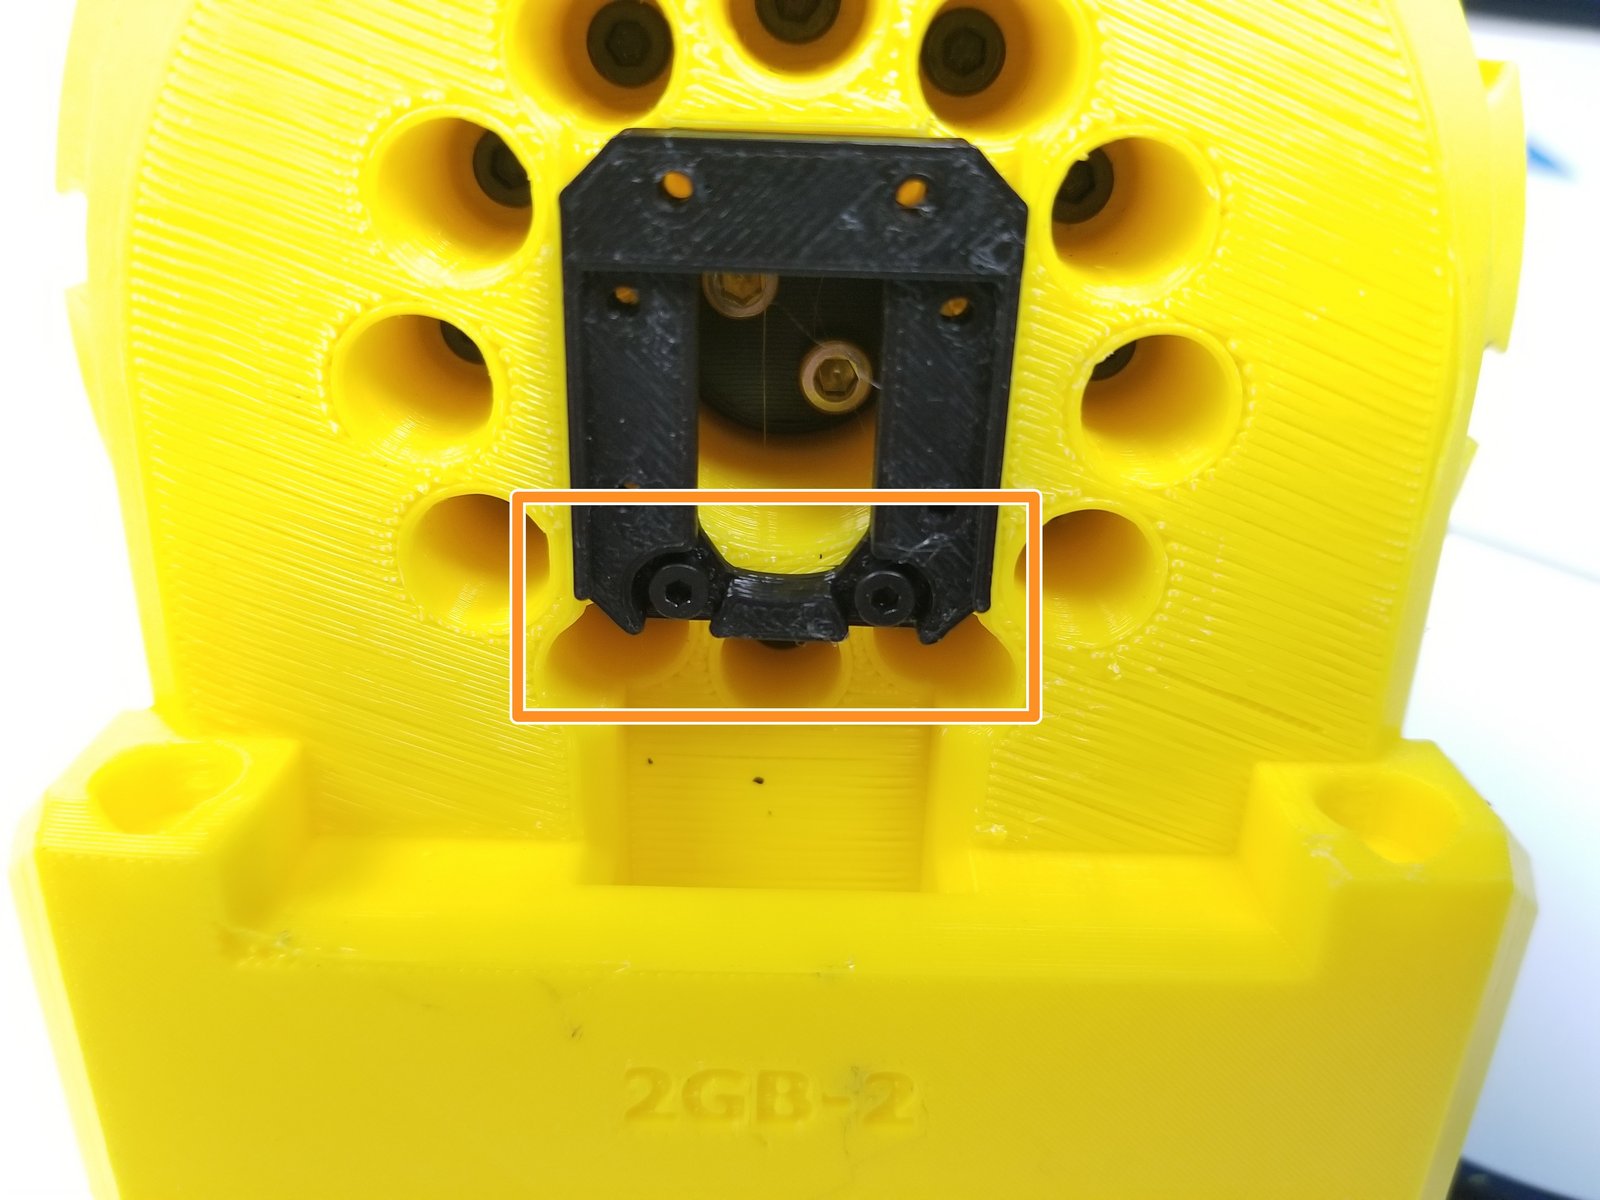
Secure the Sensor Adapter to the Sensor Side of the Gearbox with 2 screw on the bottom side of the 4 holes
Feed the Sensor Cable through the Tunnel
Then use the remaining M2x6mm Screws to Secure the Sensor to the Sensor Adapter
Chip is facing outward
Step 21 Shoulder Gearbox Sensor - 2
Click the large image to open full size.
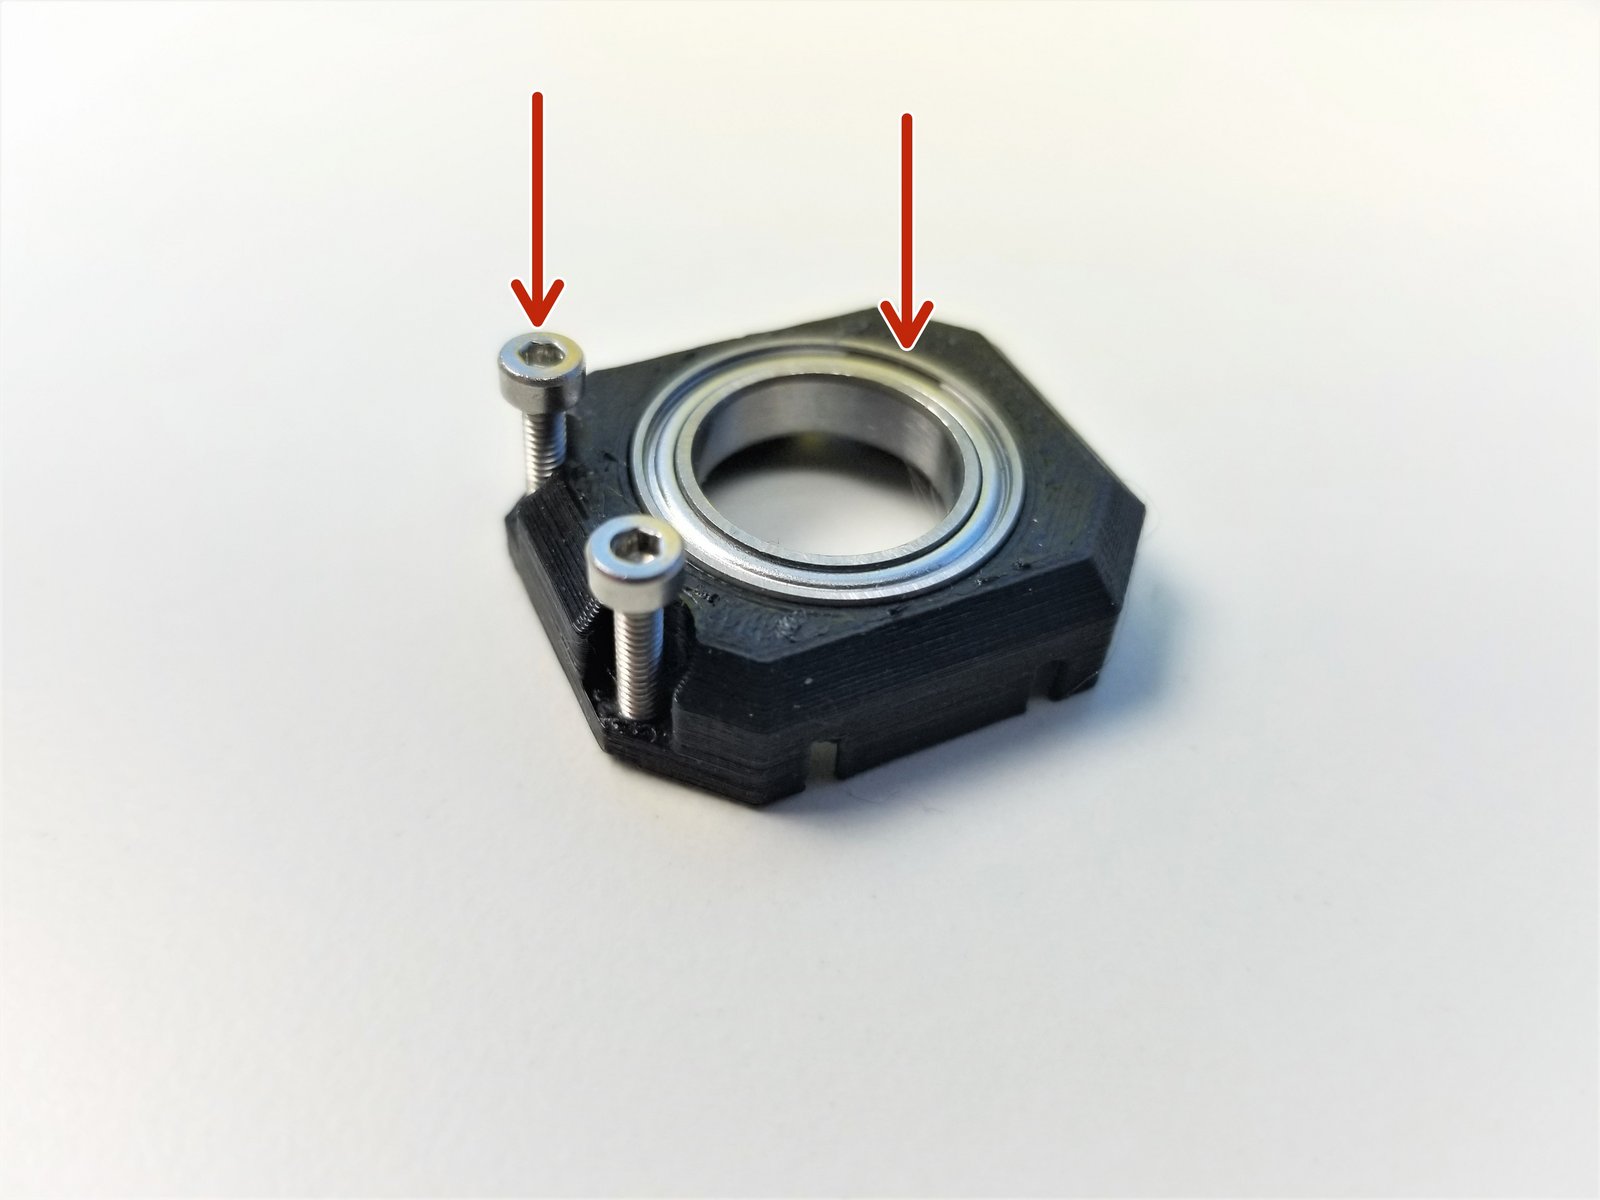
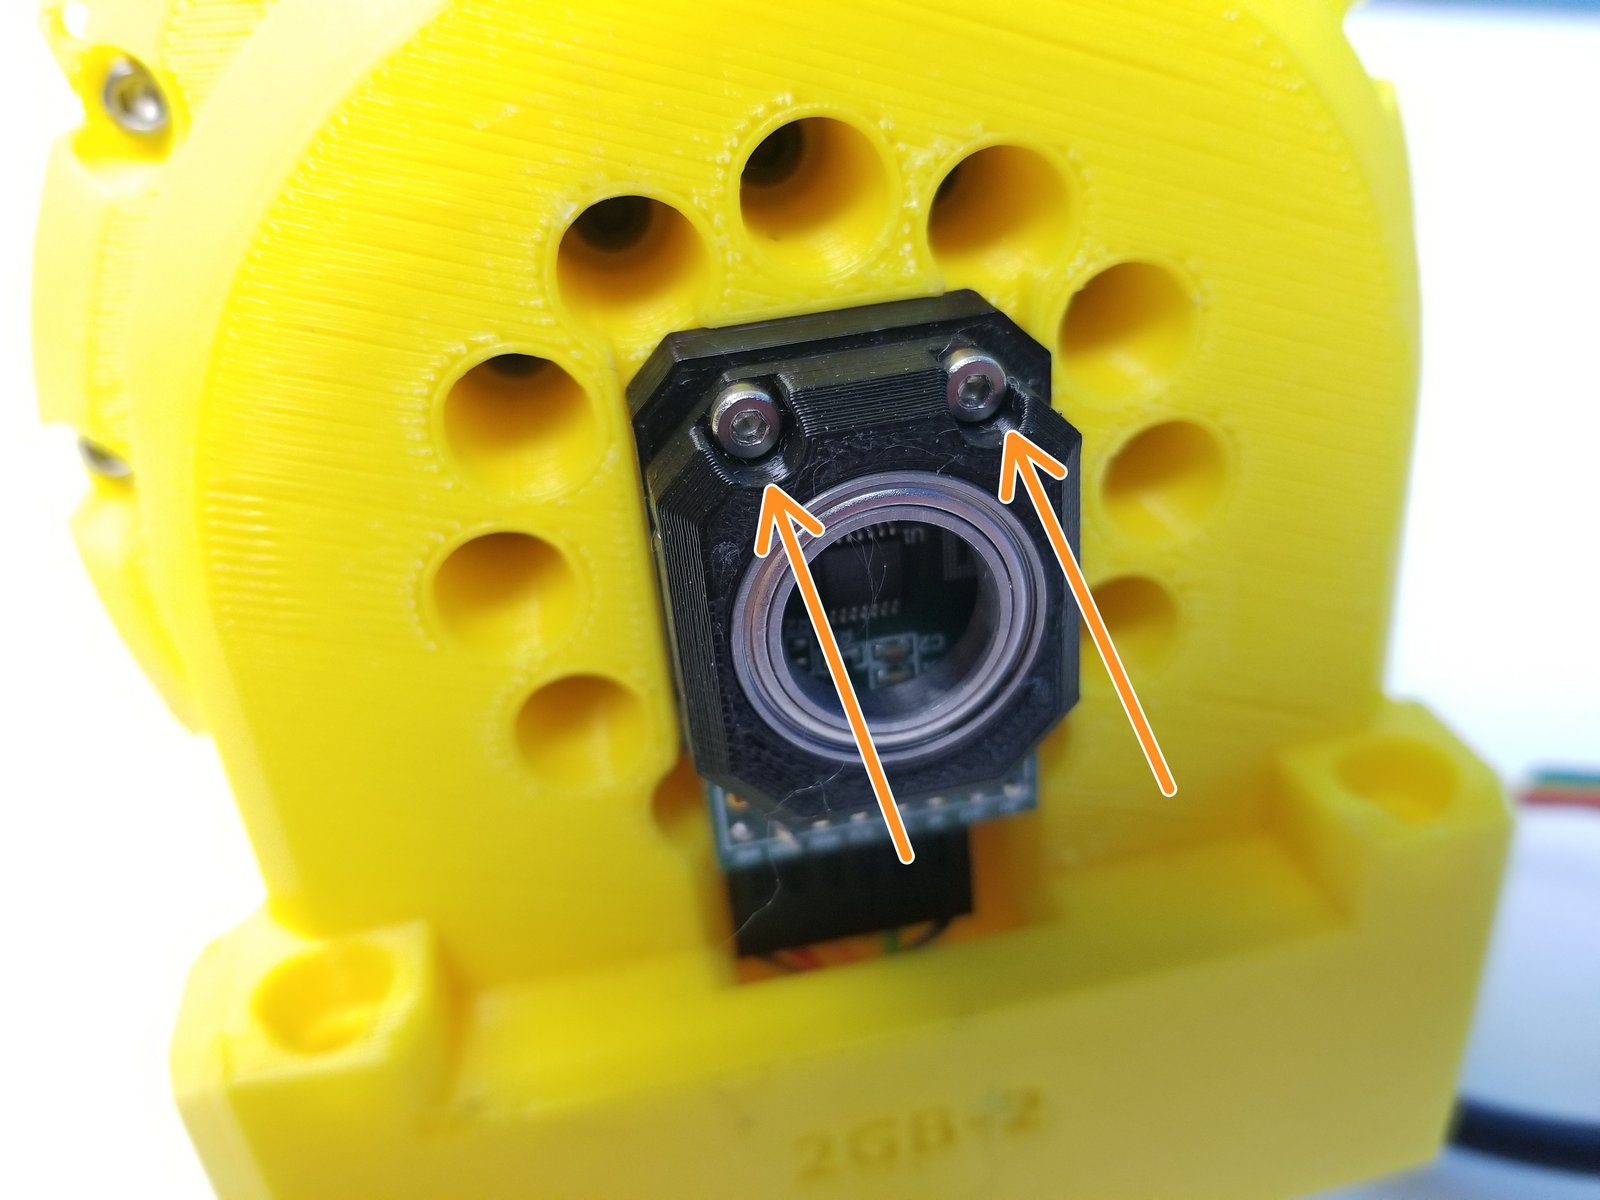
Insert 6702 bearing in the Sensor Bearing Holder part and partially screw in M2x10mm screws
Secure the Sensor Bearing Holder to the Sensor Adapter
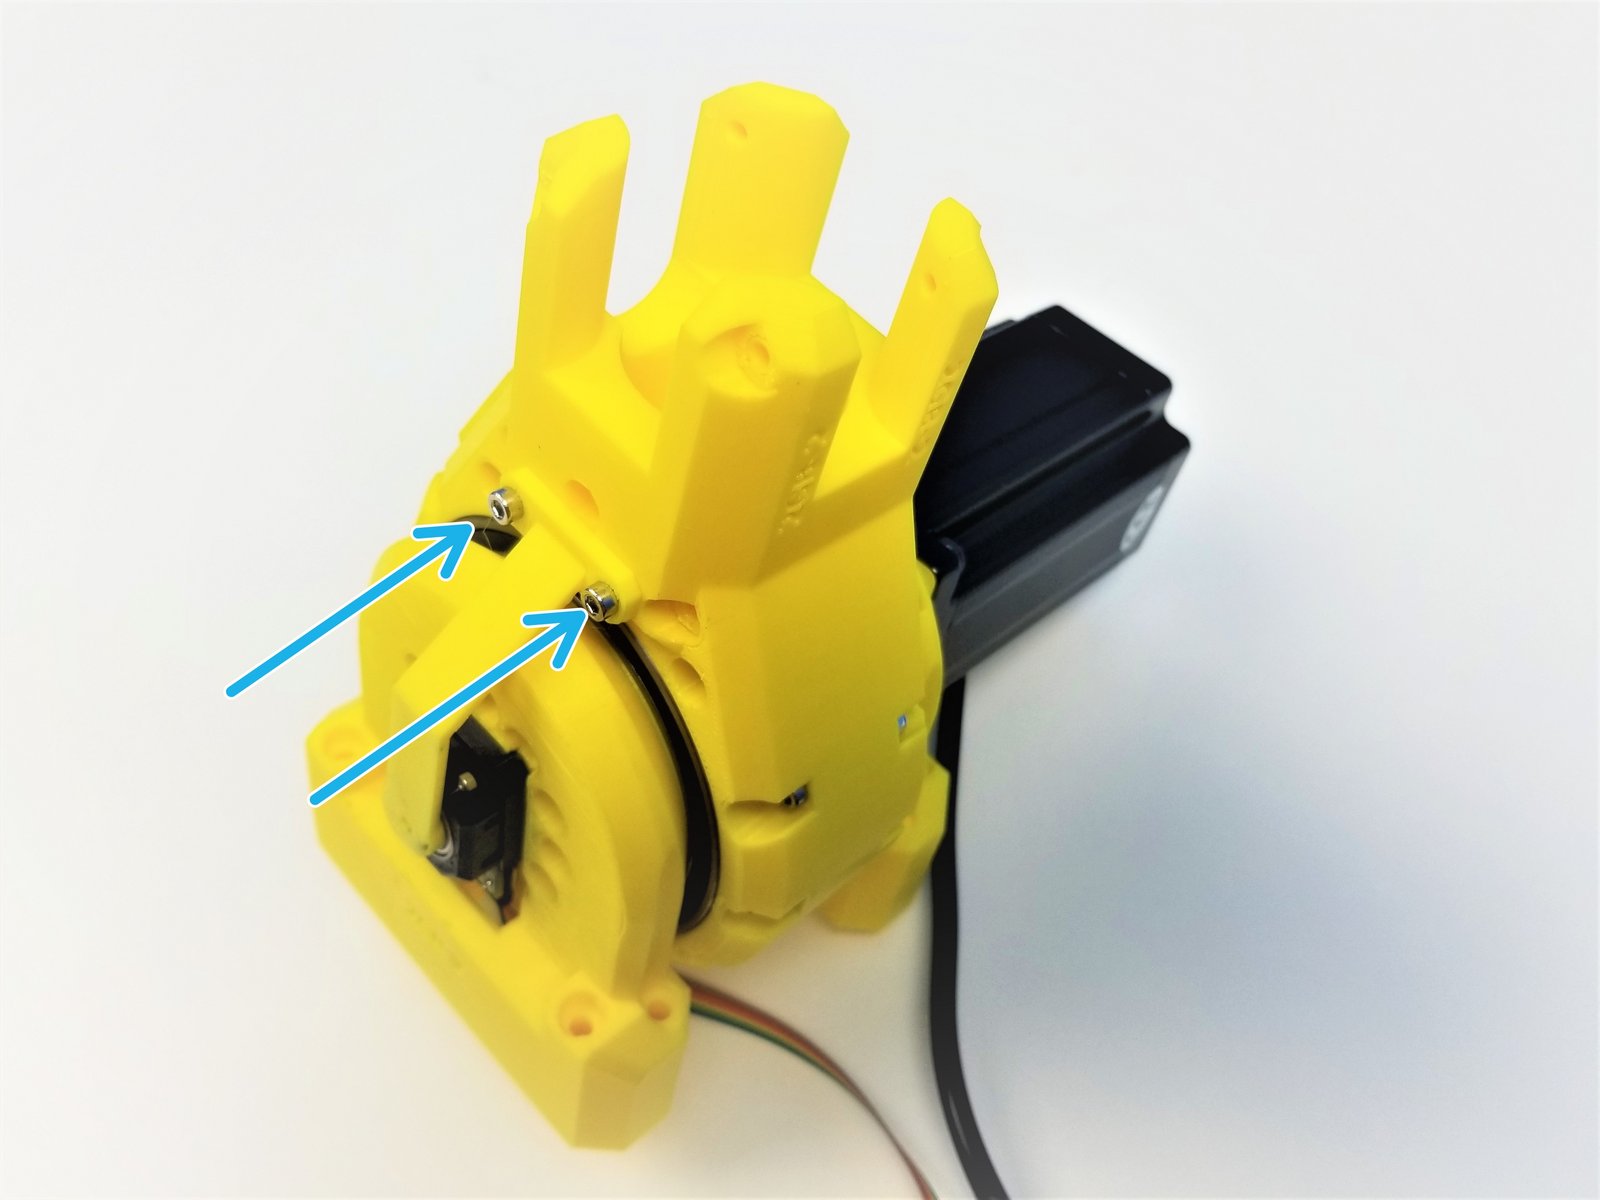
Use M3x8mm Screws to secure the Magnet holder to the Shoulder Gearbox Top
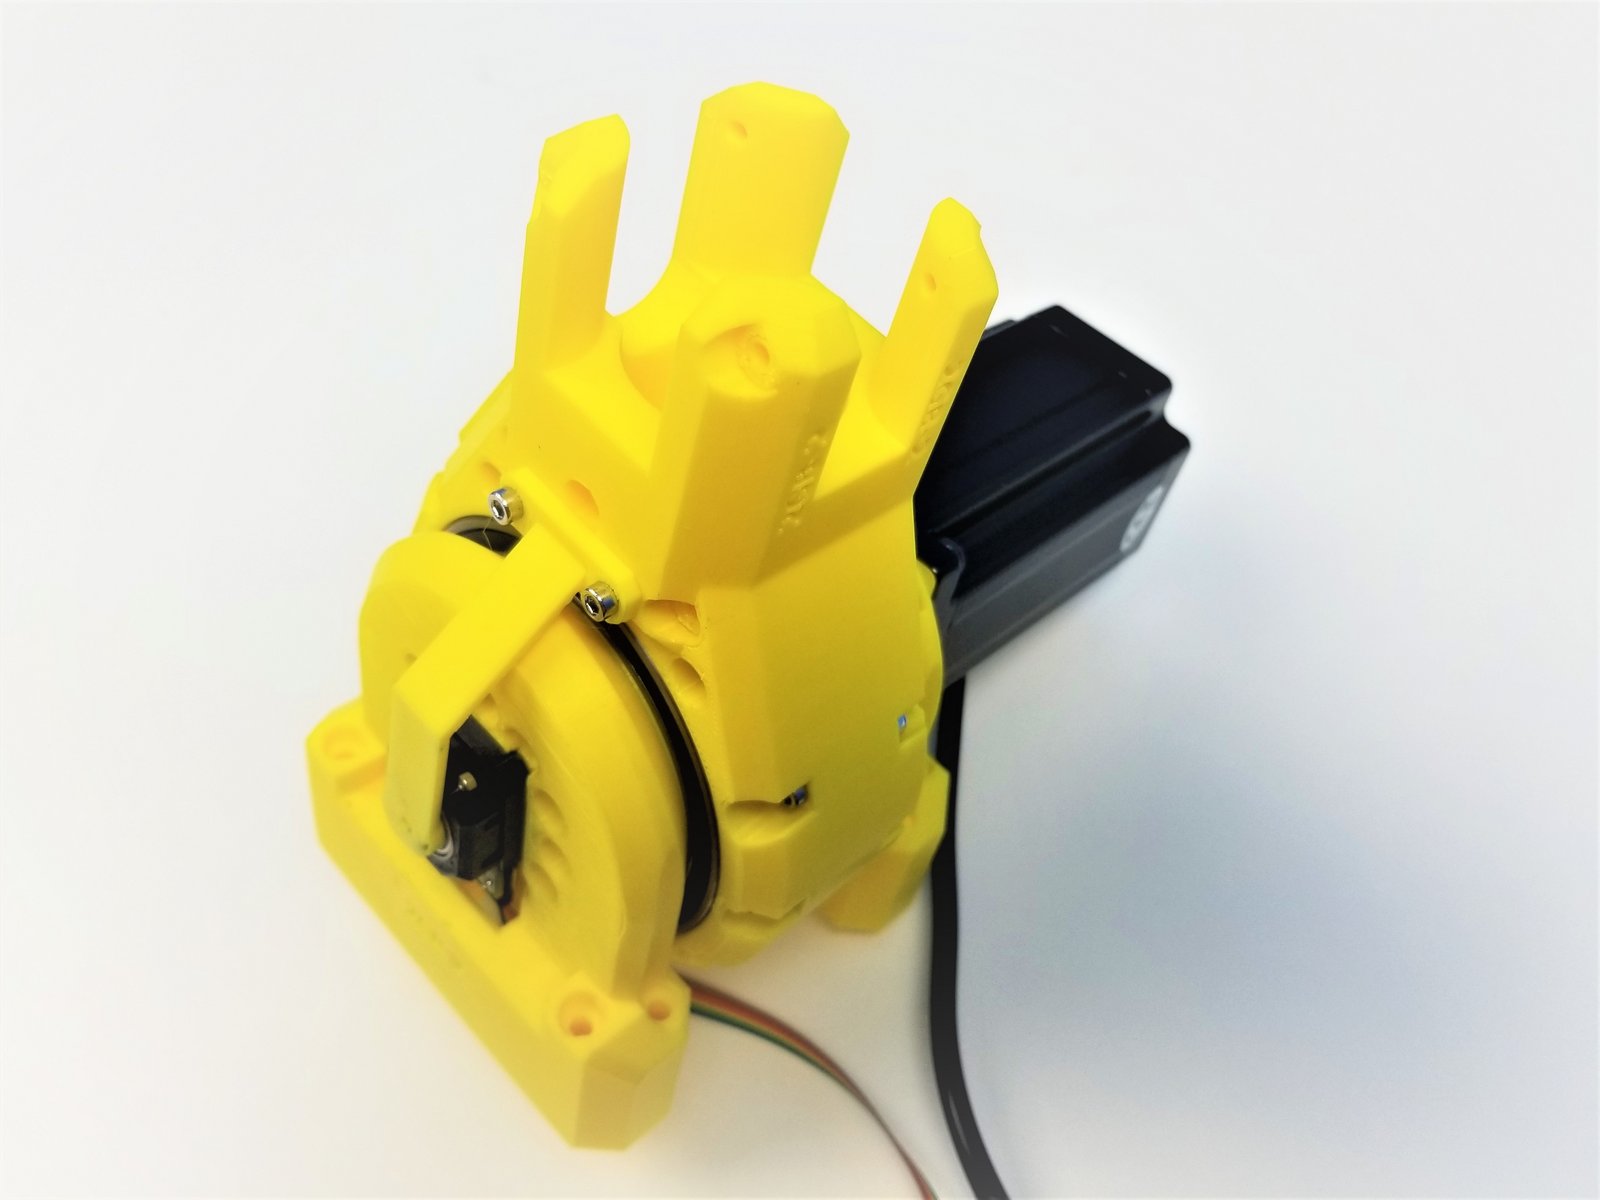
Step 22 Finished!
Click the large image to open full size.
Congratulation! Treat yourself with a candy break.