Sixi 2 robot arm
How to Make Sub Assemblies
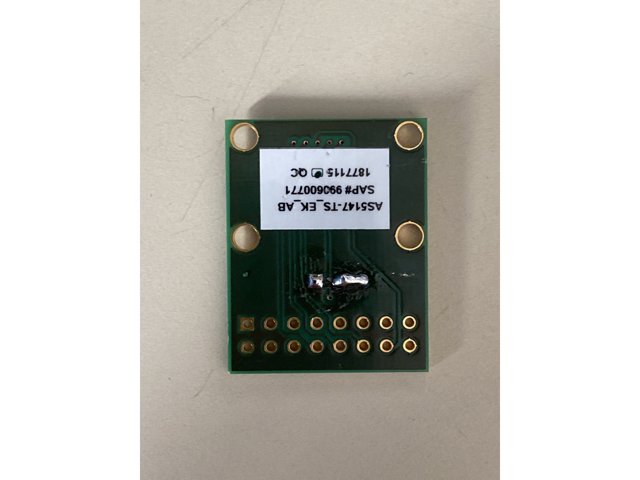
Step 1 SIXI2-112,SIXI2-113,SIXI2-114: AS5147 sensors
Click the large image to open full size.
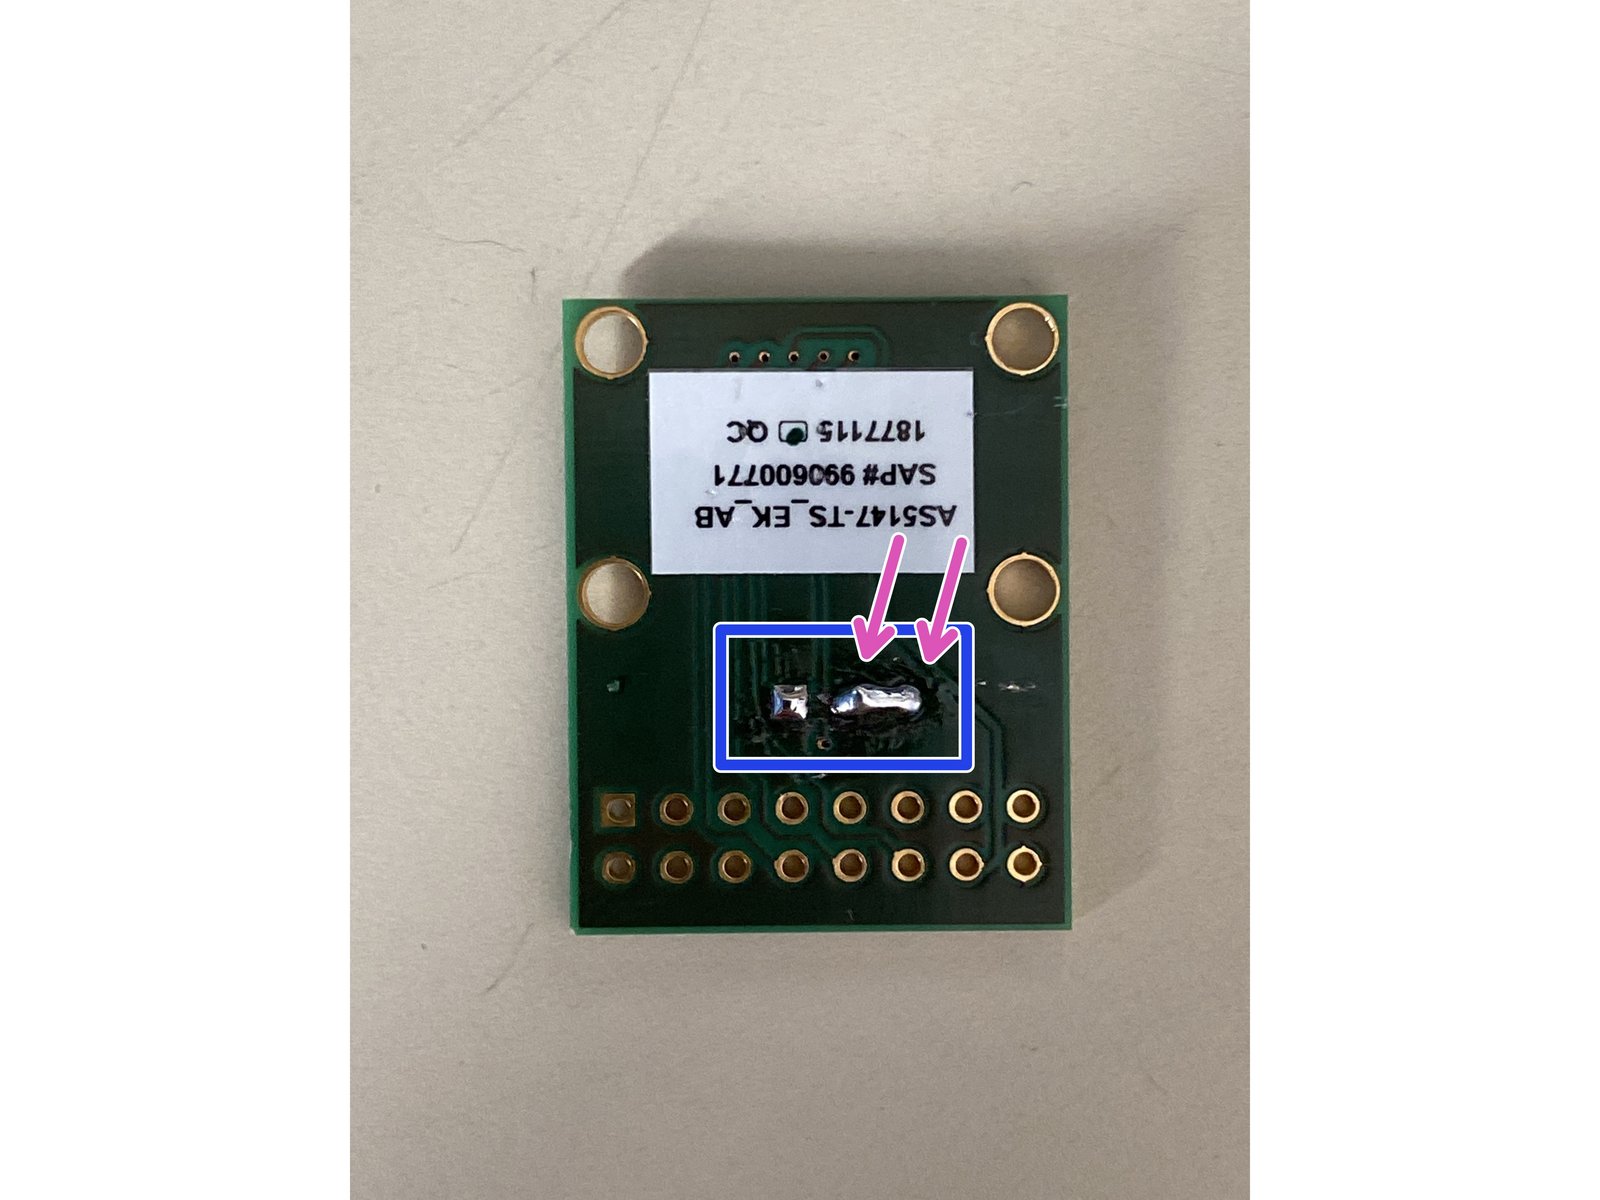
Desolder the three pin jumper from the middle of the board.
Looking at the back of the pcb, turn the through holes to the south. Using solder form a bridge between the Center and the eastern pins of the jumper.
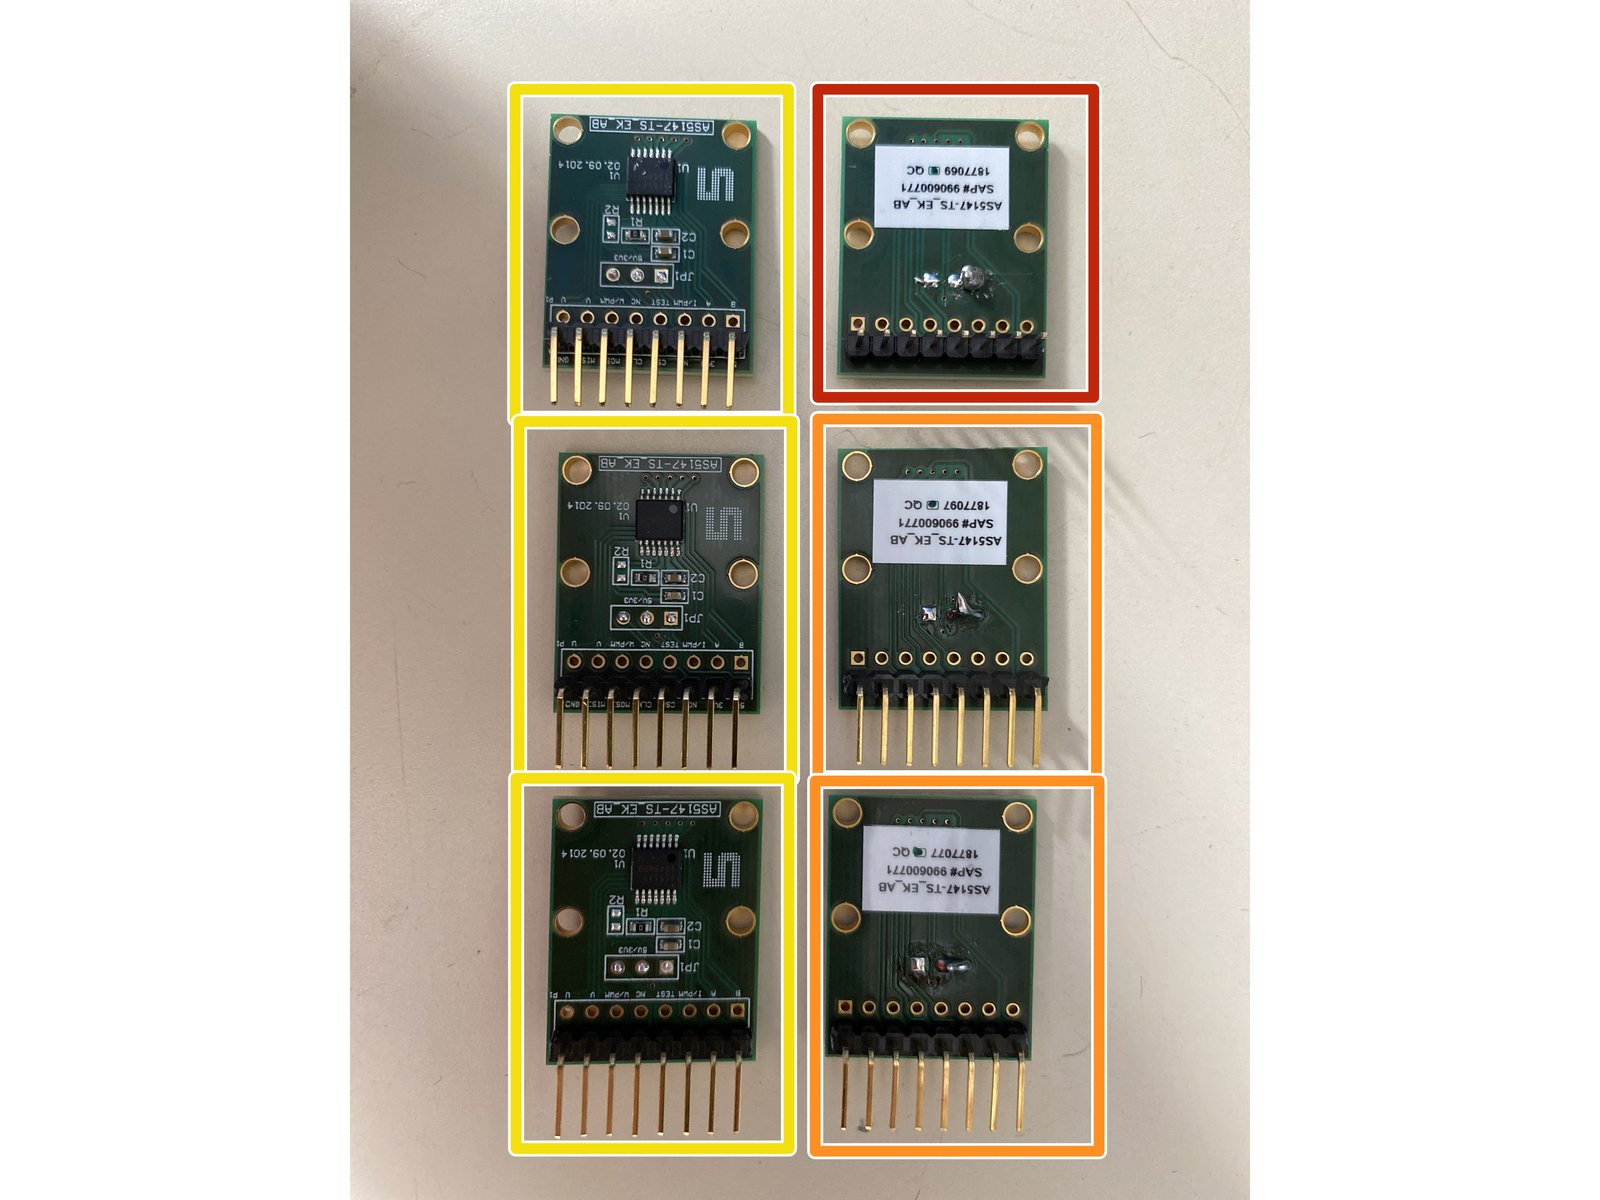
SIXI2-112: Solder one with straight pins on the back
SIXI2-113: solder two with right angle pins on the back.
SIXI2-114: solder three with right angle pins on the front.